Skip to content
AGI PROGRESS INTELLIGENCE

Footprints on the Road to AGI

Selected for You2,507

ZJU+PKU open-source Easel: a social-media agent workbench covering discovery, planning, creation, publishing and attribution across 7 platforms

ZJU+PKU open-source Easel: a social-media agent workbench covering discovery, planning, creation, publishing and attribution across 7 platforms

ZJU REAL lab with Peking University open-sourced Easel (github.com/ZJU-REAL/Easel, 2,384 stars): an open content workbench for social-media creators that hands the whole operations pipeline to an OpenClaw-powered agent. Five-layer workflow: **Discover** (aggregates Weibo/Douyin/Zhihu/Bilibili/Baidu/Toutiao trending plus industry news and competitor moves to pick topics that fit your account), **Plan** (positioning, audience profiles, topic matrices, titles/hooks, storyboards, content calendar), **Create** (copy, quote cards, Xiaohongshu knowledge cards, posters, infographics, AI image gen, multi-voice TTS, voice cloning, AI music, AI video and short dramas, subtitles, editing and clipping — every skill ships runnable scripts writing to outputs/), **Publish** (one master asset rewritten into the formats of 7 platforms — Xiaohongshu/Douyin/Kuaishou/Zhihu/Bilibili/Channels/WeChat official account — with pre-publish quality gates and copyright checks, real logged-in publishing), **Attribute** (reads back views and engagement, folding what worked into the account profile). Profile-driven rather than one-shot: each account keeps its own positioning, style and memory; one master asset is reused across platform variants.

Demo · 2026-09-30
Hyper3D Rigging: Prompt-Editable Auto-Rigging

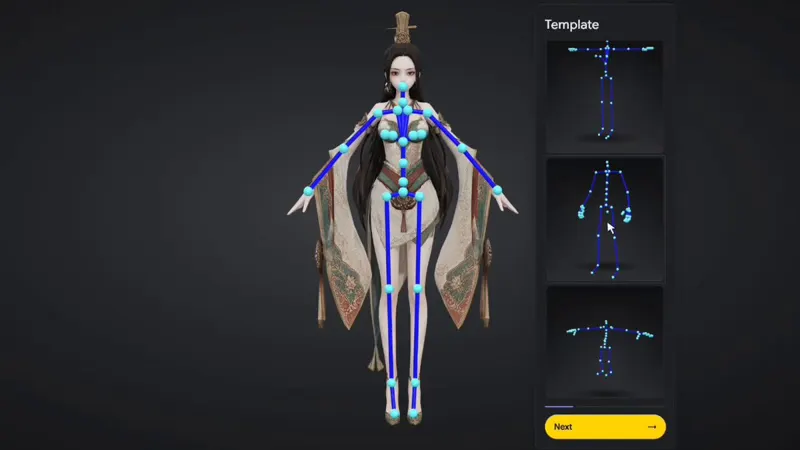
Hyper3D Rigging: Prompt-Editable Auto-Rigging

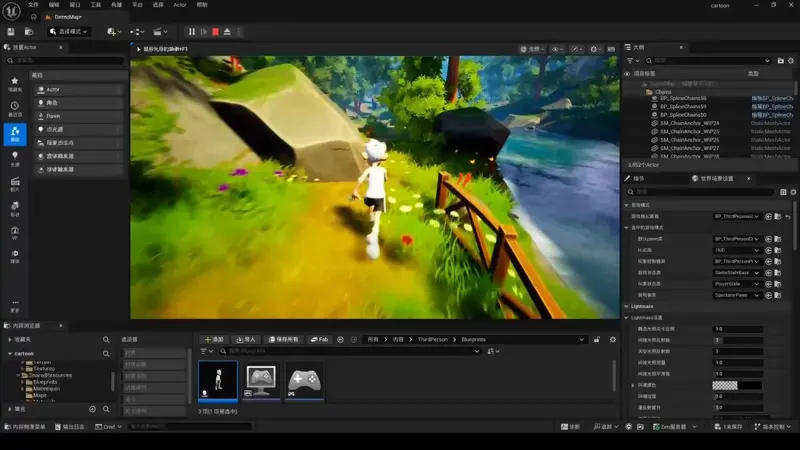
Hyper3D auto-rigs characters to finger level. Prompts add bones; 250+ presets drive animation.

Demo · 2026-11-10
LoopForge: A Self-Hosted Delivery Platform for Coding Agents

LoopForge: A Self-Hosted Delivery Platform for Coding Agents

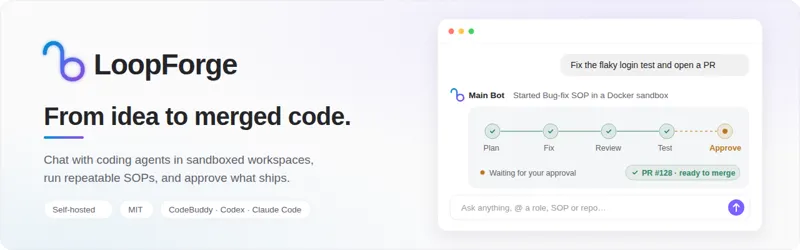
LoopForge is Tencent’s self-hosted delivery platform for coding agents. It combines Docker workspaces, versioned SOPs, human approvals, and repeatable delivery.

Open source · 2026-11-12

TokenEconomizer: Cross-Session Cost Control for Coding Agents

A black-box plugin that learns across coding-agent sessions to reduce repeated repository discovery, unused tools, and failure loops.

Open source · Exploring · 2026-11-17

Claude-BugHunter: Agent Skills and Orchestration for Authorized Security Testing

A reusable Agent Skills framework for authorized security testing, encoding recon, triage, validation, and reporting with code-enforced scope.

Open source · Exploring · 2026-11-16

Frontier papers

548
mimic-video: Video-Action Models for Generalizable Robot Control Beyond VLAs

mimic-video: Video-Action Models for Generalizable Robot Control Beyond VLAs

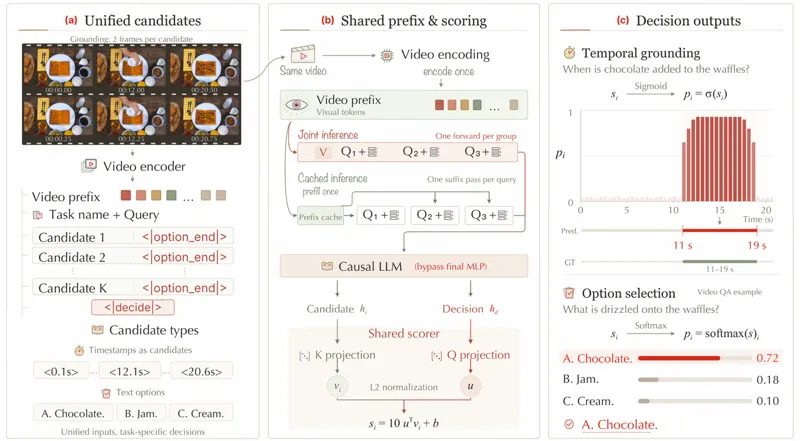
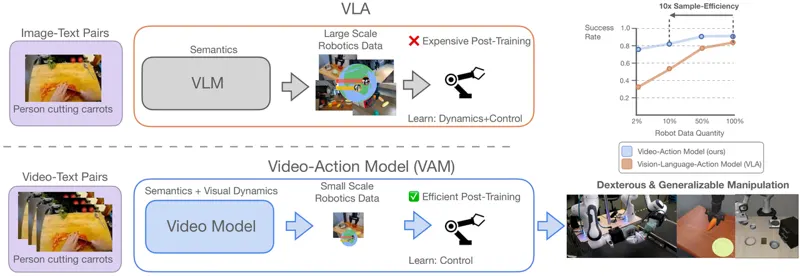
mimic-video couples an Internet-scale pretrained video model with a flow-matching action decoder. Latent visual plans carry physical dynamics, while the decoder acts as an inverse dynamics model that outputs robot actions. Evaluations on SIMPLER-Bridge, LIBERO, and real-world bimanual manipulation show stronger performance with far less action data and faster convergence.

Jonas Pai, Liam Achenbach, Victoriano Montesinos · 49 views · Dec 17, 2025
Video-Action ModelRobot Manipulation
Dec 17, 2025
MIDAS Hand: Modular low-Impedance Direct-drive Anthropomorphic Sensing Hand
02Paper

MIDAS Hand: Modular low-Impedance Direct-drive Anthropomorphic Sensing Hand

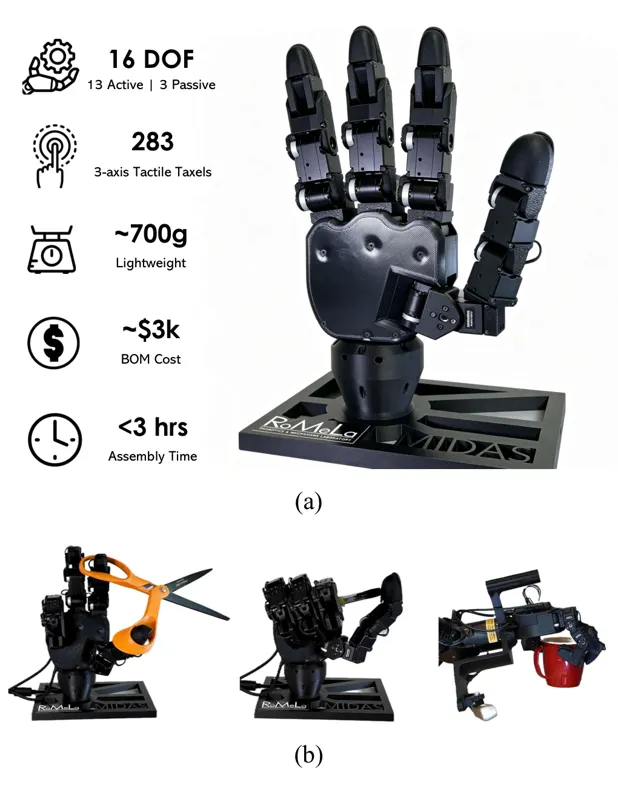
Dexterous manipulation is limited not only by algorithms but by a shortage of accessible hand hardware that combines human-scale morphology, ease of manufacturing or maintenance, tactile sensing, and practical cost. Existing dexterous hands tend to optimize some of these properties at the expense of others. We present MIDAS Hand, a low-cost, open-source, human-scale dexterous hand with integrated tactile sensing for manipulation research. MIDAS Hand provides 16 total degrees of freedom (DoF) with 13 active DoF, directly driven actuation with measurably low backdrive torque, and 283 three-axis tactile taxels in a compact 700 g package with a bill of materials under 3,000 USD. Built from 3D-printed components, it assembles in under three hours while providing the strength, repeatability, and maintainability needed for repeated real-world experiments. Alongside the hardware, we release a full stack: design files, build documentation, control and tactile Python APIs, simulation models, and retargeting and teleoperation pipelines. We characterize MIDAS Hand through workspace and grasp-taxonomy analysis, payload and reliability tests, backdrivability measurements, and teleoperation demonstrations with tactile sensing, showing that it offers a balanced, reproducible platform for tactile dexterous manipulation and human-to-robot data collection. Project page: https://midas-hand.com
Alvin Zhu, Mingzhang Zhu
RoboAtom: Large-scale Atomic-Action Supervision for Robot Learning
03Paper

RoboAtom: Large-scale Atomic-Action Supervision for Robot Learning

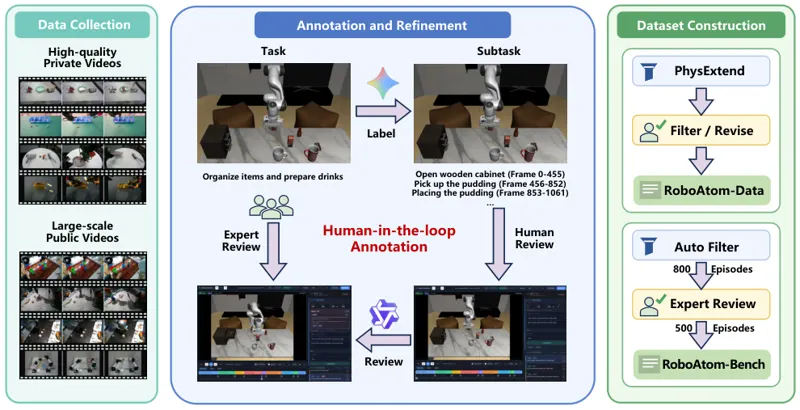
Fine-grained action annotations can support skill reuse and compositional generalization in robot policies. However, robot datasets typically provide task-level instructions without subtask annotations. Although some include subtask labels, inconsistent formats and conventions hinder cross-source joint training. We propose RoboAtom-Data, which adds unified, time-aligned atomic-action annotations to existing data from multiple sources, covering 1.45 million trajectories, 6.88 million skill-labeled segments, and 16,882.1 hours. Our pipeline combines a unified protocol, large-scale manual annotation, propagation across repeated executions with the same ordered skill sequence, and multi-stage quality control. We evaluate the dataset through automatic atomic-action annotation and robot control. We construct RoboAtom-Bench to standardize evaluation of skill recognition and temporal boundary localization. Trained on the annotated data, RoboAtom-Anno achieves better automatic annotation performance than all evaluated open- and closed-source models on both RoboAtom-Bench and the external WGO-Bench. For robot control, atomic-action supervision paired with hierarchical execution improves task success over task-level baselines on LIBERO-Long, LIBERO-Plus, and RoboTwin. We will release the data, benchmark, model, and construction pipeline to support further research on skill-level robot learning.
Xueyuan Wei, Xuanxu Wang
Training Reasoning Models in Simulation to Natively Use Real Robots
04Paper

Training Reasoning Models in Simulation to Natively Use Real Robots

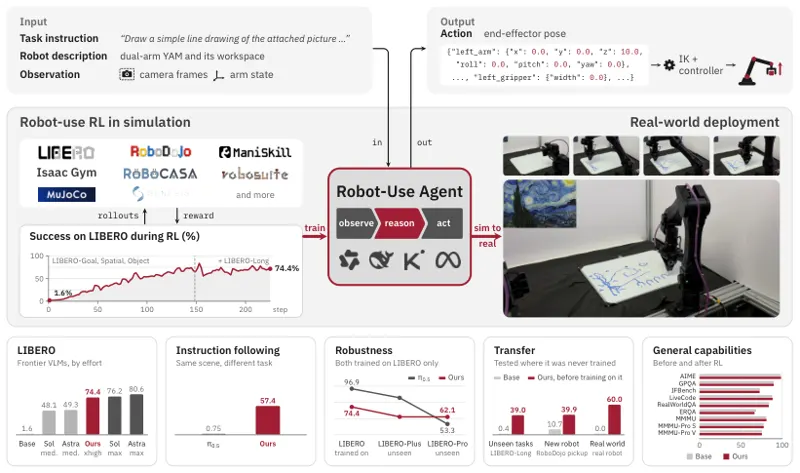
The authors train an open-weight 27B reasoning model to control real robots through simulation-only reinforcement learning and no demonstrations. PEAR uses robot-use reinforcement learning with next end-effector pose prediction; LIBERO success rises from 1.6% to 74.4%, and the trained model reaches 60% success on a real dual-arm robot.

Jiaming Tang, Zhuoyang Zhang

LLM

114

Foundation models: pre- and post-training, architecture and long context, inference serving and cost per token.

Harness

108

Agent runtimes: plugins and sandboxes, tool surfaces, skill systems, long-term memory and self-improvement.

AI Coding

117

Code generation, repair, refactoring, software engineering tasks

Skills

19
Developmentmattpocock/skillsFeatured

The 38 skills Matt Pocock uses every day for real engineering

Editor's takeSells parts, not a process: 38 SKILL.md behind a strict user/model-invoked contract, a SCOPE.md admission bar and a shared GLOSSARY.md; the spec-to-tickets-to-implement-spec pipeline is the most complete agentic engineering loop in this channel.

Daily-working set of the Total TypeScript author: 38 SKILL.md files (engineering 20, productivity 7, misc 4 frozen, in-progress 7) behind a user-invoked/model-invoked contract, a SCOPE.md admission bar and a shared GLOSSARY.md; installs as a Claude Code, Codex, Copilot or Gemini plugin, or an editable skills.sh copy.

Claude CodeCodexGemini CLI+2
claude plugin install mattpocock-skills@claude-plugins-official
Shellmattpocock289.9k
The 38 skills Matt Pocock uses every day for real engineering
Developmentobra/superpowersFeatured

Fifteen skills that give a coding agent a full development process

Editor's takeIts premise is that models lack process discipline, not coding ability. The single best idea to steal is 'Rulings, not stalls': decide by default, and stop for a human only when an action is irreversible, touches a security-sensitive surface, leaks outside the worktree, or the plan is already too broken to continue.

v6.4.1 (2026-09-18), MIT, 289k stars — the largest single skill repository of its kind. It chains brainstorming, spec writing, git-worktree isolation, planning, subagent execution, red-green TDD, two-way code review and verification-before-completion into one trunk workflow, and the README lists 16+ harnesses: Claude Code, Codex, Cursor, Gemini CLI, OpenCode, Kimi Code, Devin CLI and more.

Claude CodeCodexCursor
/plugin install superpowers@claude-plugins-official
Shellobra289.2k
Fifteen skills that give a coding agent a full development process
Official & Collectionsanthropics/skillsFeatured

The official repo from the format's author: 19 skills plus spec and template

Editor's takeIf you want to know how a SKILL.md is actually supposed to be written, read this instead of any second-hand tutorial. Two things to know first: docx, pdf, pptx and xlsx are source-available rather than open source (the other 15 are Apache-2.0), and the repo carries its own disclaimer — these skills are demos, so test them in your environment before trusting them with anything critical.

Anthropic's own implementation, 177k stars: 19 skills under ./skills plus ./spec (the Agent Skills specification, now at agentskills.io) and ./template as a scaffold. Its definition of a skill is folders of instructions, scripts and resources loaded dynamically, and progressive disclosure comes straight from here.

Claude Code
/plugin marketplace add anthropics/skills
Pythonanthropics177.3k
The official repo from the format's author: 19 skills plus spec and template
Design & Frontendnextlevelbuilder/ui-ux-pro-max-skillFeatured

Design knowledge as searchable local data: 79 styles, 192 palettes, 119 UX rules

Editor's takeIts sharpest self-description is that models can write CSS but lack a taste database. Ten rule categories are ordered by severity, with Accessibility and Touch & Interaction first as CRITICAL and Charts last — that ordering is the stance. The Design System Generator runs five parallel searches, and the repo states plainly: do not persist unverified output, so a generated design system has to be checked before it lands in your repo.

v2.13.0, MIT, 129k stars, site uupm.cc. Instead of lecturing the model it ships structured catalogues the agent queries before writing code: 79 UI styles, 192 palettes with reasoning, 74 type pairings, 119 UX rules, 105 icon suggestions, 17 GSAP presets, 25 chart types, 22 stacks and 34 landing-page patterns.

Any agent
npx ui-ux-pro-max-cli init --ai claude
Pythonnextlevelbuilder129.3k
Design knowledge as searchable local data: 79 styles, 192 palettes, 119 UX rules
KnowledgeGraphify-Labs/graphifyFeatured

Map the whole project into a queryable knowledge graph instead of grepping

Editor's takeThe design that matters most: every edge is labelled EXTRACTED or INFERRED, so you can tell what the source explicitly contains from what the tool inferred — which makes an agent's conclusions auditable, a hard requirement in production. It is not a vector index: no embeddings, no vector store, a real graph you can explain, path and query. In its own benchmark, building the graph costs zero LLM spend and ingest is an order of magnitude cheaper, a structural win from local parsing.

YC S26, Apache-2.0, 120k stars, Python 3.10+. /graphify . maps code, docs, PDFs, images and videos into a graph and emits a clickable graph.html, a human-readable GRAPH_REPORT.md and a machine-readable graph.json. Code goes through tree-sitter AST parsing (about 40 languages): deterministic, no LLM calls, nothing leaves the machine.

Claude CodeCodexCursor
uv tool install graphifyy && graphify install
PythonGraphify-Labs119.9k
Map the whole project into a queryable knowledge graph instead of grepping
Design & FrontendLeonxlnx/taste-skillFeatured

Taste Skill: 13 anti-slop frontend skills that turn AI tells into countable rules

Editor's takeThe lesson worth stealing is rules expressed as countable mechanical tests: eyebrow count ≤ ceil(sections/3), bento cells equal to content items, zero em-dashes on the page, palette families rotated across projects. Each one aims straight at the model repeating itself instead of stopping at an adjective. The repo is equally honest about its edges: v2 self-declares experimental and is still moving, §13 explicitly excludes dashboards, data tables, multi-step wizards, code editors and native mobile, and the only test in the repo guards the source-invocation semantics of the skill.sh shell helper rather than the design rules.

One MIT repo holding 13 skills: ten that output code and three that output reference images only, all installed into Claude Code / Codex / Cursor with a single npx skills add. The default design-taste-frontend v2 (experimental) is a 1,228-line SKILL.md: first the model must emit a one-line "design read", then it sets three dials (DESIGN_VARIANCE / MOTION_INTENSITY / VISUAL_DENSITY), then it implements against 14 chapters of hard rules - install the official package for corporate briefs, label aesthetic borrowings in comments, zero em-dashes anywhere on the page, eyebrow quota computed from section count, bento cells equal to content items, and finally a 50-plus box pre-flight check. The repo also ships research/laziness, a literature directory using controlled studies to explain why models cut output short.

Claude CodeCodexCursor
npx skills add https://github.com/Leonxlnx/taste-skill
JavaScriptLeonxlnx94.8k
Taste Skill: 13 anti-slop frontend skills that turn AI tells into countable rules

Leaderboard

519
Artificial Analysis Intelligence IndexOfficial intelligence index (higher is better)
Claude Fable 5.2 (max)64.56
Claude Fable 5.2 (xhigh)62.22
Claude Fable 5.2 (high)61.82
Gemini 4 Carbon (high)60.03
Claude Opus 5.5 (max)59.11

Source · artificialanalysis.aiofficial Intelligence Index v5synced Nov 14, 2026

Image Generation

67

Text-to-image, image editing, consistency and controllability

Audio & Video

178

Video and speech/audio: physical and temporal coherence for text/image-to-video, TTS and voice cloning, music generation and ASR.

3D & World Models

399

3D asset generation, scene reconstruction, long-horizon world prediction

Design & Frontend

87

Visual design, UI components, web and slide layout

Docs & Slides

19

Slides, Word, Excel, PDF generation and editing

Blog

137

Agent Studio

7

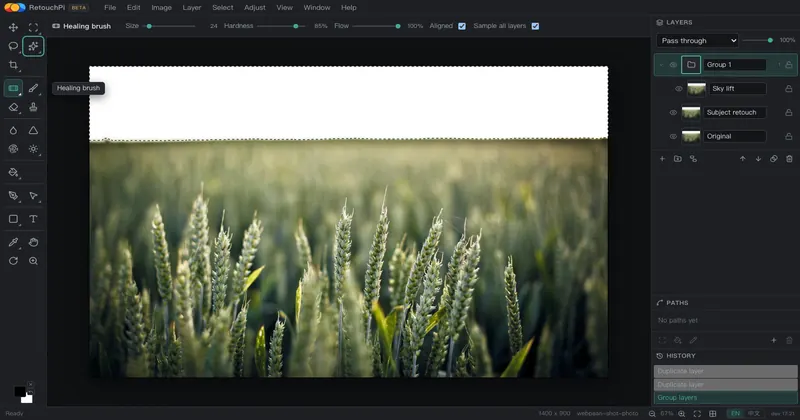
RetouchPi

Fifty-four professional tools, layers and masks, PSD files that open and save back - all in the browser, nothing to install.

retouchpi.com · 54 pro tools · PSD read and write · AI generate & edit

ThreeDream simulation engine

Built for games and for physical AI: an ultra-realistic, ultra-high-performance simulation environment with ultra-low-cost procedural data; Unreal-grade visuals open and play in the browser, bridging the physical world and intelligent agents.

Games meet physical AI · Unreal-grade on the web · Open and play

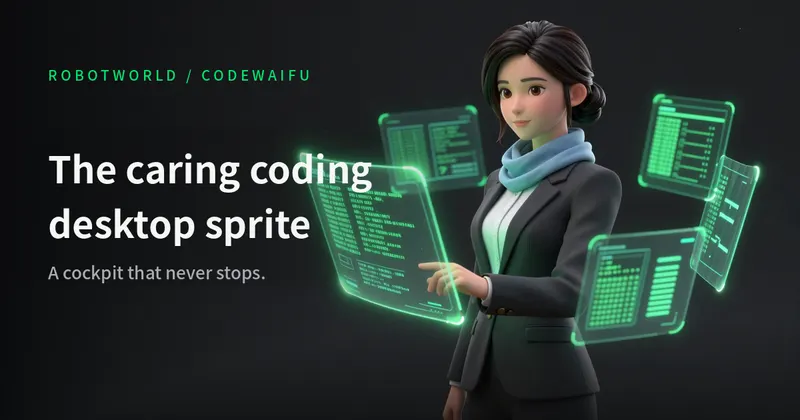
CodeWaifu, your caring coding desktop sprite

A caring coding sprite on your desktop and a cockpit that never stops: the work resumes itself after a crash or a reboot. Every coding terminal, ssh session and local shell in one tree, every start, finish and permission request reported in time. Open source, one-line install.

Your caring coding desktop sprite · Resumes after crash & reboot · First-rate terminal / ssh / shell

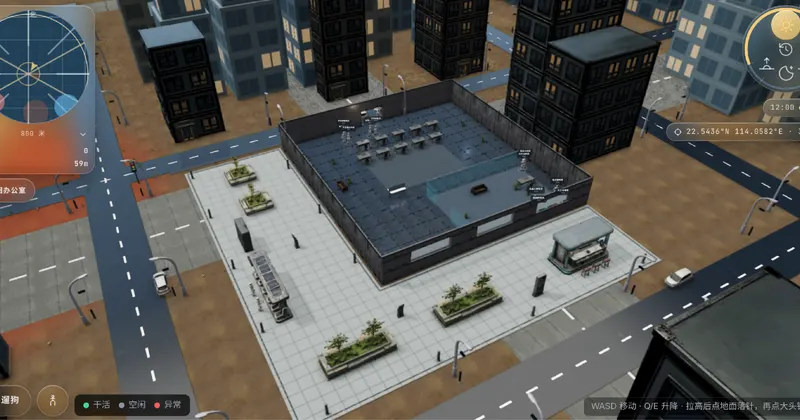
Agent digital twin office

A 100 km 3D city that opens in seconds — crawling, blogs, papers, industry and investment analysis, all watchable in one digital twin.

100km city · opens in seconds · Live task stream · Agent-maintained

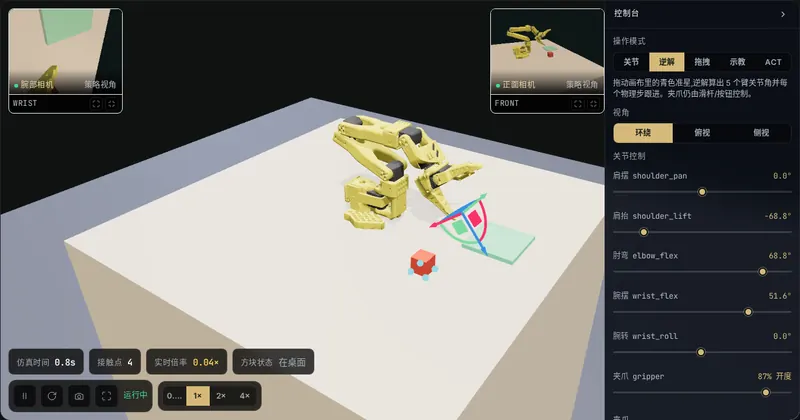
Robotic arm workbench

An SO-101 6-DoF arm running MuJoCo physics in your browser: joint teleoperation, IK end-effector dragging and gripper pick-and-place into a basket. No install.

MuJoCo WASM physics · SO-101 · 6 DoF · Contacts / telemetry HUD

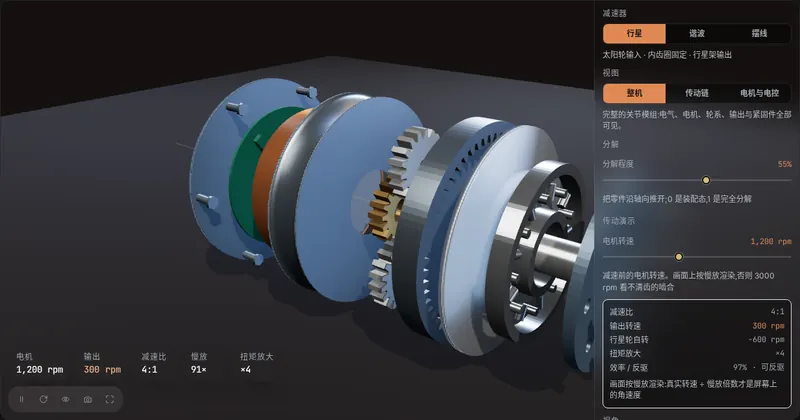
Joint actuator anatomy lab

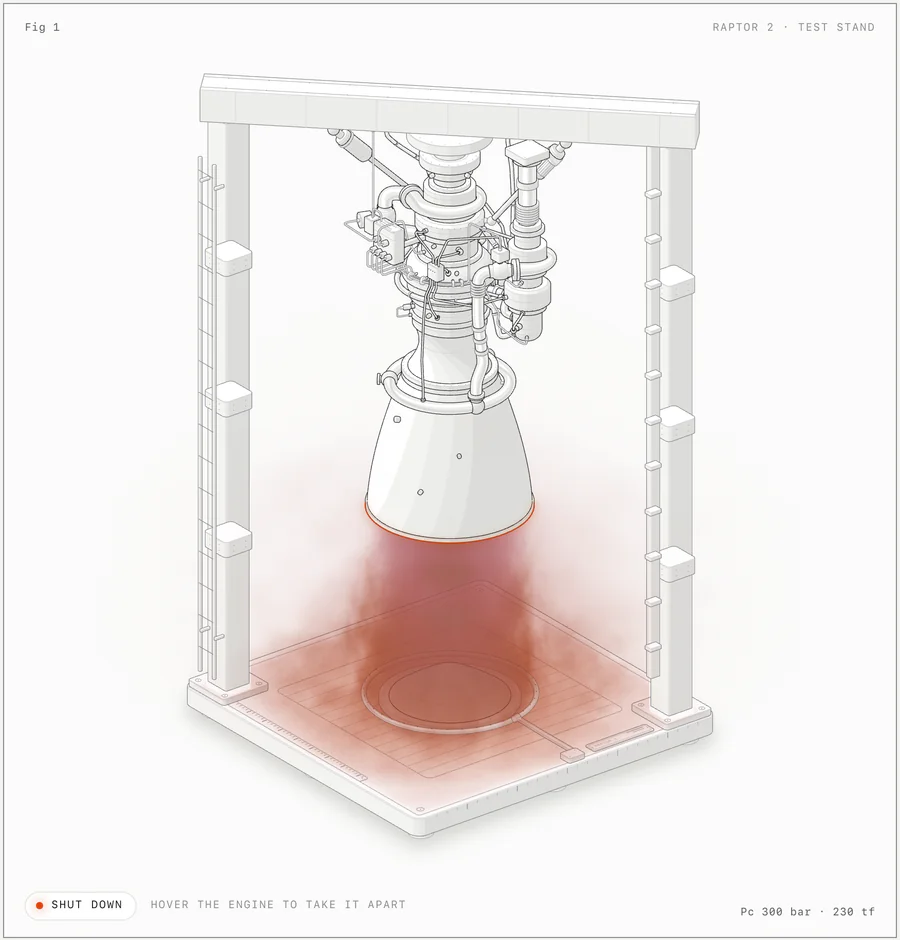
Take a humanoid joint module apart layer by layer: brushless motor, magnetic encoder, planetary / harmonic / cycloidal drive and output flange. Switch architectures on one page — exploded view plus analytic kinematics.

Three gearbox types · Planetary / harmonic / cycloidal · Analytic kinematics · explode

AI Games

5

Under constructionThe games system is still under construction — everything listed starts in-page, and the library keeps growing.

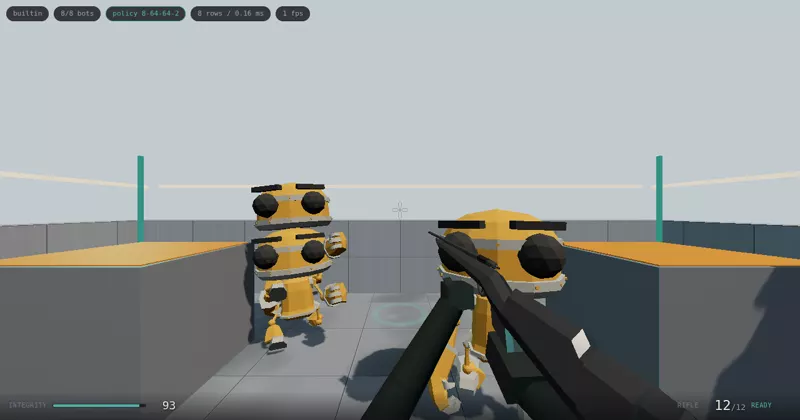
ThreeDream FPS arena

ThreeDream FPS arena

A first-person match where every bot across from you is driven live by a policy this repo trained, the whole round stepping at a fixed 60 Hz: builtin, Rust/wasm or Rapier behind one physics interface, nothing scripted.

WASD move · mouse look · left-click fire · shift sprint · R reload · esc release

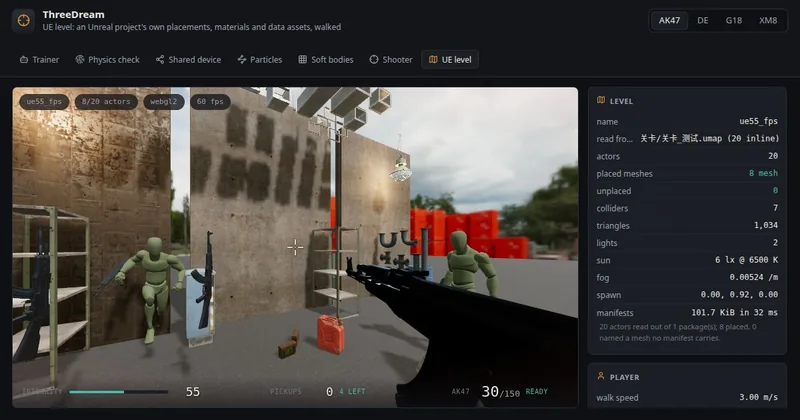
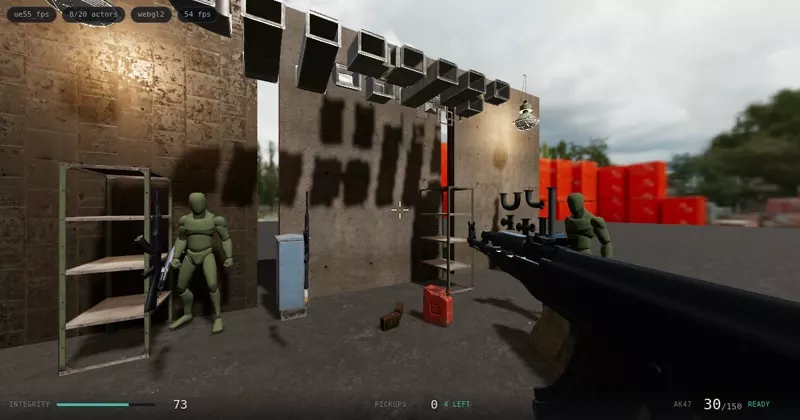
ThreeDream UE level

ThreeDream UE level

Unreal 5.5's first-person test map, running same-origin in the browser: the level, the materials, the lights and four weapon data assets are read out of the project's own .umap / .uasset bytes, six soldiers are driven by a four-state brain on one fixed 60 Hz step, and the sidebar lists every substitution the page had to make.

WASD move · mouse look · left-click fire · shift sprint · space jump · R reload · F pick up · esc release

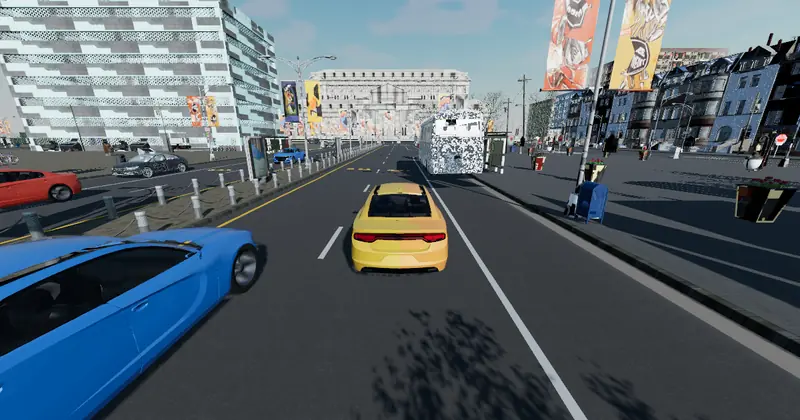
ThreeDream CARLA town drive

ThreeDream CARLA town drive

The whole of CARLA Town10HD read out of its .umap and OpenDRIVE road bytes, 4,474 actors back on the project's own coordinates; 32 cars decide live over the same lane graph - car-following, braking, lane changes - and you sit in one of them, on the wheel or on autopilot.

W throttle · S brake · A D steer · space handbrake · T autopilot · C camera

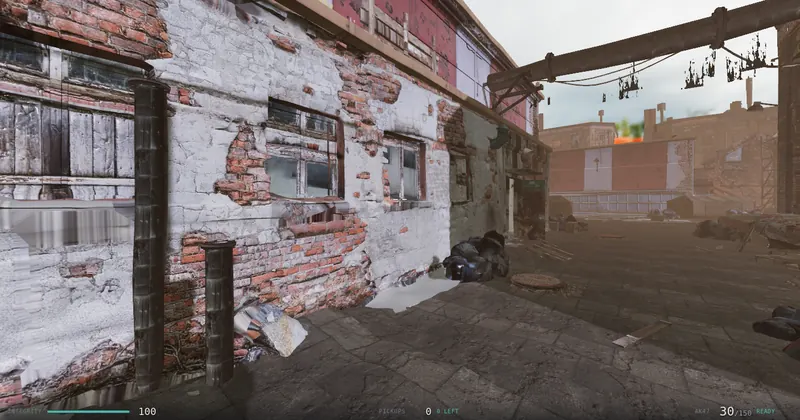
ThreeDream factory town

ThreeDream factory town

The abandoned-factory town's bytes come from two places: 3,571 actors and a 509x509 landscape heightfield read out of the Unreal project's own mainmap.umap, 3,283 meshes resolved through an unlicensed content pack pinned by revision on its own mirror; six soldiers run live on a four-state patrol / engage / advance / down brain over one fixed 60 Hz step, standing at random walkable spots wave by wave and getting back up elsewhere once downed, with four guns on the ground each wave to swap for with F and a kill quota that opens the next one (?arena=0 gives the same town back without rounds); and the sidebar lists the 101 placements still missing their mesh instead of hiding the holes.

WASD move · mouse look · left-click fire · shift sprint · space jump · R reload · F pick up · esc release

ThreeDream Solis Reach

ThreeDream Solis Reach

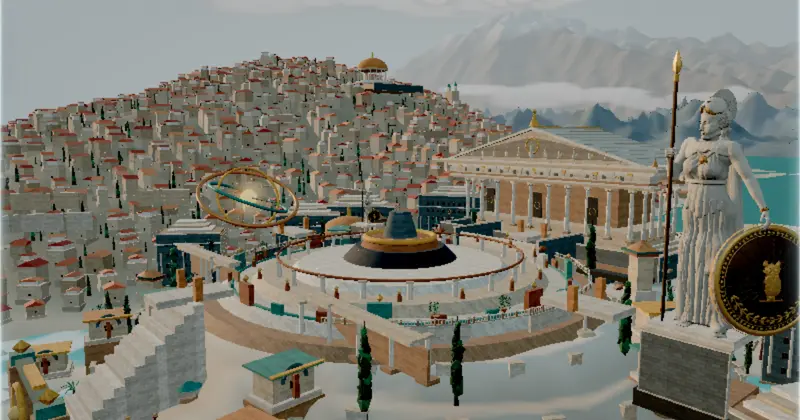
A whole mirror-salt solar city generated at runtime: 4,570 built pieces, 3,197 hillside homes, 71 heliostats and a three-ring armillary surround one live sea; 11 salt skiffs query the same heightfield that is drawn every frame, and orbit or fly cameras let you cross the scene - this is not a pre-baked tour.

drag orbit · wheel zoom · WASD fly · E Q up/down · shift boost · mouse look

Frequently asked

What is this site?
An AGI progress digest: paper deep reads, open-source projects, demo videos and leaderboards across models, agents and runtimes, skills, multimodal and embodied AI.
Where does the content come from?
Public sources: arXiv papers, official releases and blogs, GitHub repositories, demos on X and YouTube, and evaluators' own leaderboards. Every entry keeps its source link and author credit.
Are the paper and project write-ups summaries?
No. Papers are written up from the full text as bilingual long reads with formulas, experiment tables and method diagrams; open-source projects are read through their README and source before a bilingual write-up with a hands-on verdict.
Where do the leaderboards come from?
From each evaluator's own official board, synced on a schedule, with scrape and official-update timestamps shown.
Can I cite this site?
Yes — cite the canonical URL each page declares. Third-party papers, videos and images remain the copyright of their original authors.

As an Amazon Associate, we earn from qualifying purchases.