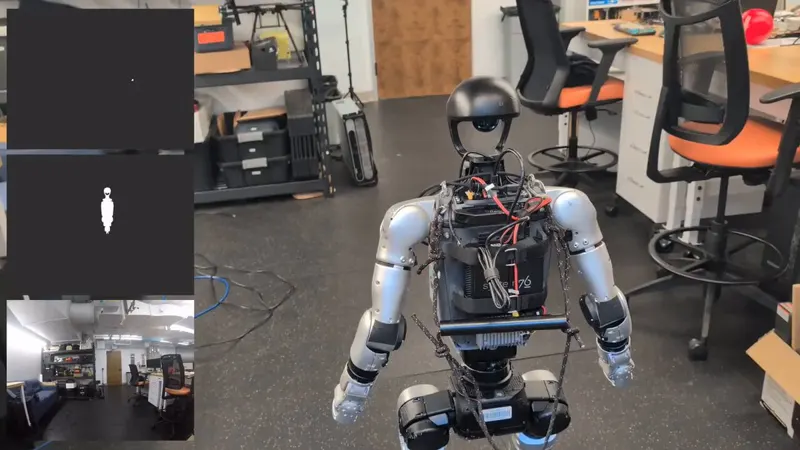
0:39Caltech 新研究:解耦导航与本体,让人形机器人走得更稳——ROM-Nav 两阶段安全导航@LeoKharon · 14次播放 · 2026-10-03人形机器人导航ReinforcementLearning
 0:39