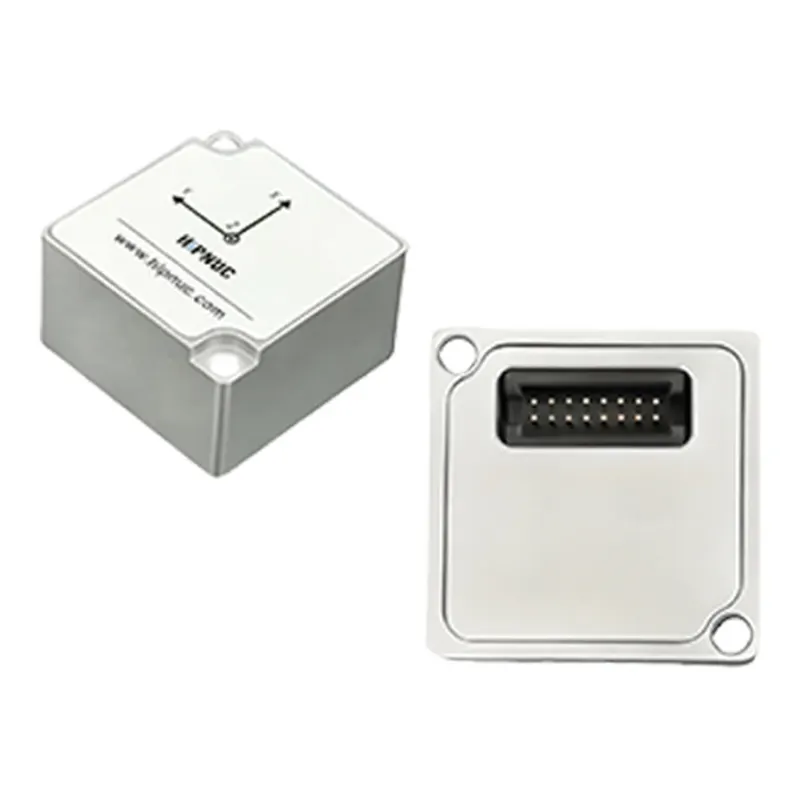
HiPNUC (Beijing) HI71 is a tactical-grade compact inertial module in a 24×24×14 mm aluminum case with board-to-board connectors for easy integration. Four variants: T2 (VRU), T4 (AHRS + barometer), M4 (MRU heave) and N4 (INS): gyro ±300 °/s with 0.3 °/h bias instability and 0.0004 °/s√Hz XY noise density; accelerometer ±16 g with 10 μg bias instability; T4/M4/N4 add a ±20 Gauss magnetometer and 300~1200 hPa barometer. Pitch/roll 0.05~0.1°, UART up to 1000 Hz and CAN at 200 Hz, binary/CANopen/Modbus/NMEA protocols with PPS/UTC sync, 3.6~5 V supply at 370 mW.
COMPONENT
HiPNUC (Beijing) HI06 is a tactical-grade compact SMD attitude module of 15×15.2×2.6 mm with full-temperature calibration of scale factor, cross-axis alignment and bias. Gyro ±4000 °/s with 0.0025 °/s√Hz noise density and bias instability as low as 0.9/1.0/1.1 °/h, up to 400 Hz 3dB bandwidth; accelerometer ±32 g with 0.011~0.05 mg bias instability; T3/N3 variants add a ±2000 μT magnetometer. Static pitch/roll 0.08~0.12°, UART at 1000 Hz and CAN at 200 Hz, PPS/UTC sync, 3.2~5.5 V supply at 220 mW, with official ROS, C and QT example code.
HiPNUC (Beijing) HI05 is a full-featured, low-noise SMD attitude module of 15×15×2.6 mm and under 1.5 g, offering IMU/VRU/AHRS/INS variants with optional barometer. Gyro ±4000 °/s with 0.0025 °/s√Hz noise density, 4/1.5/1.7 °/h bias instability and up to 400 Hz 3dB bandwidth; accelerometer ±32 g with 0.012~0.016 mg bias instability. R3/N3/R4/N4 variants add a ±2000 μT magnetometer, and R4/N4 a 300~1200 hPa barometer. UART at 1000 Hz and CAN at 200 Hz, 3.2~5.5 V supply, 195~205 mW, with PPS/UTC time synchronization.
HiPNUC (Beijing) HI02 is a compact SMD 6-axis attitude module built for cost-sensitive mobile platforms, measuring just 15×15×2.6 mm with full-temperature factory calibration. Gyro ±2000 °/s with 2.5/3.2/3 °/h three-axis bias instability; accelerometer ±24 g; static pitch/roll accuracy 0.1~0.2°. UART(TTL) output at 200 Hz, 3.2~5.5 V supply, −40 to +85 °C operation, and onboard EKF fusion delivering both calibrated raw data and fused attitude — aimed at robot vacuums, lawn mowers and pool cleaners.
IMU-G-1020-S is an industrial 6-axis IMU module from Shenzhen SZLIGHT (SZLCTEK), built on a purple PCB (V1.0, 2025-08-29) around a HiPNUC HI14-series MEMS inertial chip (silkscreen HIPNUCHI14). The HI14 family offers gyro ranges of ±2000 to ±4000 °/s and accelerometer ranges of ±24 to ±32 g, outputs fused Euler angles and quaternions at up to 1000 Hz over UART/USB, and applies full-temperature compensation from -40 to +85 °C for harsh outdoor environments. This board breaks out 5V/GND, TXD/RXD, an RSYNC sync pin and RS-485 (485A/485B) through an 8-pin connector, targeting robot attitude sensing and stabilization. No public page exists for the module vendor, so core specs follow the official HiPNUC HI14 datasheet.
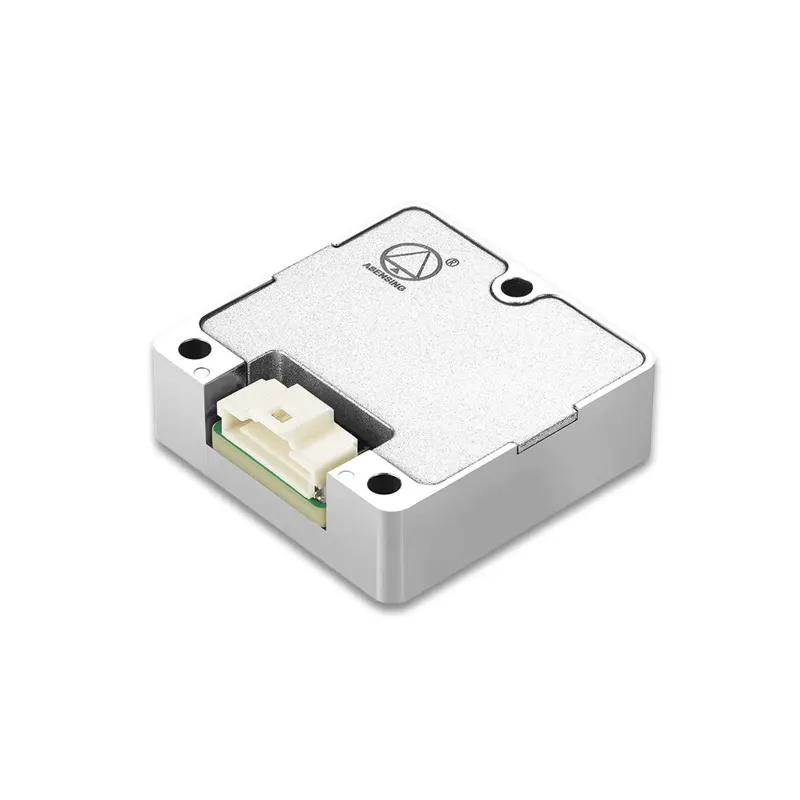
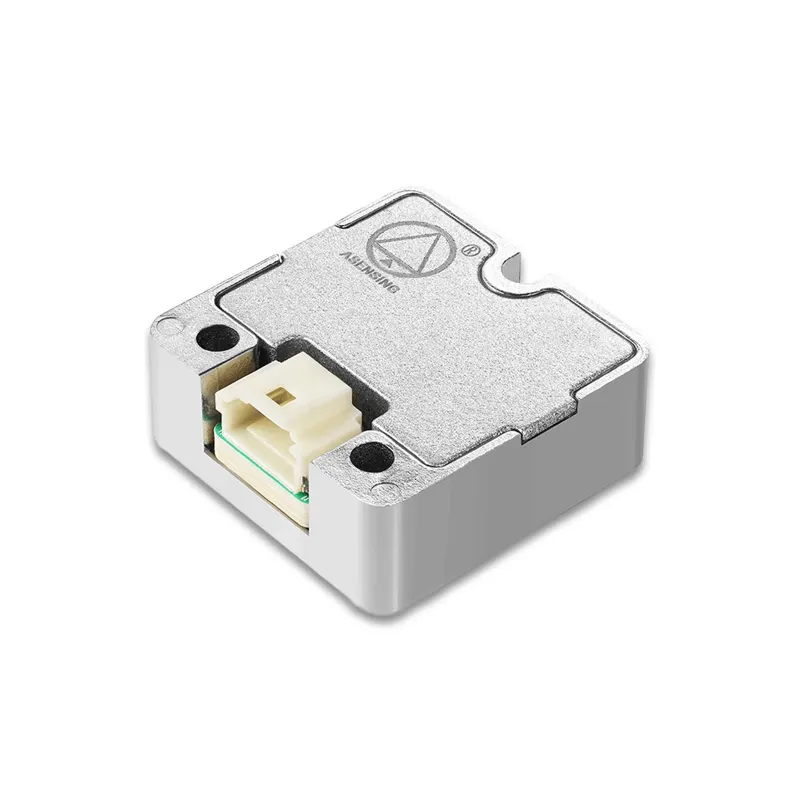
Asensing (Guangzhou) IMU5305 is a general-purpose industrial 6-axis IMU: gyro ±500 °/s with bias instability ≤2 °/h and angular random walk ≤0.18 °/√h; accelerometer ±16 g with bias instability ≤0.035 mg. Measures 30×30×10 mm, weighs 26.2±1 g, 5±0.5 V supply ≤0.1 A, UART+PPS interface (SPI optional) — a cost-effective domestic choice for attitude estimation on robots, AGVs and unmanned platforms.
Asensing (Guangzhou) IMU5146 is an automotive-grade high-precision 6-axis IMU: gyro ±500 °/s (±2000 °/s optional) with bias instability ≤1.2 °/h and angular random walk ≤0.14 °/√h; accelerometer ±16 g (±32 g optional) with bias instability ≤0.015 mg; roll/pitch accuracy ≤0.1° and heading accuracy ≤0.2°, with optional ±49 Gauss magnetometer. Measures 22.4×22.4×8.8 mm, weighs 14±1 g, 5 V supply ≤50 mA, UART+PPS output. Asensing is a leading domestic automotive inertial-positioning vendor; the module also fits attitude estimation on robots and robot dogs.
HiPNUC (Beijing) HI12 is a compact industrial 6-axis IMU for robotics, officially listed on the vendor's humanoid-robot and robot-dog solution pages. Gyro ±2000 °/s with 2.5/3.2/3 °/h three-axis bias instability at H1 grade; accelerometer ±24 g with 0.021~0.032 mg bias instability; static pitch/roll accuracy 0.15~0.2°. UART output at 1000 Hz and CAN at 200 Hz, measuring only 22×22×10 mm with 3.2~5.5 V supply, 240~300 mW power and −40 to +85 °C operation — suited to attitude estimation and motion control on humanoid robots, robot dogs and small mobile platforms.
Wit Motion (Shenzhen) WT901 is its classic 9-axis attitude module combining a 3-axis accelerometer, 3-axis gyro and 3-axis magnetometer, using MEMS sensing with proprietary Kalman-filter sensor fusion to output angles, rates, acceleration, magnetic field and quaternions at up to 200 Hz. Accelerometer ±16 g range with 0.0005 g/LSB resolution and 0.75~1 mg RMS noise at 100 Hz bandwidth; gyro ±2000 °/s with 2.24 °/h bias instability (Allan variance) and 3.19 °/h zero-bias stability; 0.2° tilt accuracy and 0.1° heading accuracy without magnetic interference; default UART 115200 bps, -40 to +85 °C operation. Compact and affordable, it is widely used for attitude estimation and motion control in humanoid robots, robot dogs, drones and research.
As an Amazon Associate, we earn from qualifying purchases.