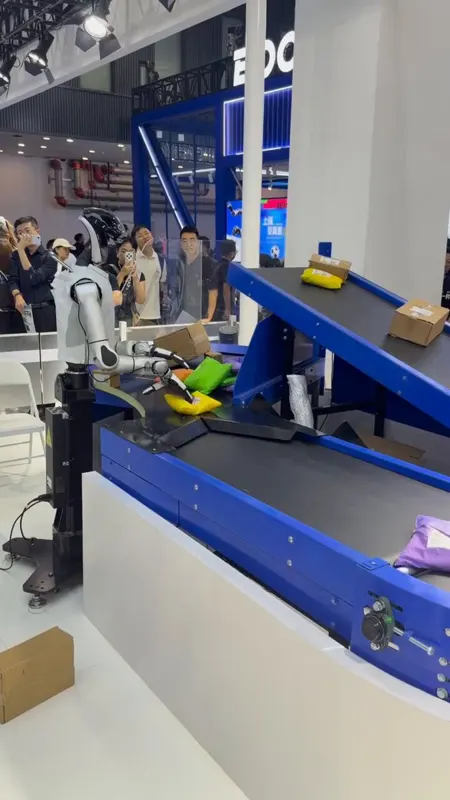
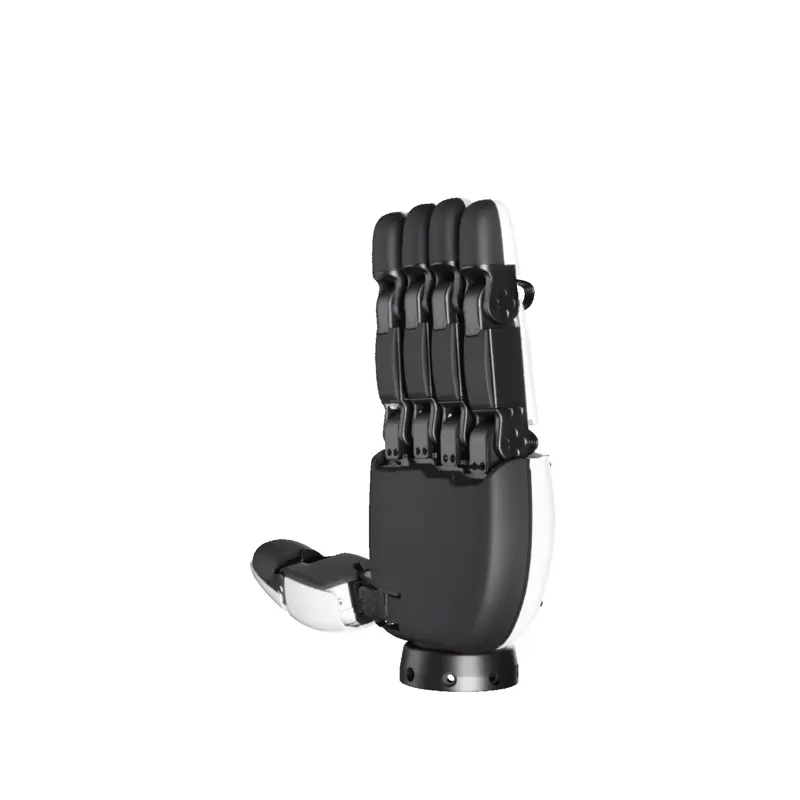
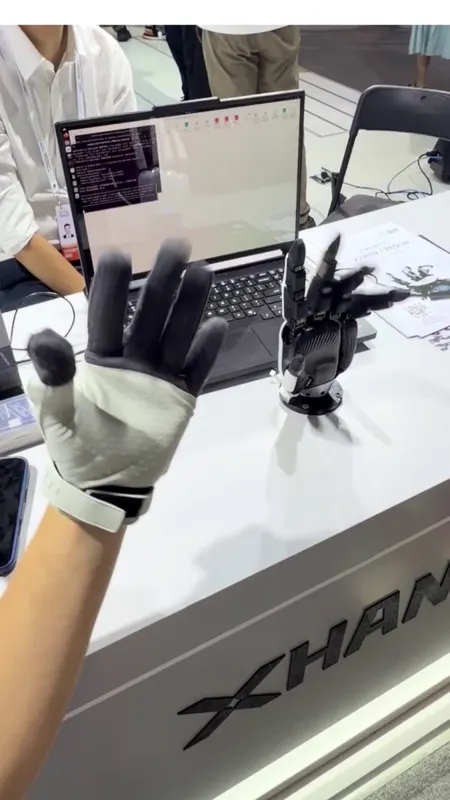
RobotEra XHAND 1 PRO Dexterous Hand
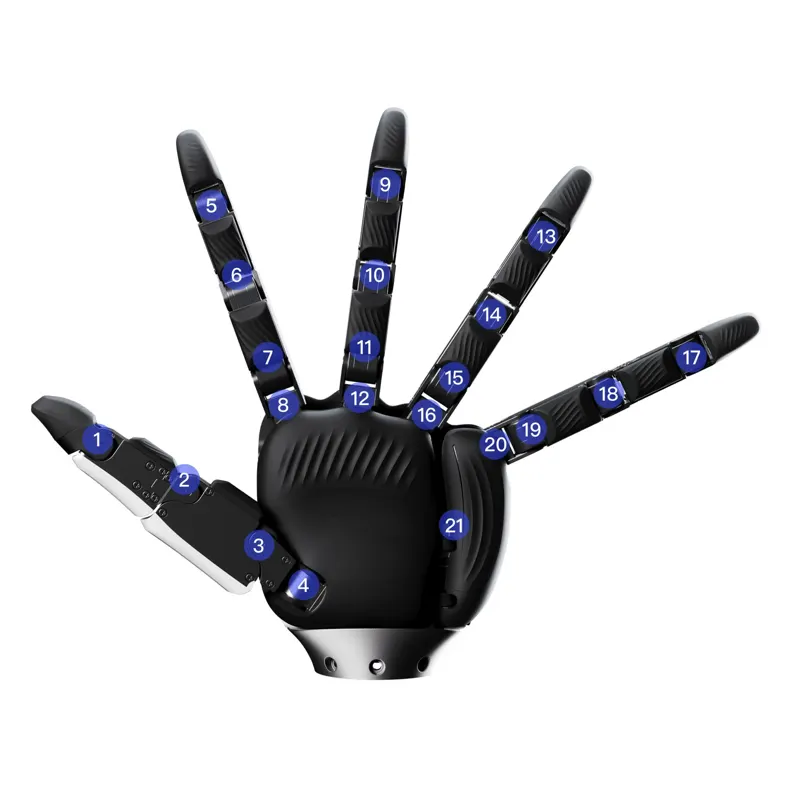
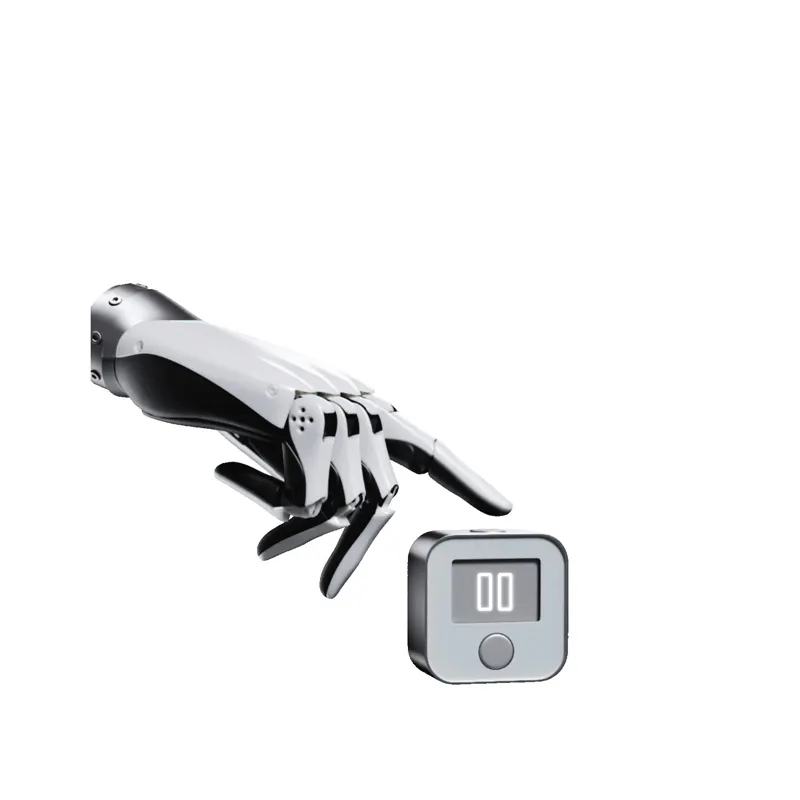
Flagship hand at 0.884 kg with 21 fully direct-driven and back-drivable active DoF, 160 mm maximum grasp diameter and 135° five-finger spread. 18 three-axis tactile sensors (5 fingertip, 10 finger-belly, 3 palm) cover 0.1-25 N at 0.01 N resolution with 10 mm proximity sensing; joint backlash under ±0.25 mm, ±0.1 mm repeatability, over 200k loaded cycles, above 5 Hz open-close and MIT, feedforward force, position and drag-teaching control modes.
COMPONENT
Dexterous HandRobotEraXHAND 1 PROFull Direct DriveTactile Sensing
 0:50