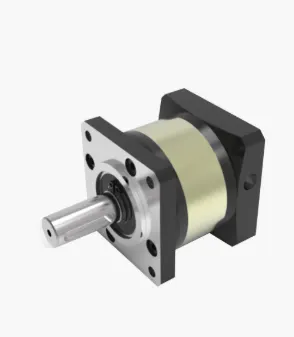
10:1 planetary gearbox for 14 mm-shaft NEMA 34 motors A straight-tooth planetary gearbox in the Leadshine PLF family.
COMPONENT
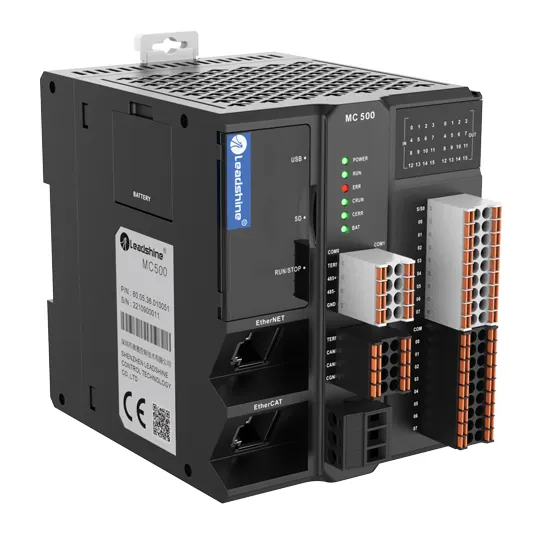
8-axis EtherCAT motion PLC with six local pulse axes A motion-control PLC supporting absolute and relative positioning, speed and torque control, electronic cams and interpolation.
4.3-inch 800 ×480 industrial touch-panel HMI A 4.3-inch industrial HMI for machine operation and status display.
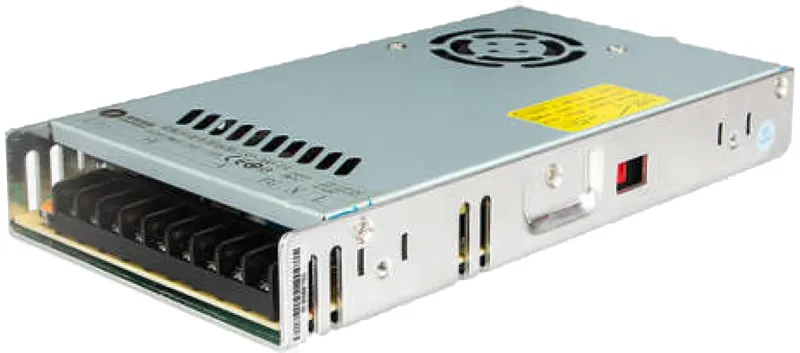
400 W power supply with 60 VDC output A compact power supply with selectable AC input ranges and a 60 VDC output.
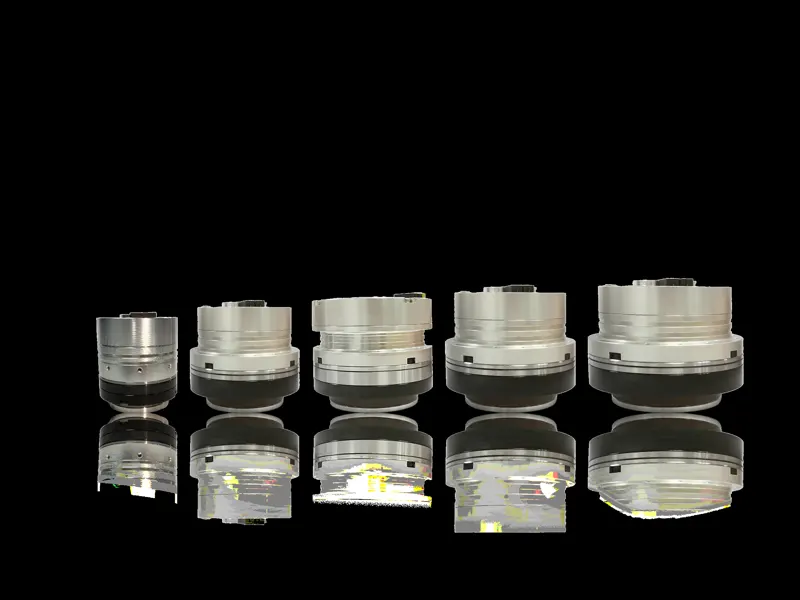
Compact 52 mm harmonic-drive actuator A compact harmonic-drive actuator from Leadshine’s HJ2 family for integrated robotic motion.
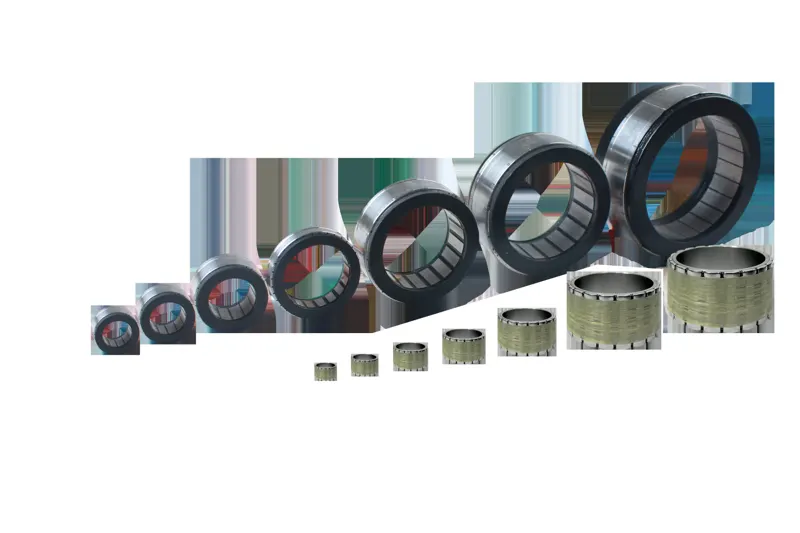
FM2-family frameless torque motor for robotic integration FM2 frameless torque motors are designed for compact robotic joints, including humanoid and collaborative robots. Leadshine describes the series as using an updated electromagnetic design for lower temperature rise and improved continuous torque.
220 VAC servo motors with 23-bit magnetic absolute encoders The ELM1 family uses permanent-magnet rotors and covers a range of machine-motion applications.
EtherCAT five-phase stepper drive, 20–50 VDC, 2.2 A An EtherCAT drive in Leadshine’s DM5 five-phase stepper family for networked motion control.
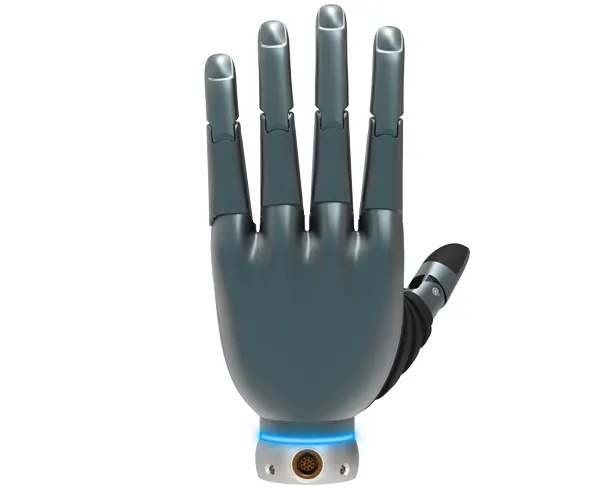
RS485 dexterous hand with 11 degrees of freedom A five-finger robotic hand driven by brushless coreless motors and worm gearing. This RS485 variant has 11 degrees of freedom, including 6 active degrees of freedom.
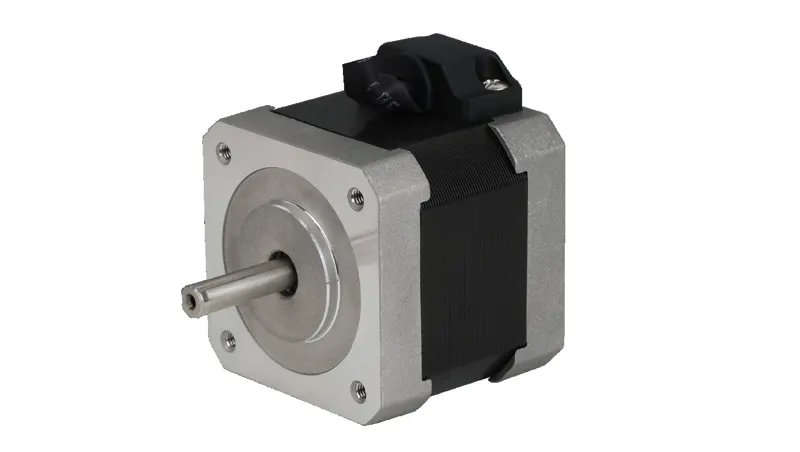
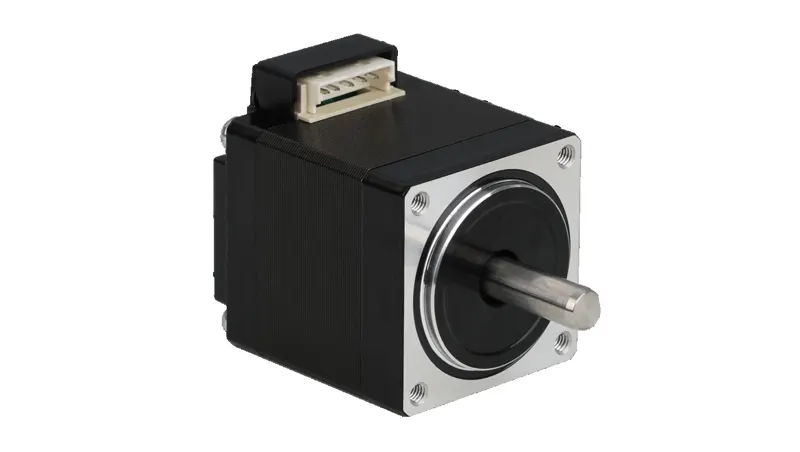
425CM high-end five-phase stepper motors in a 42 mm frame. 425CM03: 0.3 N·m holding torque, 1.8 A, 41 mm body, 0.3 kg; smoother low-vibration five-phase operation, IP40, RoHS; for medical devices, precision stages and light robot joints.
285CM high-end five-phase stepper motors in a miniature 28 mm frame. 285CM005: 0.05 N·m holding torque, 1.2 A, 32 mm body, 0.1 kg; five-phase design for lower vibration and finer resolution, IP40, RoHS.
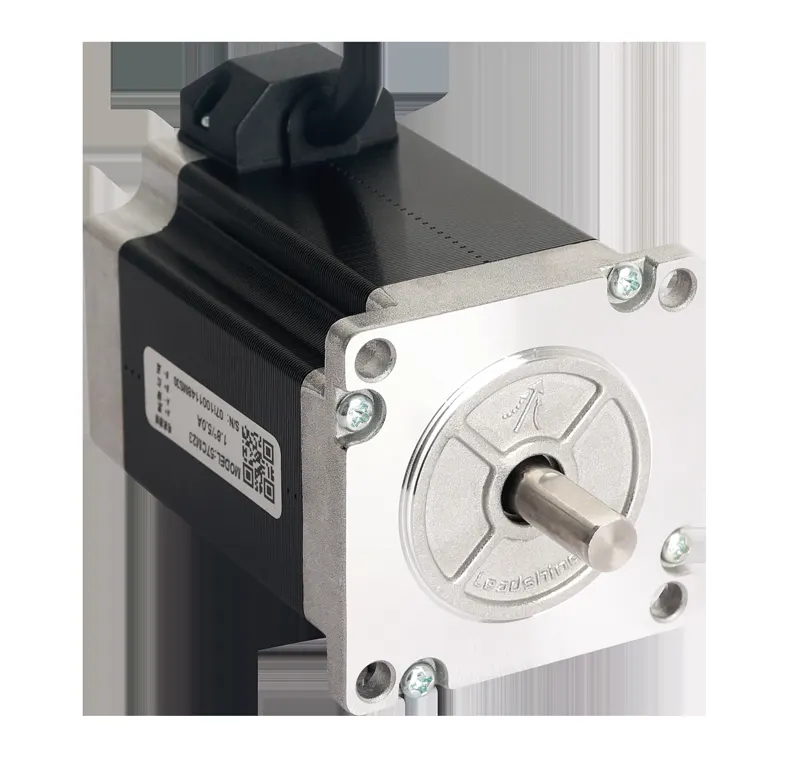
57CM standard two-phase stepper motors (NEMA 23 class). 57CM06: 0.6 N·m holding torque, 3 A rated, 41 mm body, 0.48 kg, IP40, CE/RoHS; for automation equipment and auxiliary robot axes.
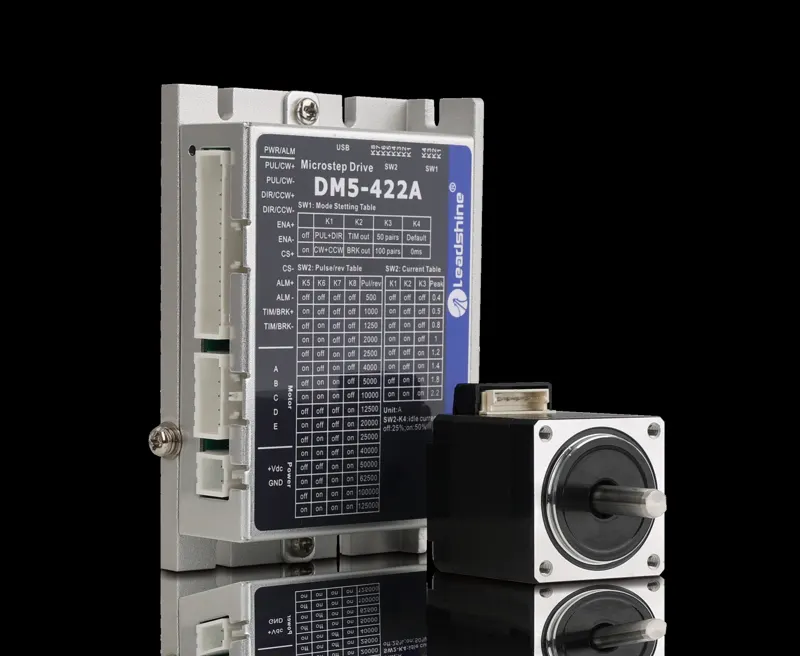
DM5 high-end five-phase stepper drives, 24-36 VDC. DM5-422A: 2.2 A peak, matches frame-28 motors, 1 MHz pulse input, TYPE-C debug with Motion Studio, 4 DI / 2 DO, pulse/direction/enable and microstep configuration.
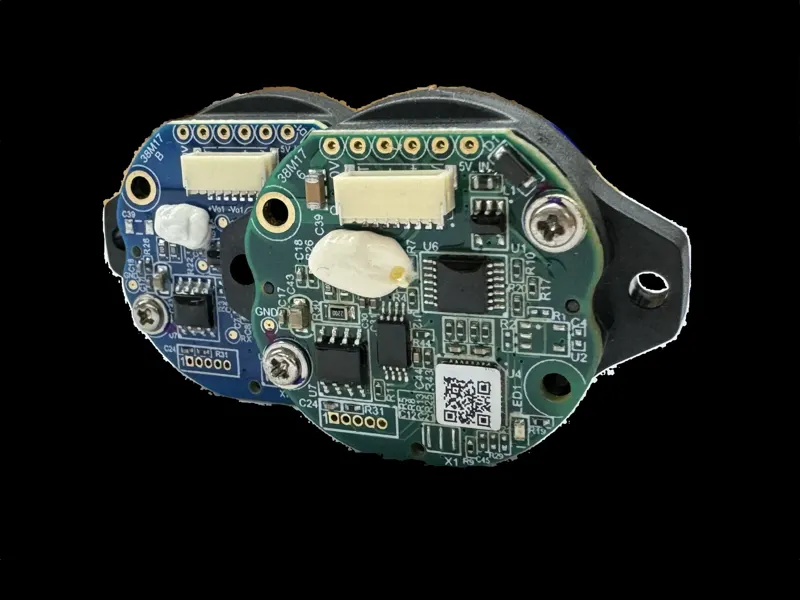
M17M standard 17-bit split magnetic-electric absolute encoders: 17-bit single-turn, 16-bit multi-turn, 5 V, RS485 at 2.5 Mbps. Strong vibration/shock/contamination resistance for reliable servo feedback in automation, robotics and logistics.
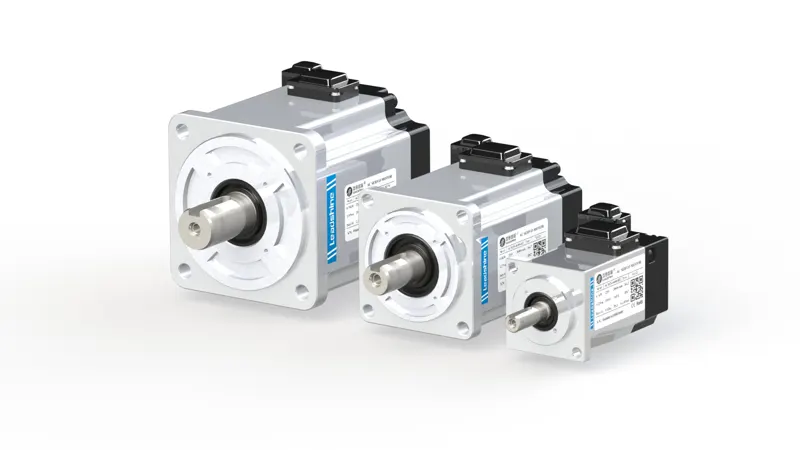
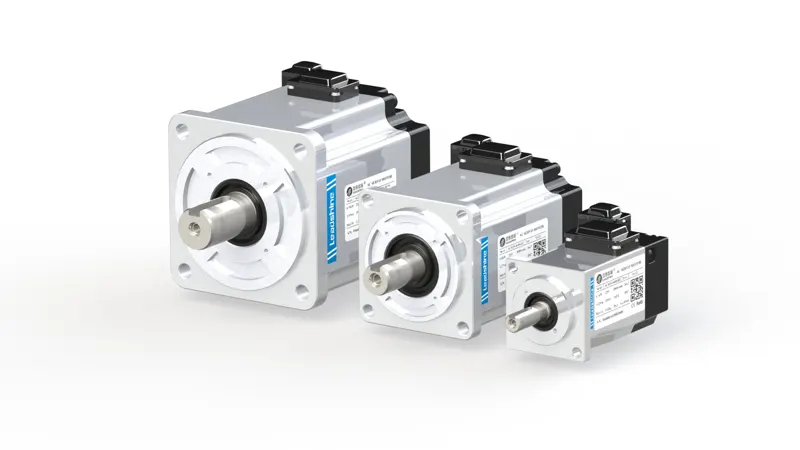
ACM2H general-purpose AC servo motors, 50-1000 W, frames 40-80 mm, up to 6500 rpm, silver body, plug-in connectors, IP67, 24-bit encoder standard, CE/UL. Example ACM2H-04A5: 50 W, 3000 rpm, 0.16 N·m.
ACM2L general-purpose AC servo motors, 30 W-5 kW, frames 25-130 mm, up to 7000 rpm, 24-bit encoder standard, plug-in connectors, IP67, CE/UL. Example ACM2L-0401: 100 W, 3000 rpm, 0.32 N·m.
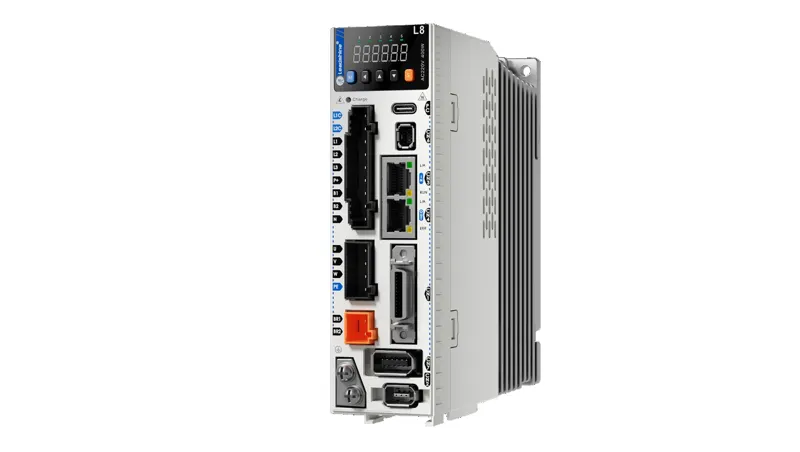
L8EC high-end EtherCAT rotary AC servo drives: 3.5 kHz velocity loop bandwidth, 125 us bus sync cycle, built-in brake drive and SIL3 STO, full-closed-loop/gantry/super-following modes. AC220 1/3-phase; L8EC-100F rated 100 W, 1.2/4.8 A.
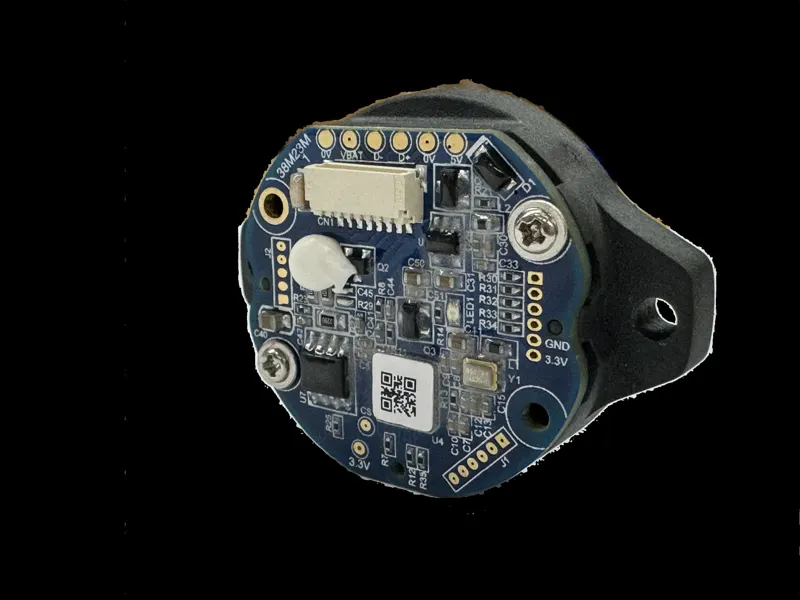
M23M high-performance split magnetic-electric absolute encoders: 23-bit single-turn, 16-bit multi-turn, 5 V supply, RS485 at 2.5/5 Mbps. Magnetic sensing gives strong vibration, shock and contamination resistance for servo feedback in robotics, laser, woodworking and logistics equipment.
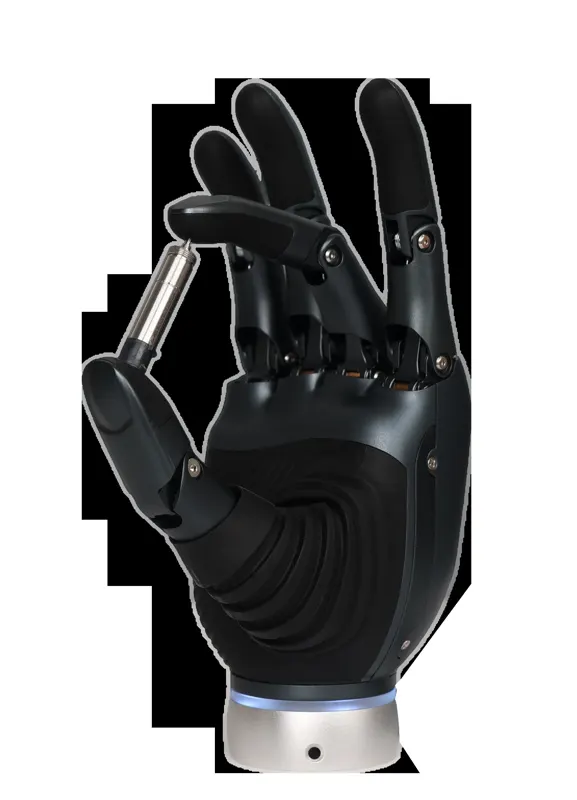
DH116 is a second-generation production five-finger dexterous hand: 11 DoF, 545 g, brushless coreless servo motors with worm-gear transmission and hybrid force-position control. 30 kg whole-hand payload, 5 kg per finger, 100 Mbps EtherCAT (CANFD/RS485), six multimodal tactile sensors, 1M-grasp lifespan.
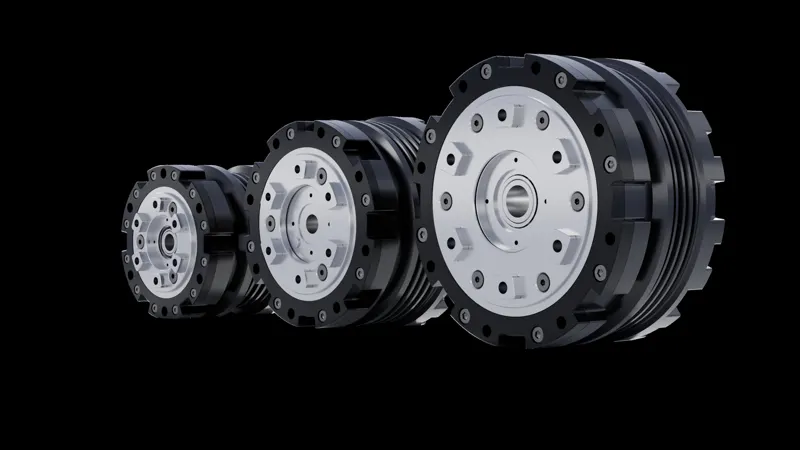
PJ series planetary joint modules for humanoid locomotion joints: optimized reducer for high output and low noise. Example model: ratio 18, 90 N·m start/stop peak torque, 142 rpm rated, 10 arcsec backlash, 17-bit encoder, CAN bus, 105 mm OD with 50 mm through-hole, 0.83 kg.
HJ series harmonic joint modules: harmonic reducer plus fully hardware FOC on chip-level FPGA with 20 kHz triple-loop control. Top model delivers 194 N·m peak torque at ratio 101, 24-bit encoder, EtherCAT/CAN/CANFD, power-off brake and hollow wiring for humanoid joints.
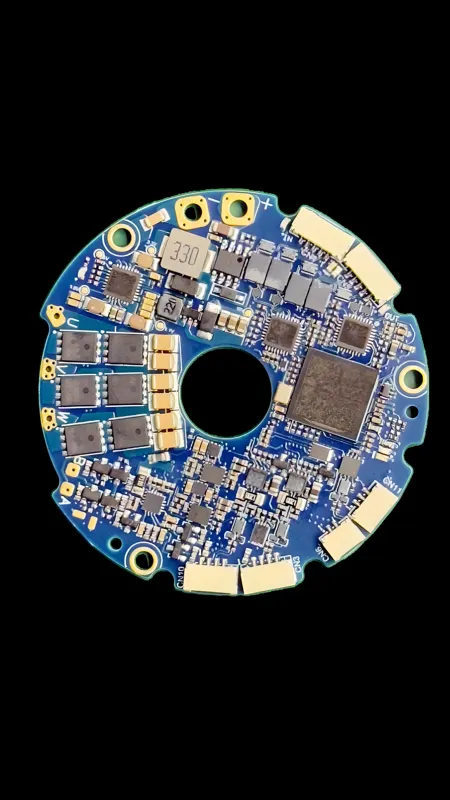
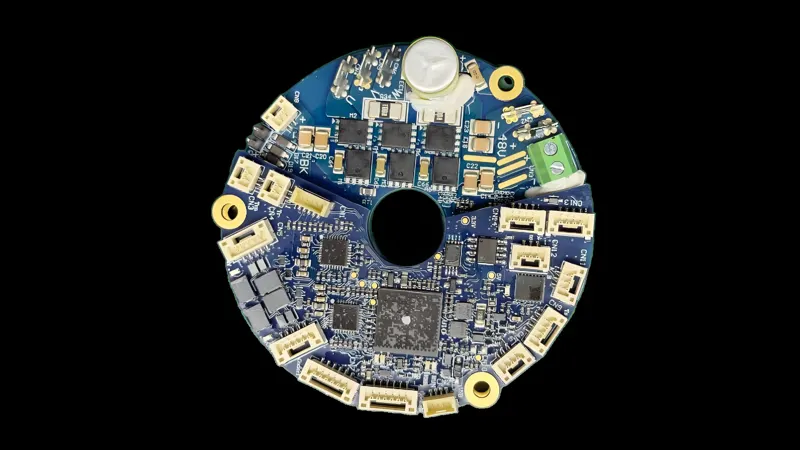
CDH series ring servo drives sized for humanoid robot joints: 48 V, 5/15 Arms rated/peak, OD 58 mm with 15 mm hollow bore, dual EtherCAT plus CAN/RS485/USB, optional 2x19-bit absolute encoders and brake control.
CD series ring-shaped servo drives for collaborative robot joints: 48 V, 10/30 Arms rated/peak, hollow-ring mechanics (OD 65 mm / ID 15 mm), dual EtherCAT (DS402, CoE, FoE, FSoE) plus CAN/RS485/USB, optional 2x19-bit absolute encoders and dual STO.
FM1 series frameless torque motors in four standard frame sizes (50/70/85/115 mm). 48 VDC, up to 6500 rpm; motor dimensions and electrical parameters customizable for robot joint and direct-drive applications.
As an Amazon Associate, we earn from qualifying purchases.