FIBER: Action-Aligned Latent Planning for Humanoid Loco-Manipulation
Loading video
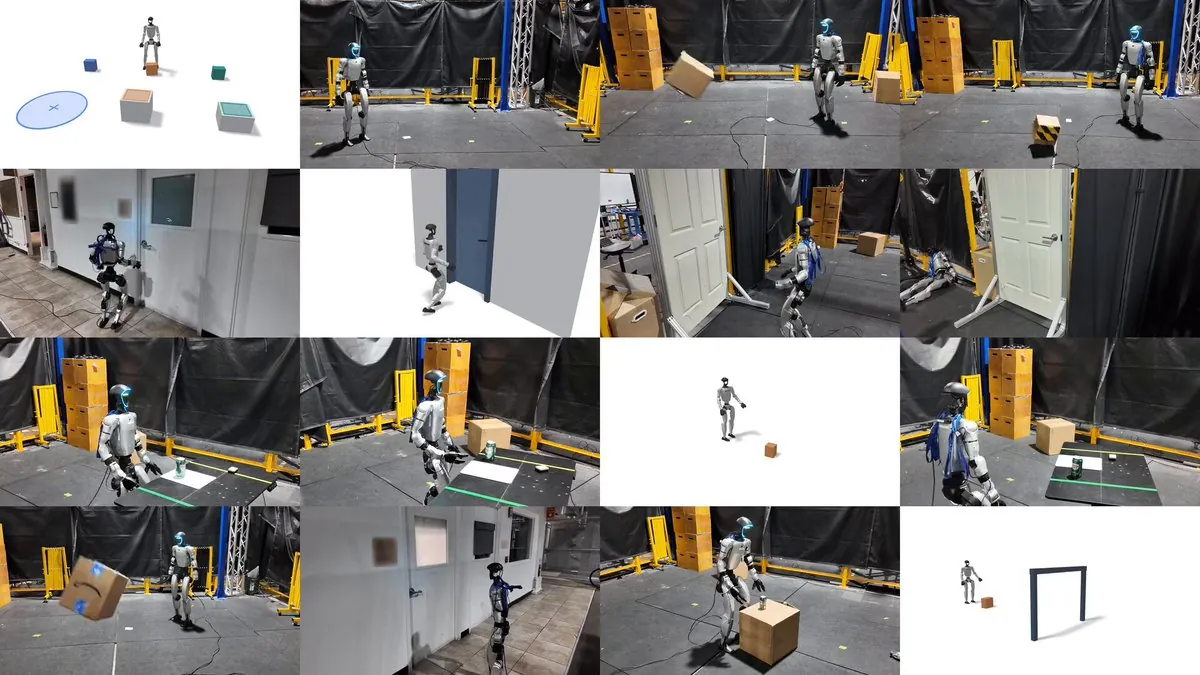
Loading videoFIBER turns a frozen Behavior Foundation Model's executable latent space into the shared planning interface: Latent Policy Projection maps independently trained skill experts into latent commands whose induced actions match their local responses, then a single perceptive flow planner is trained entirely offline on their closed-loop latent rollouts. Across 128 simulated variations per task it reaches 42.0% mean success, against 11.6% for projected latent replay and 3.5% for kinematic planning, and transfers to a real Unitree G1 for box pickup, door opening and object grasping.
HumanoidWhole-Body ControlMobile ManipulationBehavior Foundation ModelReinforcement LearningSim-to-RealUnitree G1Amazon FAR
Category: humanoid
Author: @yutang_llin
Date: 2026-10-20T00:00:00
Duration: 181.033s
Reference: https://arxiv.org/abs/2610.24675