RL Whole-Body Control Self-Trained in 3 Hours Replicates a Laundry Task in Browser MuJoCo
Loading video
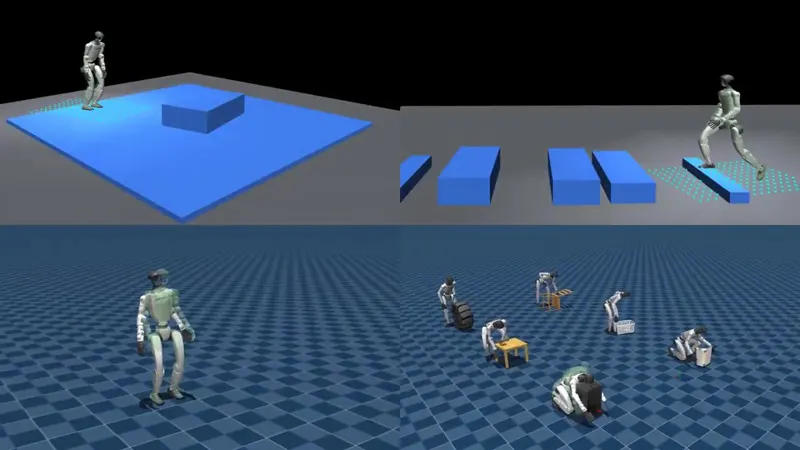
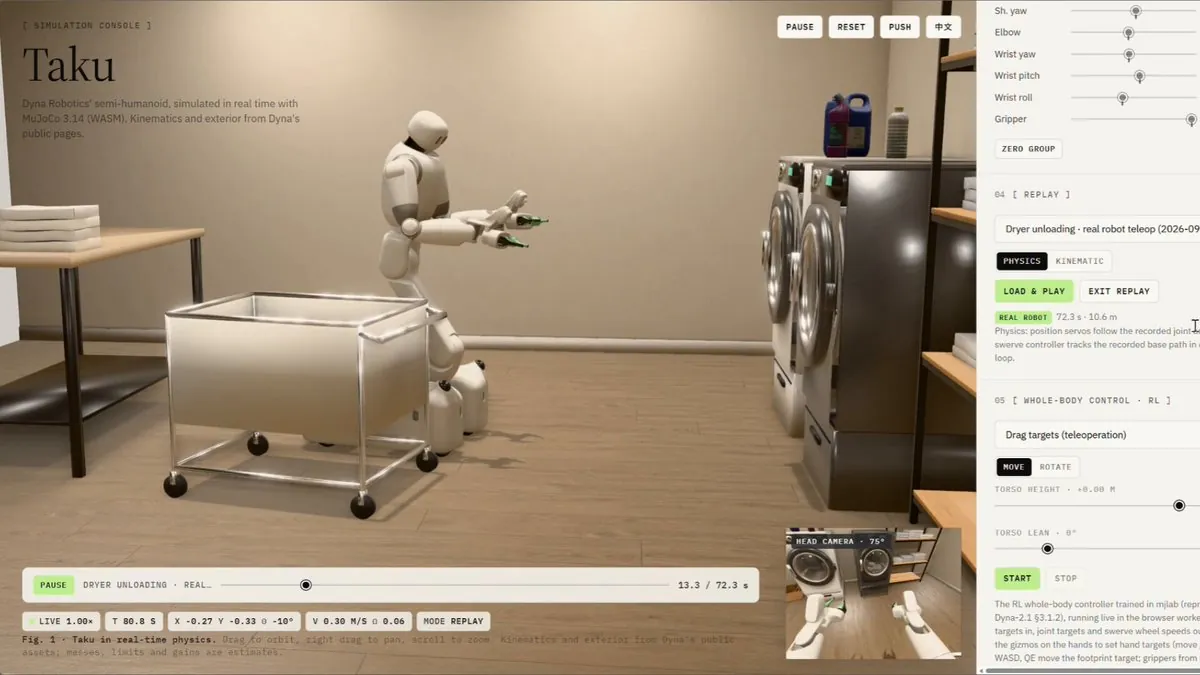
Loading videoA browser build of MuJoCo 3.14 (WASM) simulates Dyna Robotics semi-humanoid Taku in real time and replays a real dryer-unloading teleop episode (72.3 s, 10.6 m). An AI agent replicated the laundry task and self-trained the RL whole-body controller in about three hours: PPO over 4096 parallel envs with overdamped tracking, reaching 13/16 mm hand tracking error.
Category: humanoid
Author: @VectorWang2
Date: 2026-10-13T00:00:00
Duration: 30.0s