LeWAM: An End-to-End JEPA That Controls Real Robots
Loading video
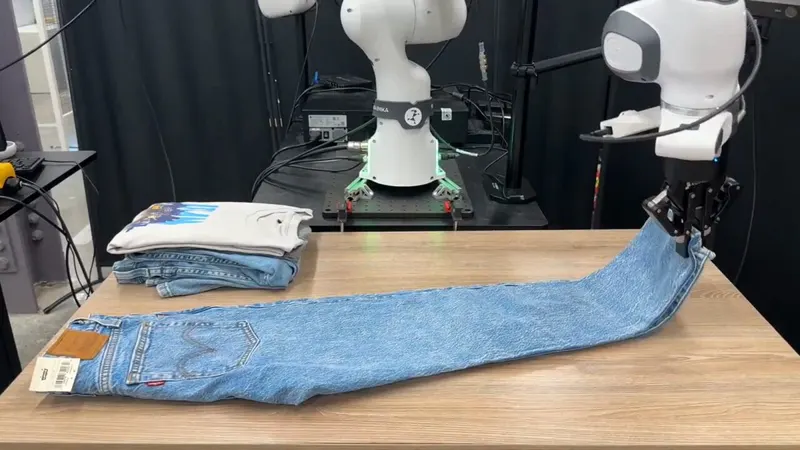
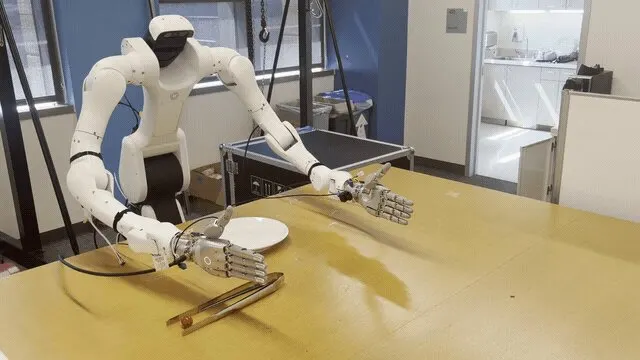
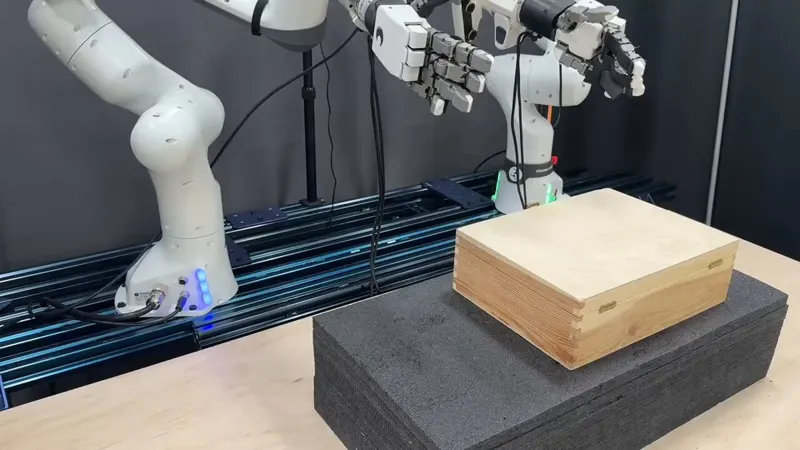
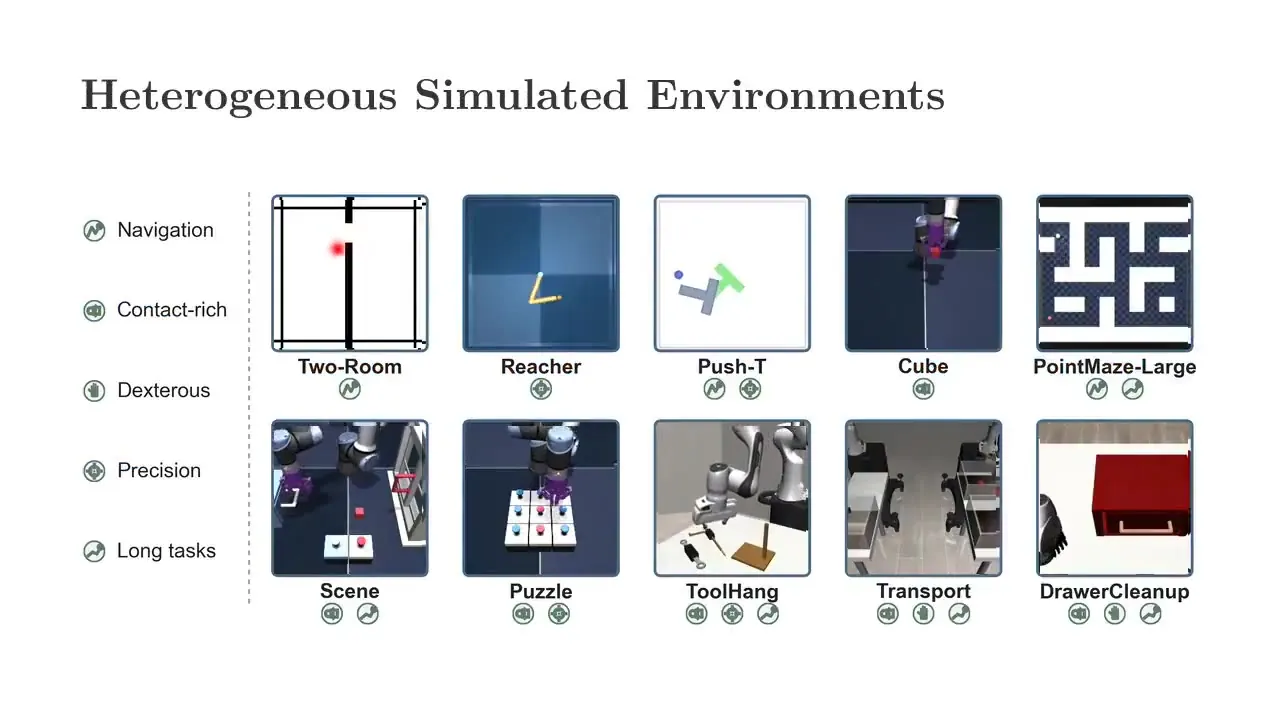
Loading videoLeWAM is an end-to-end JEPA for control: joint next-latent prediction and action flow matching let one 17M-param model act directly and plan visually, lifting contact-rich success from 28.6% to 89.7% on a real robot.
Category: arm
Author: @Minghao__Fu
Date: 2026-10-09T00:00:00
Duration: 57.25s
Reference: https://le-wam.github.io/