Skip to content
Scaling Behavior Foundation Model for Humanoid Robots

Scaling Behavior Foundation Model for Humanoid Robots

Humanoid control requires natural whole-body coordination, precise real-time responses to control signals, and robust generalization across diverse environmental contexts, making it a cornerstone for generalist embodied agents. Behavior Foundation Models (BFMs) have recently emerged as a promising solution to address these challenges by leveraging large-scale behavioral data to achieve superior expressiveness, versatility and generalization. However, despite growing interest in scaling BFMs to further improve their capabilities, it remains unclear how key factors, including the learning paradigm, behavioral data and model architecture should be coordinated to enable effective scaling. In this work, we revisit the scaling recipe for BFMs and demonstrate that substantial performance gains can be achieved through the coordination of three core components: 1) the learning paradigm of motion tracking that reformulates diverse humanoid control problems as the reproduction of integrated whole-body behaviors in the global frame; 2) the strategic synergy between on-policy rollout quantity and reference motion diversity; and 3) the expressive and scalable model architecture termed Humanoid Transformer that facilitates the natural emergence of structured behavioral representations. Through extensive experiments in both simulation and real-world deployment, we demonstrate that our approach yields significant improvements in control fidelity and task generalization, reducing Mean Per-Keypoint Position Error (MPKPE) on the test set by over 10% in local mode and 82% in global mode compared with existing humanoid controllers. These results establish BFM as a principled and effective foundation for scalable and general-purpose humanoid control.

HumanoidBFM
Weishuai Zeng, Kangning Yin, Xiaojie Niu · 494 views · Jul 16, 2026
RAVEN: Reinforcement-Adaptive Visibility-Graph Planning for Robust Humanoid Navigation with Collision-Free MPC

RAVEN: Reinforcement-Adaptive Visibility-Graph Planning for Robust Humanoid Navigation with Collision-Free MPC

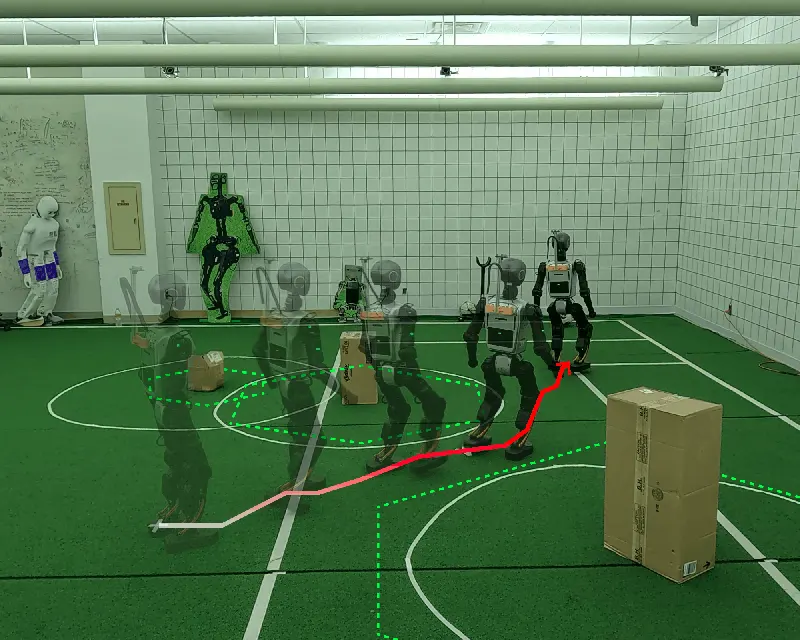
Humanoid navigation in dynamic environments requires long-horizon planning while respecting short-horizon dynamic and safety constraints. Classical visibility-graph planners combined with model predictive control (MPC) can efficiently generate collision-free trajectories, but their performance depends on manually tuned parameters and accurate system modeling. In real robotic systems, control delays, state-estimation noise, and locomotion uncertainties can cause overshoot and constraint violations even when the nominal path is geometrically optimal. We propose RAVEN, a hierarchical reinforcement learning (RL)-MPC framework for robust humanoid navigation. Unlike prior approaches that use learning to tune cost weights or replace planning entirely, RAVEN employs RL to adapt the geometric construction of a visibility-graph planner by modifying obstacle inflation and related graph parameters. By directly reshaping the free-space geometry, the learned planner alters the topology of the global path to compensate for delay and tracking imperfections. A collision-free MPC layer then tracks the planned trajectory while explicitly enforcing velocity bounds and obstacle-avoidance constraints. By training under realistic delays and observation noise, RAVEN learns planning adaptations that improve robustness while retaining explicit long-horizon geometric planning and constrained optimization, in contrast to end-to-end learning approaches. We evaluate RAVEN against a manually tuned visibility-graph MPC baseline and a pure RL navigation policy. Results demonstrate reduced overshoot near obstacles, improved robustness in narrow passages, and more reliable navigation under delay and noise. These findings indicate that reinforcement-adaptive graph construction combined with constrained MPC provides an effective and interpretable alternative to end-to-end learning for robust humanoid navigation.

MPCNavigation
Ruochen Hou, Shiqi Wang, Beom Jun Kim · 461 views · Jul 17, 2026
Handroid: Bridging Dexterous Hand and Humanoid

Handroid: Bridging Dexterous Hand and Humanoid

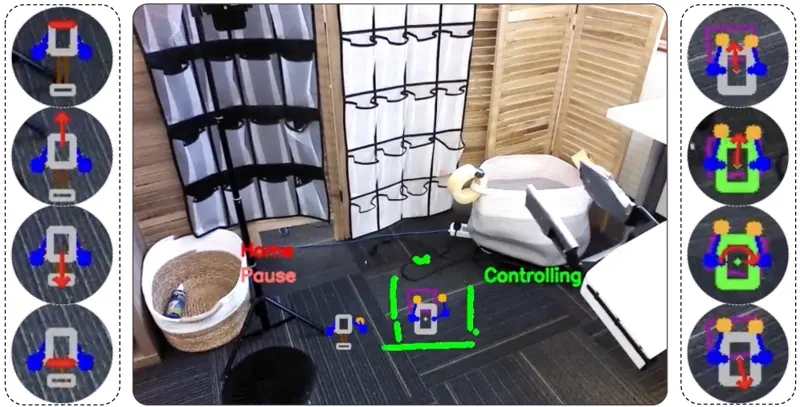
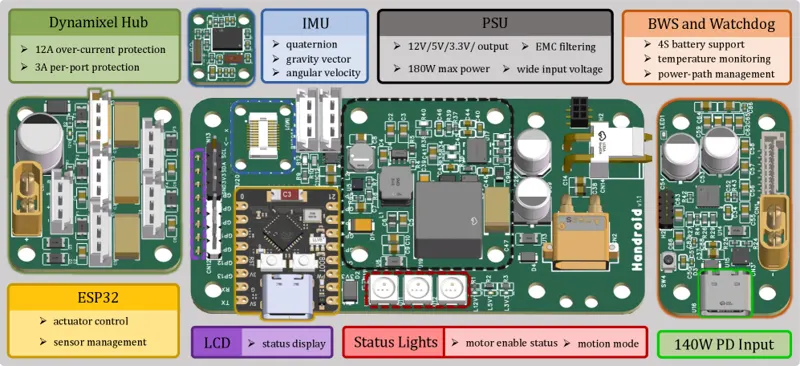
Dexterous hands and humanoid robots are typically developed as distinct embodiments: the former enable contact-rich manipulation at the object scale, whereas the latter provide mobility and whole-body interaction in human-centered environments. We introduce Handroid, a desktop-scale dual-embodiment robot that integrates both capabilities within a single reconfigurable platform. Handroid reuses one 27-DoF electromechanical body as either a dexterous hand or a desktop humanoid, measuring 0.33 m in height and 2.05 kg in weight. In the dexterous hand embodiment, 20 DoFs form an anthropomorphic hand closely matching the kinematic structure of the human hand. In the humanoid embodiment, the same articulated modules are reconfigured into a humanoid with a head, arms, and legs, including a 12-DoF lower-limb structure for locomotion and whole-body motion. Handroid further provides a unified control and learning framework supporting hand teleoperation, dexterous grasping, in-hand manipulation, humanoid locomotion, gait generation, and interactive motion authoring. We validate the platform through real-world dexterous manipulation, reinforcement-learning-based locomotion, keyframe motion deployment, and a long-horizon task involving embodiment reconfiguration, locomotion, docking, and dexterous pick-and-place. These results position Handroid as a compact and reproducible platform for advancing morphology-reconfigurable robotics and cross-embodiment robot learning.

Dexterous HandHumanoid
Ruogu Li, Chenyang Ma, Sikai Li · 421 views · Jul 17, 2026

As an Amazon Associate, we earn from qualifying purchases.