Skip to content
←Back to Papers

PAPER DEEP DIVE

Figure AIHelixHumanoid

Helix: Large-Scale Neural Networks for Whole-Body Humanoid Control

Helix is an end-to-end neural framework for humanoid whole-body perception and manipulation, achieving high generalization through large-scale sim data and real-world fine-tuning.

Helix is an end-to-end neural framework for humanoid whole-body perception and manipulation, achieving high generalization through large-scale sim data and real-world fine-tuning.

Related Papers

Chunk-wise Model-based Policy Optimization

Chunk-wise Model-based Policy Optimization

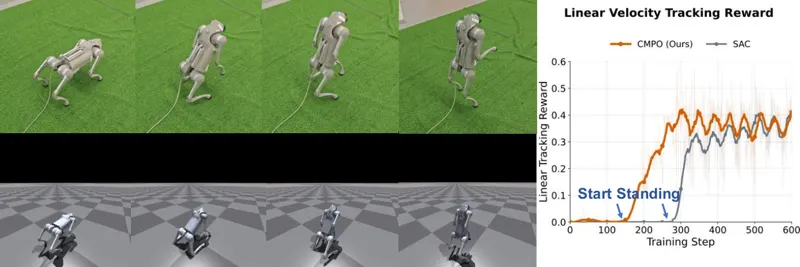
Model-based reinforcement learning has shown superior sample efficiency by leveraging the learned latent dynamics either in the form of derivative-free planning/imagined rollout training or dynamics gradient-based policy updates. While these approaches achieve comparatively fast learning, they all suffer, to varying degrees, from issues of recurrent compounding errors, high inference-time latency, and instability in backward propagation through time (BPTT). In this work, we propose a model-based RL approach that uses the chunk world model as a differentiable training-time evaluator to optimize the chunk actor without recurrent model invocation. Through the collaborative chunk-wise prediction of the world model and policy, we can generate H-step hypothetical rollouts in a single forward pass and directly optimize value expansion, avoiding the costly and unstable BPTT. We evaluate our method on 19 challenging high-dimensional humanoid tasks from HumanoidBench and deploy our method to the real-world for quadruped bipedal walking. Project Website: https://song-wx.github.io/cmpo.github.io/

Weixi Song, Donglin Wang, Yong-Lu Li · 73 views · Oct 10, 2026
HumanoidModel-Based RL
Oct 10, 2026
Movens-Zero: Scaling Humanoid Motion Foundation Models with Large-Scale Human Videos

Movens-Zero: Scaling Humanoid Motion Foundation Models with Large-Scale Human Videos

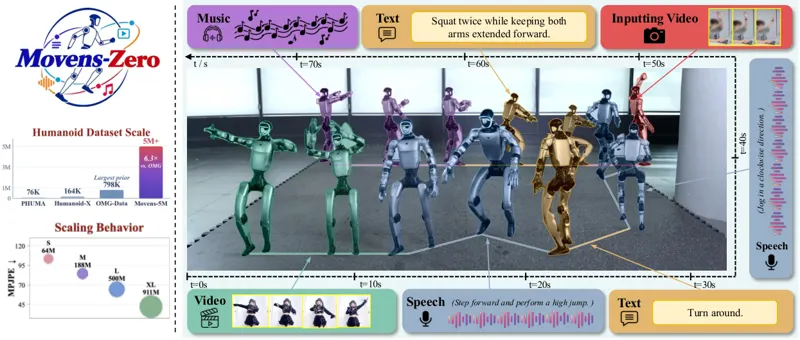
Movens-Zero builds five million executable humanoid motions from Internet human videos, unifies text, video, speech, and music conditioning, and drives Unitree G1 in real time through chunked closed-loop control.

Wendong Bu, Tinghong Ye, Qizhou Wang · 78 views · Oct 30, 2026
HumanoidHumanoid Motion Foundation Model
Oct 30, 2026
METATRON: A Promptable Whole-Body Execution Layer for Humanoids

METATRON: A Promptable Whole-Body Execution Layer for Humanoids

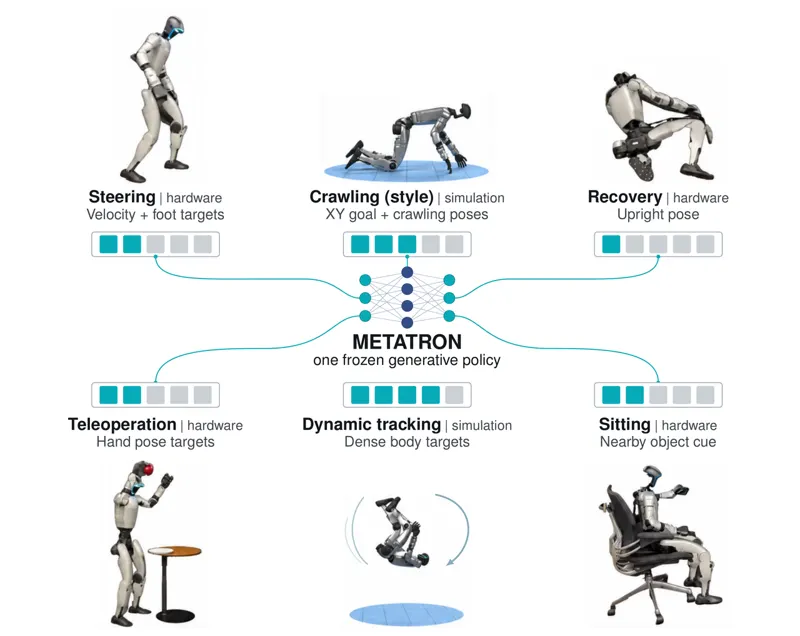
Humanoid controllers often require task-specific training despite sharing the need for balance and whole-body coordination. We present Metatron, a promptable whole-body execution layer combining a generative base policy with a programmable skill layer. The base policy receives partial goals, collectively called a prompt, that can combine timed body-part targets, velocity commands, and style cues. It produces diverse whole-body motions consistent with these goals. Training combines motion capture, synthetic recovery trajectories, and retargeted scene-interaction motions. After training, the policy is frozen. Stateful programs called skills express task intent as prompts at each control step, drawing rough geometric sketches that the policy turns into coordinated movement. Skills are ordinary code, refined by coding agents that analyze motion data and fit compact rules without task-specific policy training. On the physical Unitree G1, one frozen checkpoint supports walking, recovery, teleoperated object pickup, and sitting on furniture. Comparative evaluations show higher reaching success and push robustness than the tested reference-tracking pipelines. The same recipe produces climbing and acrobatics on a simulated character. Metatron enables coding agents to turn learned motor capabilities into new skills through code, without further policy training.

Chen Tessler, Yifeng Jiang, Alec Otto · 334 views · Oct 27, 2026
HumanoidWhole-Body Control
Oct 27, 2026
BeyondMimic: From Motion Tracking to Versatile Humanoid Control via Guided Diffusion

BeyondMimic: From Motion Tracking to Versatile Humanoid Control via Guided Diffusion

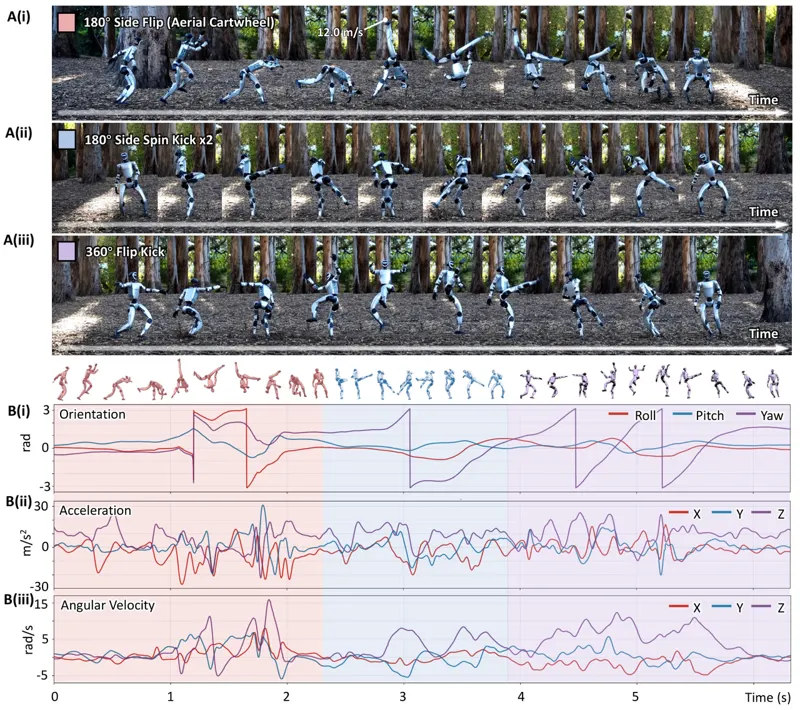
BeyondMimic first masters diverse agile humanoid skills with a compact motion-tracking formulation, then composes and guides them through a unified latent diffusion model for unseen tasks and zero-shot deployment.

Qiayuan Liao, Takara E. Truong, Xiaoyu Huang · 73 views · Aug 11, 2025
HumanoidMotion Tracking
Aug 11, 2025

As an Amazon Associate, we earn from qualifying purchases.