FEATUREDPerceptron Open-Sources Isaac 0.5: First Open Model at the Frontier of Video Understanding, Embodied Reasoning and Robot Control — 210x Less Teleop via Video Scaling
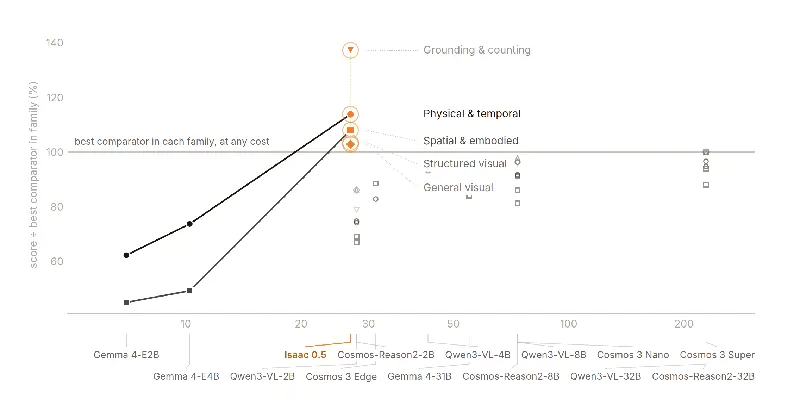
Isaac 0.5 is Perceptron's open-source embodied foundation model with 36B sparse parameters: it reads images, video, language, robot state and previous actions to answer video questions, point and track objects, report task progress, and generate robot actions. The team establishes a scaling law trading video for teleop: scaling general video from 1,000 to 1M hours cuts the teleoperation needed for action loss 2.50 from ~5,900 hours to 28 (210x). Trained on 35+ robot systems, 100K hours of robot experience, 1M hours of video and 3T multimodal tokens, it introduces semantic world modeling (predicting future percepts), the mHarmony typed multimodal interface, and Null Experts for dynamic compute — leading all five perception task families at 8.5x lower inference cost. Weights, training code and LeRobot inference code are fully released.
Embodied Foundation ModelScaling LawVLALeRobotEmbodied Base Model
Perceptron· 2026-08-26T00:00:00