BLOG
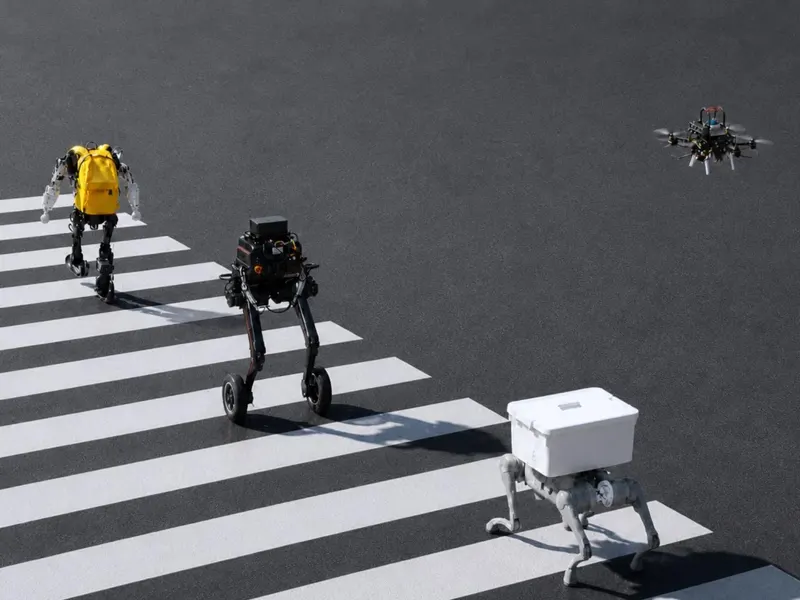
Light Origins' Real2Sim2Real engine turns 2,000+ internet-sourced scenes into 4,000+ hours of aligned VLA experience. LightNav-0 tops 10 simulated settings and transfers zero-shot to humanoid, quadruped, aerial, and wheeled robots.
Meta Reality Labs Research open-sourced Project SuperDex, a unified dexterous-manipulation simulation platform built on a custom contact-first physics engine with soft-body/rod/non-convex contact support, VR teleoperation for synthetic data, and a Gymnasium-style RL stack that achieved zero-shot sim2real shape sorting.
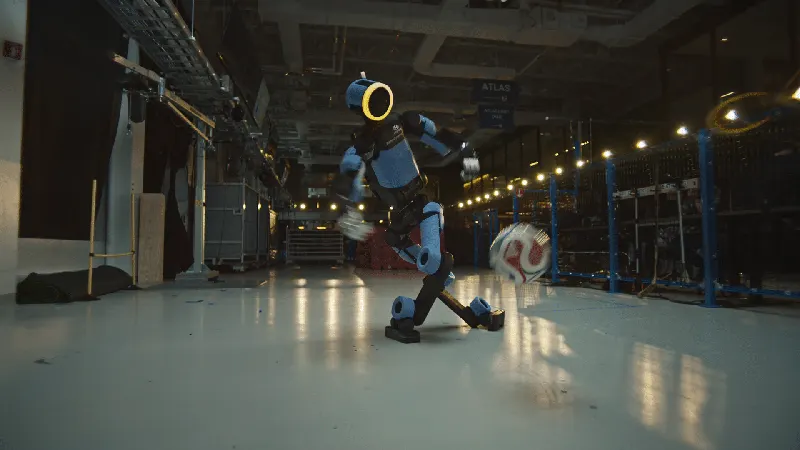
Boston Dynamics teaches Atlas to play football using motion capture + RL for the Ghost Rabona kick. The whole-body coordination required transfers directly to industrial manipulation tasks.
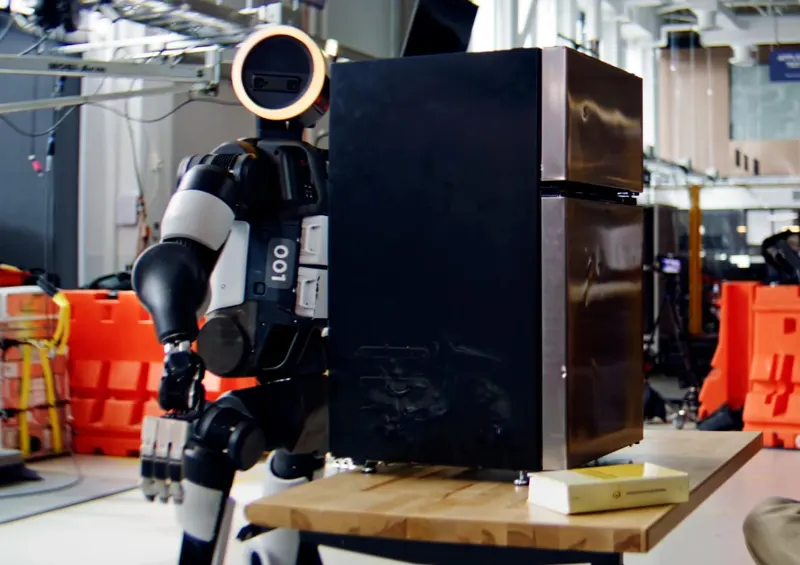
Boston Dynamics shares how Atlas learns whole-body lifting via RL: from reference trajectories and reward design to GPU-scale simulation and real-hardware iteration, demonstrating fundamental building blocks of physical intelligence.
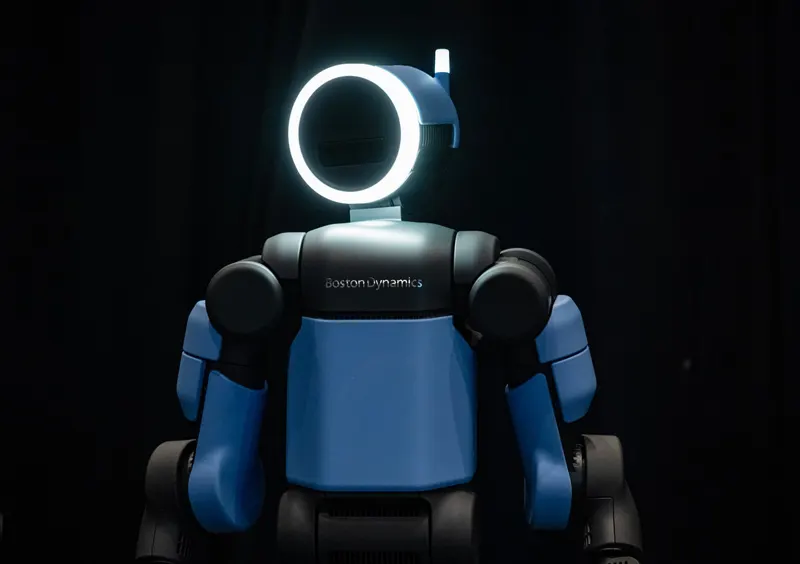
Boston Dynamics traces Atlas' decade-long evolution from hydraulic parkour research platform to electric industrial humanoid. 2026 production-ready Atlas unveiled with Hyundai, already deployed for part sequencing at the Hyundai metaplant.
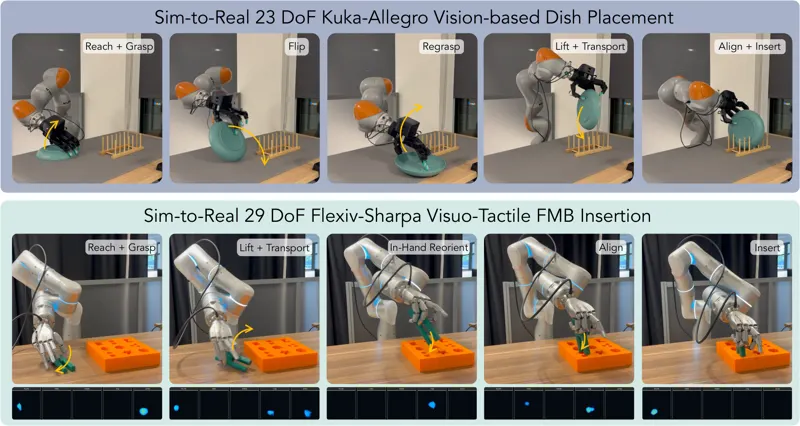
ADEPT pre-trains one dexterous policy on 16 primitives, post-trains specialists without forgetting, and deploys zero-shot on Kuka-Allegro and Flexiv-Sharpa, 2-14x faster than gripper pipelines.