BLOG
2026 Handbook (AIDC Agent ) Agent 。 <1%(1 vs 3 ) 70% 90%+ Scrum Session→Commit→Change→Workitem Guardrail (UNKNOWN PASS) 。
Physical Intelligence (Sergey Levine's team, Mar 19, 2026) present RL Tokens (RLT): freeze a pretrained VLA, attach an encoder-decoder that compresses its internal embeddings into a bottleneck RL token, then run online RL with a ~1M-parameter actor-critic on the real robot, refining only the critical phase (editing VLA action chunks rather than generating from scratch, anchored by a BC regularizer plus reference-action dropout). Across four sub-millimeter tasks the critical phase speeds up by up to 3x, screw success goes 20% to 65%, and half of Ethernet insertion episodes beat every human teleoperation demo - with just 15 minutes of real robot data.
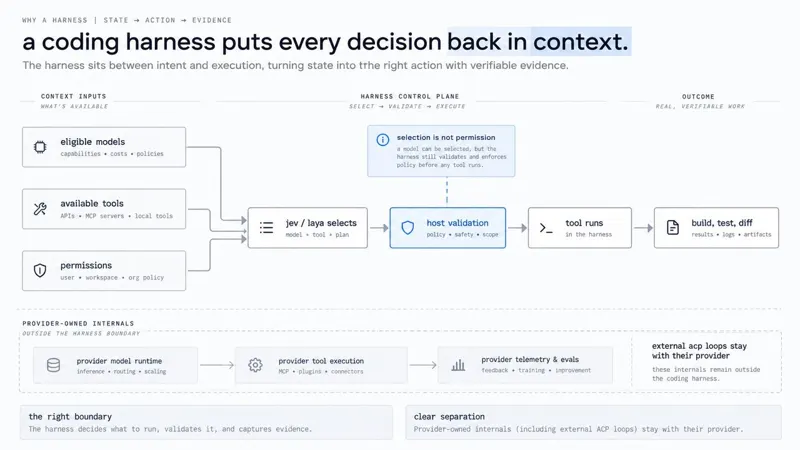
Avid's 3,500-word build log: Jev as a decision layer inside keel, a local-first Rust coding workspace. One principle carries it: a model can suggest the next move, the host still owns the move — the host prepares the menu, Jev picks from it, the host checks again; pinned routes and live sessions bypass automatic selection; selection grants no permission. Plus how decision receipts become replayable evaluation scenarios.
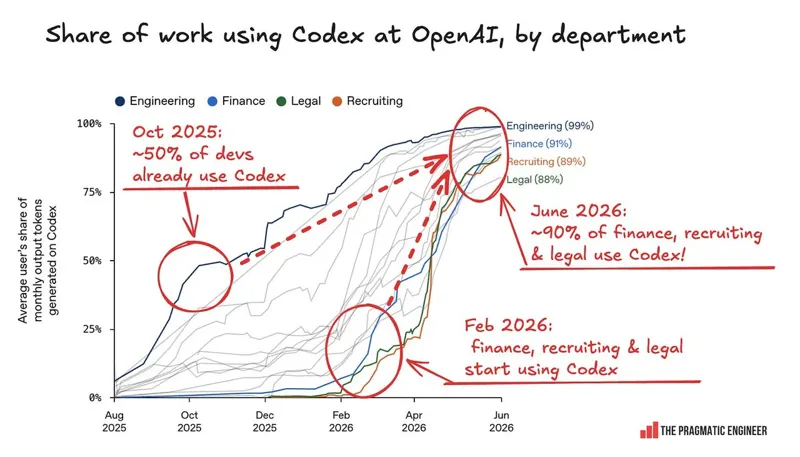
Gergely Orosz visits OpenAI: Codex and ChatGPT Work have taken over everything; a nine-step agentic software factory with Perf Factory and Sevbot, and the rethink of IDEs and pull requests.
Six preparation steps for AI-driven code modernization, from target to pilot run.
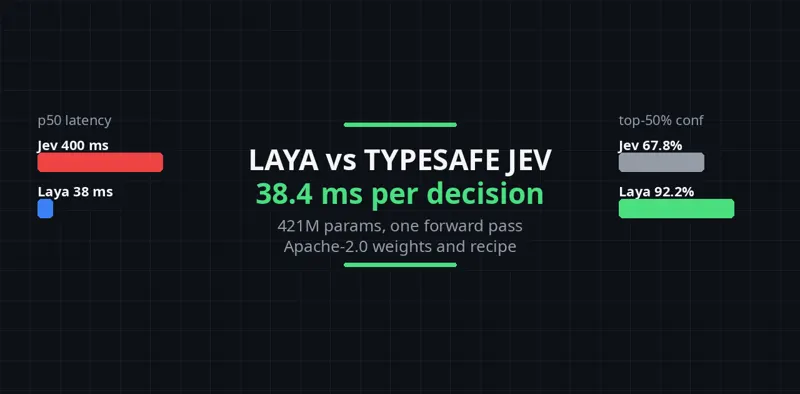
Convai Innovations' open answer to TypeSafe Jev: a 421M non-autoregressive decision model trained with RLCD proper scoring rules, plus the README's honest limits and real Jev comparisons.
Asimov opens up its $20k DIY humanoid kit: 25-DoF hardware, fabrication codes, CAN wiring traps, and the 200 Hz sim / 50 Hz asymmetric actor-critic behind zero-fine-tuning sim-to-real walking.
Code2Skill turns 19,769 GitHub repos into 1,006,822 verified skill records; retrieved skills lift macro-average 11.7% and beat trajectory-derived banks on all seven shared benchmarks.
Xiaomi open-sources MiMo-V2.6 Pro/Flash: 30 live RL steps, ~750k trajectories at $850k/$2.62M; AA Index 46 tops open models, DeepSWE v1.1 gains +17/+14 out of sample; Vibe World, CUA, science and content demos plus 7k+ RL environments released.
Seeed's open-source six-axis arm in full: 96 STEP files, a screw-level BOM recomputed line by line (motors = 89.9%), the published thermal-test limits, the CERN-OHL-W-2.0 licence switch, and the LeRobot + GR00T N1.7 overnight autonomy loop.
Jev-style fixed-answer scoring reproduced locally with SGLang /v1/score: single-token labels, restricted softmax, confidence-gated routing, and a 6 ms vs 1088 ms benchmark against generation.
A deep read of TypeSafe's first System One Model: three question primitives, the economics of parallel calls, confidence-gated routing, eval caveats, eight jagged edges, and the OpenJev local repro.
As an Amazon Associate, we earn from qualifying purchases.