
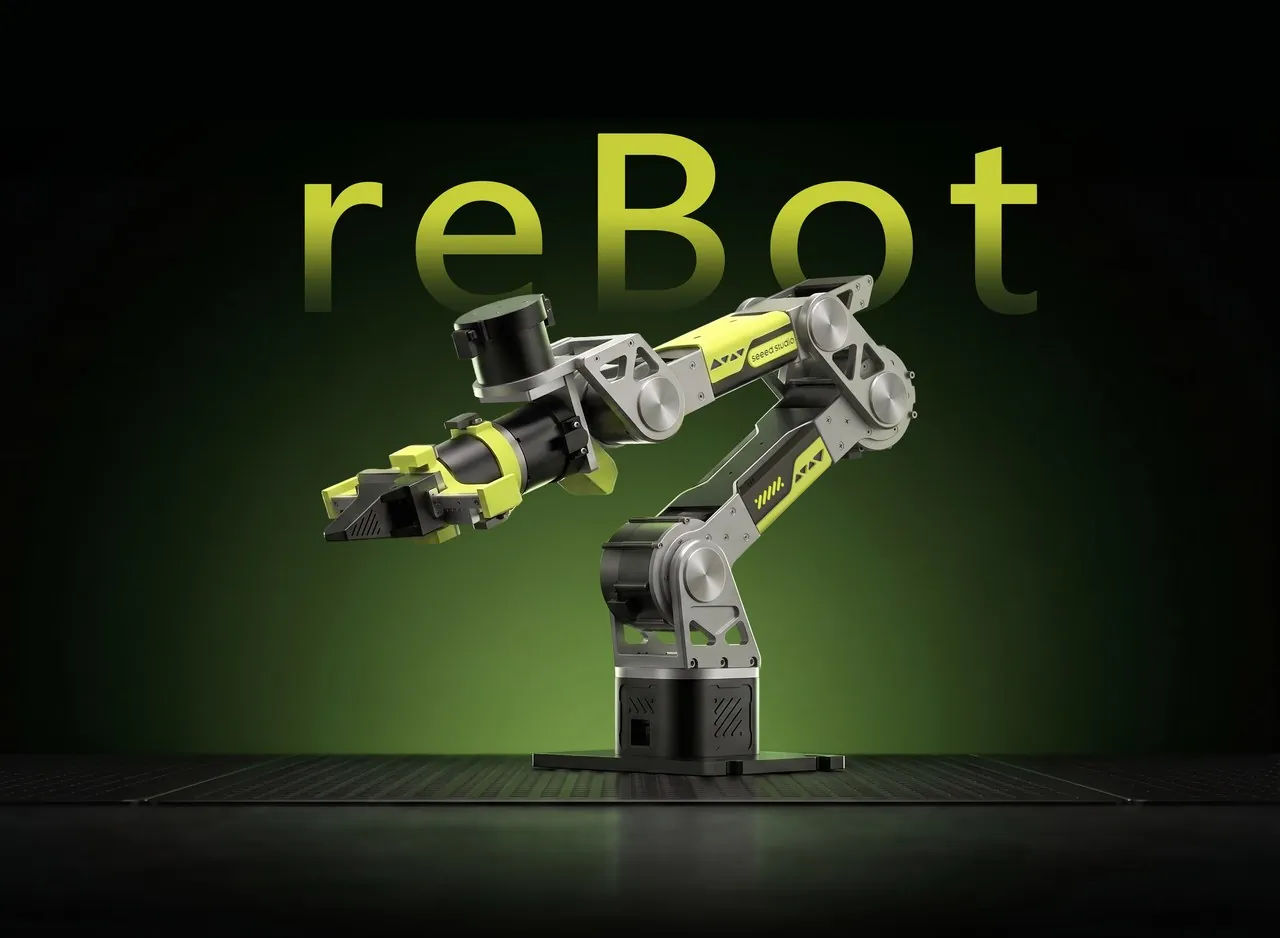
reBot-DevArm Deep Read: 96 STEP Files, a Screw-Level BOM and an Overnight VLA Loop
Seeed's open-source six-axis arm in full: 96 STEP files, a screw-level BOM recomputed line by line (motors = 89.9%), the published thermal-test limits, the CERN-OHL-W-2.0 licence switch, and the LeRobot + GR00T N1.7 overnight autonomy loop.
Introduction: an open-source arm you can actually rebuild, priced to the screw
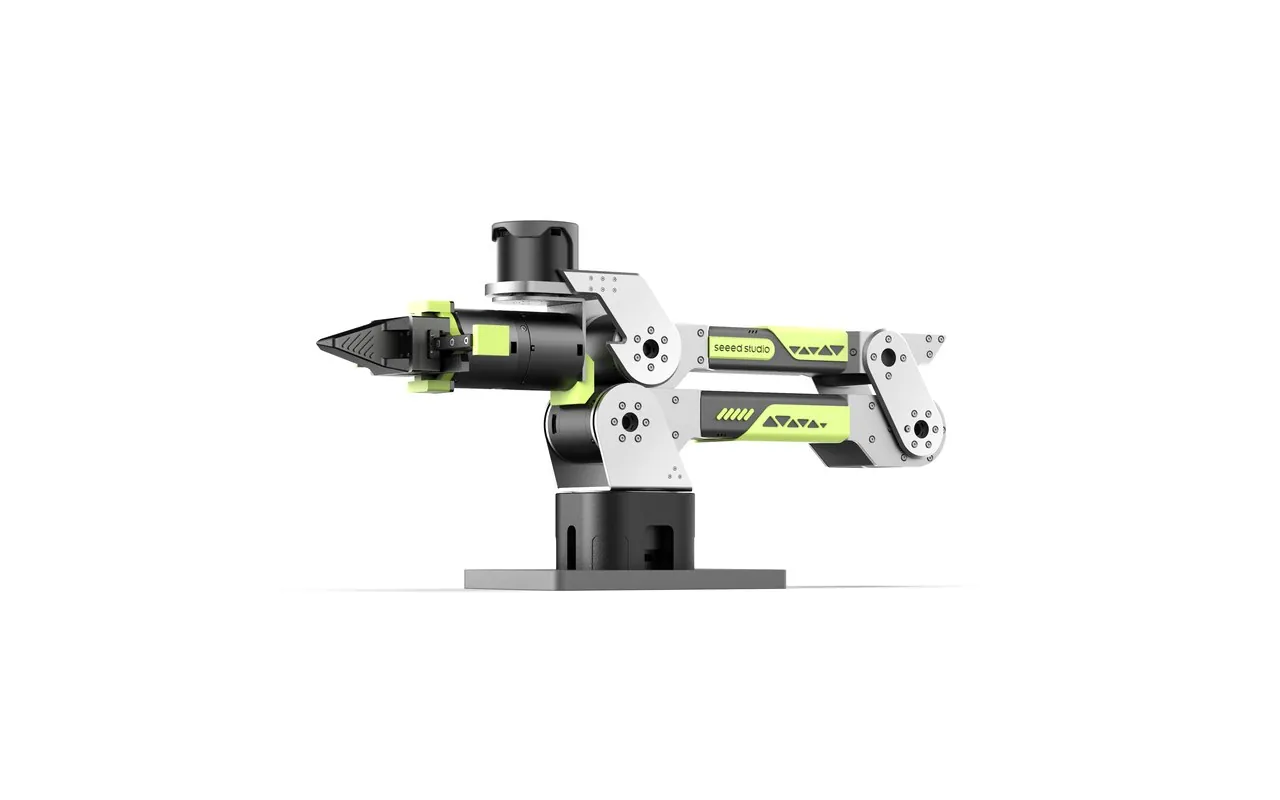
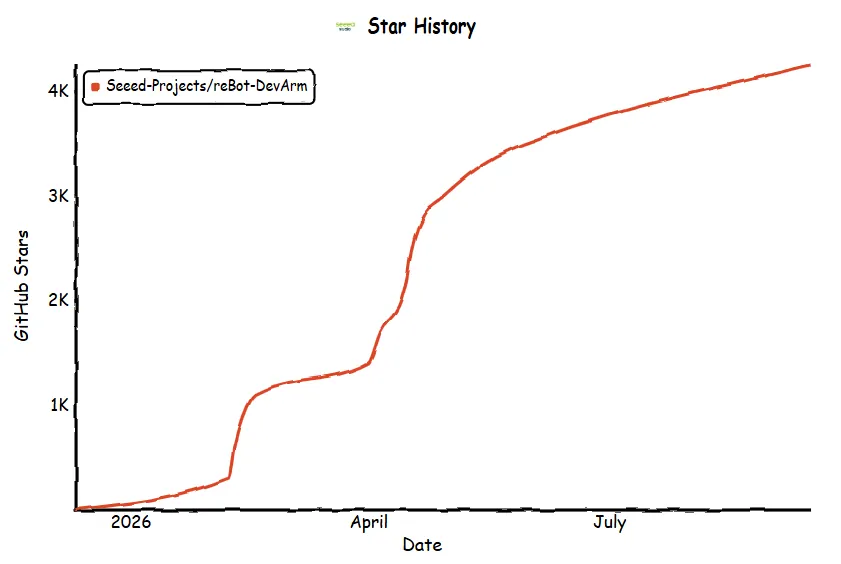
Most projects that call themselves "open source" publish firmware and a demo script, and stop there. The mechanical design lives in someone's CAD tool, the bill of materials lives in someone's spreadsheet, and the reason the arm costs what it costs lives in nobody's head in particular. reBot-DevArm, Seeed Studio's six-axis desktop arm, takes the opposite bet: the repository ships the STEP files, the screw-level BOM with purchase links, the reference manufacturing prices, the real-machine thermal test data and the whole software ecosystem stack, and it keeps updating them as the physical product iterates. As of September 2026 the repository holds 4,276 stars and 428 forks, carries OSHWA certification CN000024, and is dual-licensed CERN-OHL-W-2.0 (hardware) plus Apache-2.0 (software).
media/RS5_56.png).This article is a full read-through of the project: what "open source" concretely contains in this repository, how the two hardware variants differ, what the arm really costs when you add up the BOM line by line, what the official thermal tests say about its honest working envelope, how it became one of the first physical platforms in the NVIDIA + Hugging Face LeRobot VLA pipeline, and what the licence change of May 2026 means if you intend to sell what you build. Every number below is either quoted from the repository's own documents or recomputed from its BOM tables; the source list is at the end.
What "true open source" contains here: 96 STEP files and a screw-level BOM
The claim is easy to check, because a Git tree is a public inventory. The repository's hardware/ directory alone holds 278 files: 96 .step and 10 .stp CAD files covering every printed part, every CNC-machined part and every purchased part, plus 152 reference PNGs and 14 markdown documents. A sibling directory, Rebot_Arm_description/, adds a self-contained URDF/STL package for both variants (92 STL meshes across visual, collision and MuJoCo-collision sets, plus the URDFs themselves), which is what simulation tooling consumes directly. Across the whole repository the count is 419 files: 96 STEP, 10 STP, 92 STL, 171 PNG, 25 markdown documents, 2 URDFs.
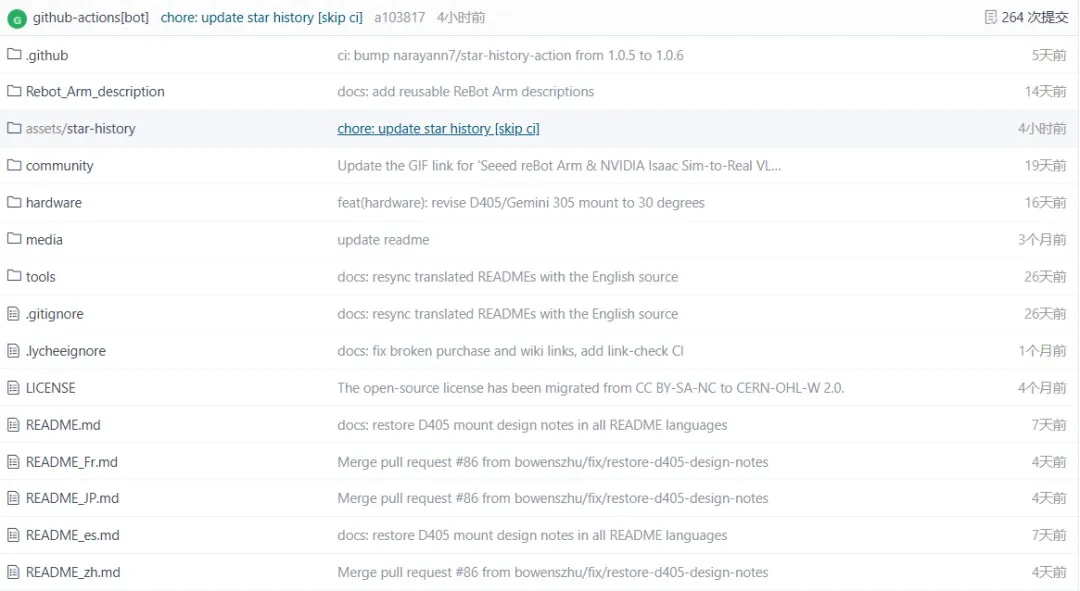
The BOM documents are the part that separates this repository from a marketing drop. The DM hardware readme lists every purchased part with quantity, unit price and a live marketplace link, down to HM3-12mm screws (14+), M4*7mm dowel pins, a ¥10 module-1 16-tooth gear, ¥1.25 6803ZZ bearings and a ¥20 MGN9-170mm linear rail. The printed-part table states a reference average of ¥350 for the whole printed set (Bambu ABS, 0.4 mm nozzle, 0.2 mm layers, 30% infill), and the metal-part table a reference average of ¥1,500 for the aluminium-5052 CNC set, both explicitly flagged as floating with material cost and factory lead time. That is a BOM you can price, not a BOM you can admire.
Just as important, the files track the physical engineering. The DM changelog records v1.0 on 2026-03-31 and v1.1 on 2026-04-25, and the v1.1 entry is pure assembly feedback: cable restraints (Cable Restraint) added to the last three joint motors so harnesses cannot chafe or pull out, the joint-1 motor corrected from DM4310 to DM4340P after the original sizing proved wrong, a new CNC base reinforcement part (02_Base_Reinforcement_Part.step, aluminium 5052, with a note that ABS printing at higher infill is an acceptable cost-down substitute), and extra harness clips. Public files that change because a real arm broke are the difference between documentation and a design record.
| Version | Date | STEP release | What changed and why |
|---|---|---|---|
| v1.0 | 2026-03-31 | reBot_B601_DM_v1.0_20260331.step | First public upload of the full assembly |
| v1.1 | 2026-04-25 | reBot_B601_DM_v1.1_20260425.step | Cable restraints on joints 5-7 (anti-chafe, anti-pull-out); joint 1 motor corrected 4310 → 4340P; CNC base reinforcement 02_Base_Reinforcement_Part.step; added harness clips |
One caveat the project states plainly: the published BOM is not the shipped configuration. Seeed's production version adds laser-engraved anti-fooling marks on metal parts, replaces some printed parts with metal for durability, retunes clearances and machining tolerances for factory variation, and adds custom braided-sleeve wiring at extra cost, while keeping the mechanical structure identical. If you rebuild from the repository you are building the honest open version, which is deliberately a few optimisations behind the retail unit.
Two variants, one architecture: B601-DM and B601-RS
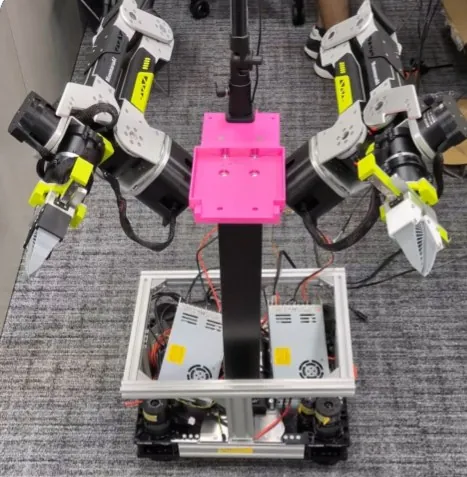
The project ships two parallel hardware lines that share geometry and differ in actuators and electrical class. B601-DM runs Damiao 43-series motors on a 24 V bus; B601-RS runs RobStride actuators on 48 V and trades weight for payload. Both are 6+1 DoF: six revolute joints plus a seventh motor for the gripper.
| Parameter | B601-DM (Damiao) | B601-RS (RobStride) |
|---|---|---|
| Degrees of freedom | 6 + 1 (gripper) | 6 + 1 (gripper) |
| Max reach | 767 mm | 754 mm |
| Recommended payload | 1.5 kg | 2.5 kg |
| Repeat positioning accuracy (declared) | < 0.2 mm | < 0.2 mm |
| Supply | DC 24 V | DC 48 V |
| Arm mass | ≈ 4.5 kg | ≈ 6.7 kg |
| Actuator set | 4 × DM4310 (V4) + 3 × DM4340P (V4) | 4 × RobStride RS00 + 3 × RS06 |
| Brakes | None on either variant: do not use it to carry loads that must not drop | |
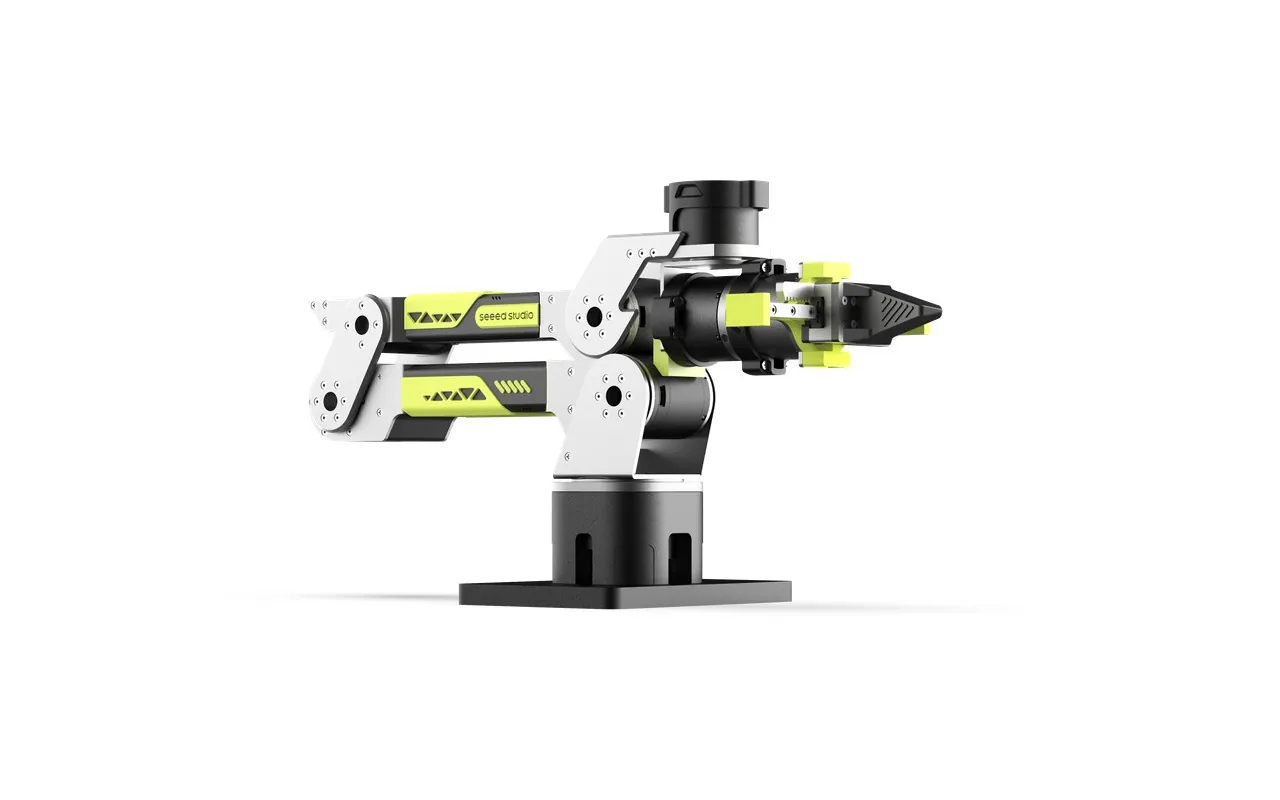
Two declared numbers deserve scepticism, and the community supplies it. The < 0.2 mm repeatability figure is a vendor-style claim with no published measurement protocol in the repository; builders treat it as aspirational and measure their own units. And the absence of brakes is a real architectural constraint, not an omission to forgive: with no holding brakes, a powered-down or faulted arm will sag under load, so the platform is wrong for any task where dropping the payload is unacceptable. Read together, these two caveats define the machine's honest identity: a research and education arm with excellent documentation, not a production manipulator.
BOM forensics: the motors are 90% of the money
Adding up every priced line in the DM BOM (motors, CAN-USB board ¥60, CAN power-separation board ¥9, 6707ZZ bearing ¥14.80, three 6803ZZ at ¥1.25 each, AXK5578 thrust bearing ¥17, MGN9 rail ¥20 plus two sliders at ¥20, gear ¥10, silicone pad ¥4.60, the XT30 harness set, two 6-inch G-clamps at ¥23.80, the LRS-350-24 supply at ¥118.75, AC cord, XT60E output hardware, IEC inlet and the priced screw lines) gives ¥5,664.76 of priced purchased parts. Of that, the seven motors alone are 4 × ¥599 + 3 × ¥899 = ¥5,093, or 89.9% of the priced total. Everything else on the arm, bearings to power supply, is ¥572.
Then add manufacturing. The printed set references ¥350 and the CNC set ¥1,500, so a from-scratch replication lands near ¥7,515 (about US$1,044 at 7.2 CNY/USD) before labour, tools and shipping. The community figure of "around ¥6,000 to self-source" matches the priced-items-only calibre almost exactly (¥5,665 rounds to "six thousand"), which is a useful sanity check on both numbers: the gap between ¥6,000 and ¥7,500 is precisely the manufacturing layer that casual quotes drop.
The RS BOM tells the same story in dollars and with a flatter curve: 4 × $125 RS00 plus 3 × $210 RS06 is $1,130 of motors inside a priced total of $1,466.98, i.e. 77.0%. The RS line prices its non-motor parts higher in dollar terms (CAN-USB $15, gear $44, rail $23, LRS-600-48 supply $69.50), which is why the motor share drops even though the motors themselves cost more in absolute terms.
({"_height": "380px",
 "backgroundColor": "transparent",
 "grid": {"left": 70, "right": 40, "top": 60, "bottom": 60},
 "legend": {"top": 8, "textStyle": {"color": "#94a3b8"}},
 "tooltip": {"trigger": "axis", "axisPointer": {"type": "shadow"}},
 "xAxis": {"type": "category", "data": ["B601-DM (CNY)", "B601-RS (USD)"], "axisLabel": {"color": "#e2e8f0"}},
 "yAxis": {"type": "value", "name": "cost", "axisLabel": {"color": "#94a3b8"}, "splitLine": {"lineStyle": {"color": "rgba(148,163,184,0.15)"}}},
 "series": [{"name": "Motors (7 actuators)", "type": "bar", "stack": "c", "data": [5093, 1130], "itemStyle": {"color": "#3ddc97"}},
 {"name": "Other priced parts", "type": "bar", "stack": "c", "data": [572, 337], "itemStyle": {"color": "#38bdf8"}},
 {"name": "Printed + CNC reference", "type": "bar", "stack": "c", "data": [1850, 0], "itemStyle": {"color": "#f59e0b"}}]})
The engineering reading of Figure 4 is the point of this section. On a desktop arm built from quasi-direct-drive actuators, the actuator choice is the product: it sets cost, bus voltage, mass, thermal behaviour and control stack in one decision. That is why the v1.1 changelog's single most consequential line is a motor substitution (joint 1 from 4310 to 4340P), and why the performance section below is really a story about motor thermals rather than about structure. It is also why the two variants exist at all: DM buys a cheaper, lighter, 24 V machine for education and algorithm work; RS buys payload headroom at 48 V and 2.2 kg extra mass.
The honest working envelope: structure passes, motors set the ceiling
The repository publishes its own abuse testing in Performance_Testing.md, based on the DM variant with Damiao V4 motors. The protocol is simple and credible: 5-second reciprocating motions across 5-70% or 5-100% of rated reach for dynamic tests, static holds at 70% and 100% reach for static tests, run until something stops the test.
| Dynamic test (5 s reciprocating) | Load | Duration | Termination |
|---|---|---|---|
| 5%-70% reach | 1.5 kg | > 2 h | Motor #2 reached 90 °C, stopped manually |
| 5%-70% reach | 2.5 kg | 40 min | Overheat protection triggered |
| 5%-100% reach | 1.5 kg | 45 min | Overheat protection triggered |
| Static hold | Load | Max duration | Termination |
|---|---|---|---|
| 70% reach | 1.5 kg | 18 min | Overheat protection |
| 100% reach | 1.5 kg | 3 min | Overheat protection |
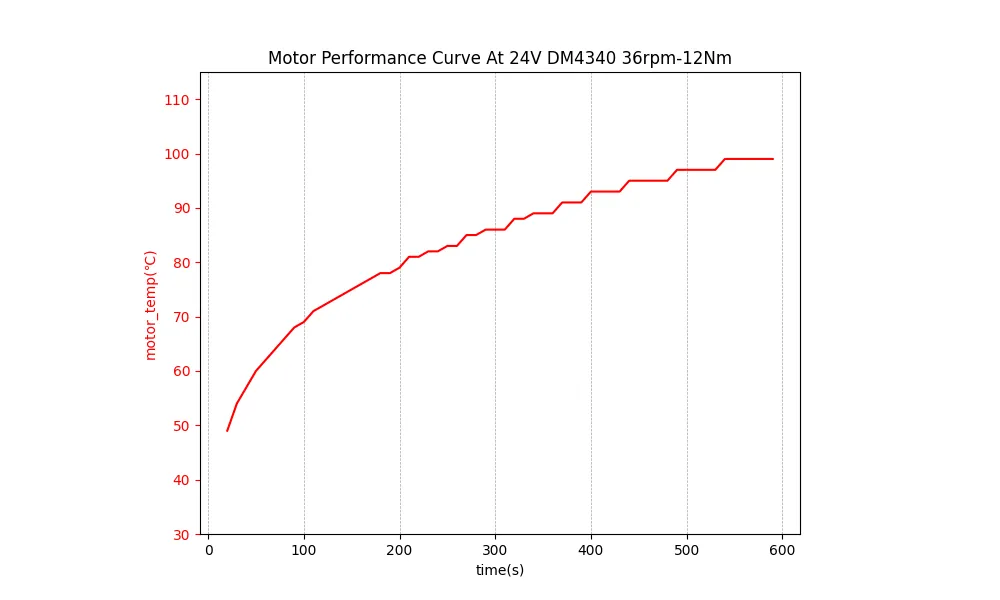
Three conclusions follow, and the project draws them itself. First, the mechanical structure is not the limit: every test ended in motor thermal protection, never in deflection, backlash or breakage. Second, reach and speed are thermal variables, not just kinematic ones: holding the load constant at 1.5 kg and moving the posture from 70% to 100% reach cuts static endurance from 18 minutes to 3, and pushing speed to full range cuts the 1.5 kg dynamic run from over two hours to 45 minutes. Third, the official recommendation is therefore a duty-cycle contract rather than a spec sheet: load < 1.5 kg, working radius < 70% of reach (about 450 mm), speed < 70% of maximum, ambient 15-35 °C, active cooling for long high-load sessions, and a 10-15 minute rest after every two hours of continuous operation. The published 12 Nm load curve for the Damiao 43 series (motor temperature rising from about 50 °C to a plateau near 98 °C over ten minutes) is the physical reason behind all of it.
From Quest 3 to autonomy overnight: the VLA pipeline
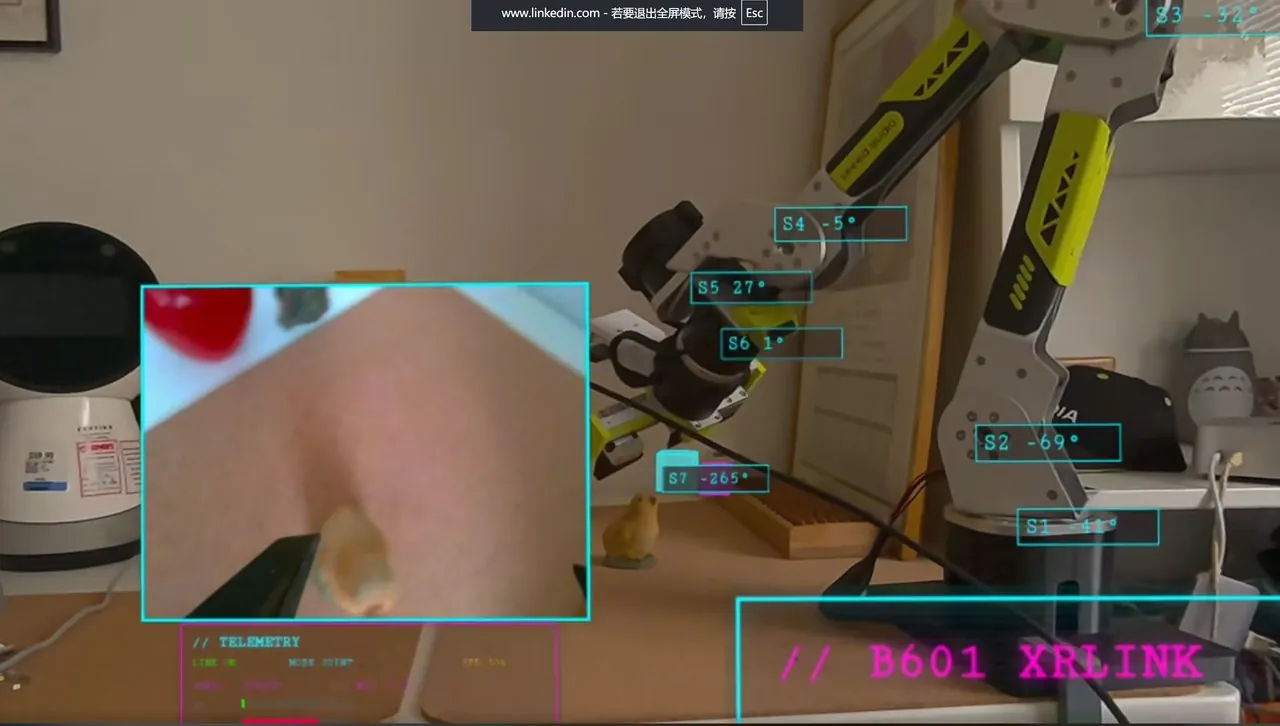
The most consequential thing about reBot-DevArm in 2026 is not mechanical. In July 2026 NVIDIA integrated Isaac Teleop (teleoperation data collection) and GR00T N1.7 (a 3-billion-parameter open VLA foundation model under Apache-2.0) natively into Hugging Face's LeRobot, and the 7-DoF reBot DevArm adapted to every layer of that stack, becoming one of the first physical hardware platforms of the new paradigm. LeRobot's official documentation registers reBot B601 single-arm and dual-arm configurations.
flowchart LR
 A["Quest 3 headset
operator in VR"] --> B["Isaac Teleop
teleoperation + data capture"]
 B --> C["~40 demonstrations
standard LeRobot dataset"]
 C --> D["GR00T N1.7 fine-tune
3B params, Apache-2.0
overnight job"]
 D --> E["Deploy to reBot B601
autonomous next morning"]
 E -.->|new failures, new demos| C
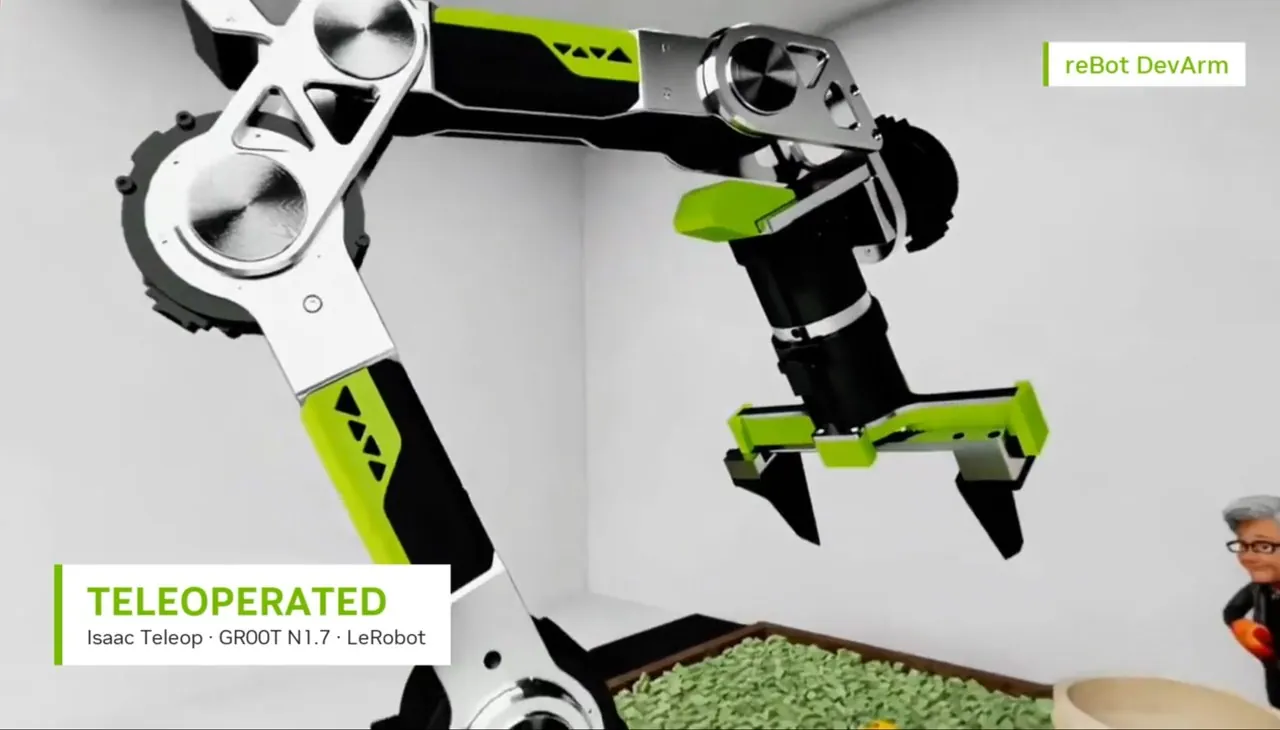
Rebot_Arm_description/ is what simulation trains against, which is why sim-to-real transfer on this arm is a documentation problem rather than a modelling problem.Beyond the VLA headline, the ecosystem table in the README is unusually complete for a sub-$1,500 arm: ROS 1 and ROS 2 integration with MoveIt on the RS line, a ROS 2 controller with kinematics, trajectory planning and gravity compensation on DM, Pinocchio adaptation for forward/inverse kinematics, Isaac Sim USD import with simulated teleoperation in progress, the Motorbridge Python SDK covering Damiao, RobStride and other motor protocols with a web UI, a browser MuJoCo demo, the YOLO/depth grasping demo, and a reSpeaker Flex four-mic-array voice-control build. Seeed also published a Sim-to-Real VLA course with NVIDIA for WRC 2026 covering real demonstration capture, Isaac Sim data augmentation, GR00T 1.7 post-training and Jetson deployment, plus a wiki tutorial for fine-tuning GR00T N1.7 on the B601-DM and deploying to Jetson Thor.
The licence story: non-commercial for five months, then fully commercial
For its first five months the project ran on CC BY-SA-NC, a non-commercial licence that kept companies out by design. Effective 2026-05-11 it migrated to a dual licence: CERN-OHL-W-2.0 for hardware designs and Apache-2.0 for firmware and software, which the README describes as reaching "100% full-stack open source with full commercial compliance and usage rights for all scenarios". The migration commit is visible in the repository history, and the OSHWA certification CN000024 followed under the new terms.
| Right / obligation | Hardware: CERN-OHL-W-2.0 | Software: Apache-2.0 |
|---|---|---|
| Commercial use, modification, redistribution | Allowed | Allowed |
| Closed-source integration | Conditional (weakly reciprocal) | Allowed, no disclosure of modified code |
| Copyright + licence text retention | Required | Required |
| Modification notice | Required, with date and description | Required, with description |
| Patent grant | Explicit | Explicit |
| Source provision on distribution | Must provide hardware "Complete Source" | No mandatory source provision |
| Closed external modules | Allowed: independent-interface "External Material" keeps its own licence | Allowed, link with anything |
The practical reading for a company: you may sell arms built from these files, and you may keep unrelated modules (a proprietary gripper, a closed vision stack) closed under the External Material clause, but the moment you distribute modified hardware you must publish the complete source of that hardware design. Apache-2.0 on the software side imposes no equivalent duty. Verify clause by clause before shipping; the matrix above is a summary of the README's own table, not legal advice.
Kits, community pricing, and what the kit does not include
Seeed sells five DM tiers, from motors-only to a finished machine, plus RS full and pre-assembled kits with an early-bird price of $1,499 for the assembled RS unit. Community discussion puts an unassembled full kit near $1,200, which sits sensibly above the $1,044 from-scratch figure computed earlier: the delta is assembly, testing, warranty and margin.
| DM kit tier | Contents |
|---|---|
| Arm Body Motor Kit | Motors and harness only |
| Arm Body Structural Kit | Mechanical structure parts only |
| Gripper Complete Kit | Complete gripper assembly |
| Full Kit | Arm body plus complete gripper |
| Pre-assembled Robotic Arm | Fully assembled and tested unit |
Two purchasing footnotes matter more than they look. Kits exclude the power supply and the C-clamps used during assembly, and Seeed's own bundled PSU listing has been delisted at times, with the wiki pointing builders to search the store for a 24V 4.5A XT30 substitute; the DM BOM's own reference is a Mean Well LRS-350-24 at ¥118.75. And the ¥350/¥1,500 manufacturing averages are partial manufacturing costs: motors, harness, supply, bearings and your labour all sit outside them, which is exactly the gap Figure 4 makes visible.
Before you build: four traps the community already fell into
1. The open files are not the shipped article. Builders recommend waiting until official software and peripherals mature before a full replication, and Seeed states the divergence explicitly (laser engraving, metal substitutions, tolerance retunes, custom braided harness). Budget for documentation lag.
2. Check the licence per component. Hardware and software carry different licences with different distribution duties, and the project was non-commercial until May 2026; older forks and mirrors may still say CC BY-SA-NC. Confirm against the current LICENSE file, not a blog post.
3. Do not run the control stack in a virtual machine. Seeed's wiki states that validated VM performance is insufficient for the demos and carries configuration problems; use an Ubuntu physical machine. This is a real-time bus (CAN) driving seven actuators; virtualised USB latency is exactly the failure mode that produces scary arm behaviour.
4. Respect the screw discipline. The kit contains 300+ visually similar screws and structural parts; the official guidance is an electric screwdriver set to 3-6 kgf·cm to avoid stripping threads and scrapping printed parts. Builders who hand-tightened "by feel" report exactly the scrapped parts the torque figure exists to prevent.
Resource index
| Resource | URL | What it is |
|---|---|---|
| GitHub main repository | github.com/Seeed-Projects/reBot-DevArm | Code, CAD, BOM, docs, community gallery |
| Gitee mirror | gitee.com/seeed-projects/reBot-DevArm | Faster clone for mainland-China developers |
| Seeed Wiki robotics hub (zh) | wiki.seeedstudio.com/cn/robotics_page/ | Aggregate of all Chinese tutorials |
| DM hardware readme (STEP + BOM) | hardware/reBot_B601_DM/readme_zh.md | Screw-level BOM with prices and links |
| RS hardware readme | hardware/reBot_B601_RS/README.md | RobStride variant BOM and parts |
| LeRobot tutorial (zh / en) | zh / en | Data collection, training, deployment in LeRobot |
| GR00T N1.7 fine-tune + Jetson Thor | wiki tutorial | Fine-tune on B601-DM, deploy on Thor |
| NVIDIA Isaac Sim integration blog | seeedstudio.com blog, 2026-07-08 | Isaac Teleop + GR00T N1.7 + LeRobot stack, with the advocate's validation log |
| Sim-to-Real VLA course (WRC 2026) | seeedstudio.com blog, 2026-08-19 | Demo capture, Isaac Sim augmentation, GR00T post-training, Jetson deploy |
| Visual grasping demo | reBot-DevArm-Grasp | YOLO/OBB + RGB-D grasping example |
| Assembly video (58 min, zh) | Bilibili mirror BV1zPdzBEE1R | Full build from parts to working arm |
| Motor ID write + zero calibration | Bilibili mirror BV1H2drBtENA | Mandatory first-run calibration steps |
Assessment
reBot-DevArm's value is the combination of two things that rarely coexist: depth of hardware disclosure (STEP + STL + URDF + screw-level priced BOM + thermal test data, all versioned with the physical product) and breadth of ecosystem integration (LeRobot, GR00T N1.7, Isaac Sim/Teleop, ROS 1/2, MoveIt, Pinocchio, Motorbridge, MuJoCo, perception and voice demos). Neither half is impressive alone; plenty of arms have SDKs, and plenty of repositories have CAD. The conjunction is what makes it a credible verification platform for embodied-AI algorithms on a desk-sized budget, and the published thermal data is what makes that credibility honest: you know before buying that this is a 1.5 kg, sub-70%-reach, duty-cycled research arm with no brakes, and you know exactly which component class would have to change to make it something else.
For developers already familiar with Unitree or AgiBot-class platforms, reBot-DevArm offers the same sim-to-real loop, from data collection to policy deployment, at two orders of magnitude lower entry cost, with official and community documentation covering every step. If your goal is to validate embodied-AI algorithms on a fully reproducible, actively maintained, ecosystem-rich desktop platform, it is one of the few candidates worth a serious evaluation in 2026.
Sources
| Source | Type | Used for |
|---|---|---|
| WeChat article by (Tieweishi) | Original Chinese article this page adapts | Narrative structure, kit table, community caveats, resource list |
| Seeed-Projects/reBot-DevArm (README, licence section, roadmap, community) | Primary repository, state as of 2026-09-20 | Stars/forks, licence matrix and migration date, ecosystem table, inspirations, kit tiers, OSHWA mark |
| B601-DM hardware readme / B601-RS readme | BOM documents with prices | All BOM line items, recomputed totals (¥5,664.76 / $1,466.98), motor shares, v1.0/v1.1 changelog, printed/CNC averages, shipped-version divergence |
| Performance_Testing.md | Official thermal test report (DM, Damiao V4) | Dynamic and static test tables, recommended envelope, 12 Nm curve |
| Repository Git tree (419 blobs, fetched 2026-09-20) | Public inventory | File counts: 96 STEP, 10 STP, 92 STL, 171 PNG, 25 MD, 2 URDF |
This page is an independent technical adaptation for study and open-source exchange; it is not official Seeed Studio material and does not represent Seeed's positions. Repository state, prices and links change over time; treat the official repository and wiki as authoritative. No purchase is promoted here; kit prices are quoted as published facts.
Source:铁卫士 (WeChat)https://mp.weixin.qq.com/s/tJhWWmA5hb8kdwjV34m0yA