BLOG
Seeed's open-source six-axis arm in full: 96 STEP files, a screw-level BOM recomputed line by line (motors = 89.9%), the published thermal-test limits, the CERN-OHL-W-2.0 licence switch, and the LeRobot + GR00T N1.7 overnight autonomy loop.
Jev-style fixed-answer scoring reproduced locally with SGLang /v1/score: single-token labels, restricted softmax, confidence-gated routing, and a 6 ms vs 1088 ms benchmark against generation.
A deep read of TypeSafe's first System One Model: three question primitives, the economics of parallel calls, confidence-gated routing, eval caveats, eight jagged edges, and the OpenJev local repro.
The run book behind PaperRoute: mechanics before art, engine and look as separate threads, Blender driven by headless Python, Meshy for faces, review renders driving iteration, 39 tracked hours.
Meta distills compliance expertise into 200+ structured files, splits what the agent knows from how it reasons via recipes, and compiles expert fixes into regression-tested edits, no model retraining.
A robotics-oriented walkthrough of CAN: protocol contrast, 120Ω termination and differential levels, standard/extended frames, bit stuffing and bit timing, non-destructive arbitration, TEC/REC error states, plus when to reach for CAN FD or CANopen on joint and actuator buses.
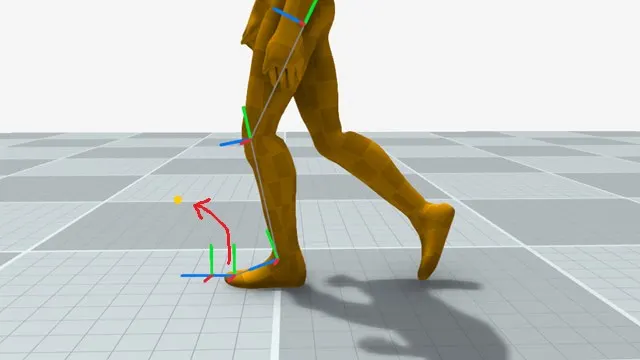
A practical recipe for foot sliding: solve the leg with soft-clamped two-bone IK and toe orientation, lock the toe target during contacts with inertialization, annotate contacts automatically, then use a position-based dynamics-style offline pass to distribute corrections. The key insight is velocity preservation, not sticking to the ground, and the toe—not the heel—is what should be locked.
A source-code grounded walkthrough of GPT-6 Astra: accessibility trees instead of pixel guessing, a persistent Node REPL, actions written as code, and a Guardian policy that blocks risky operations before execution.
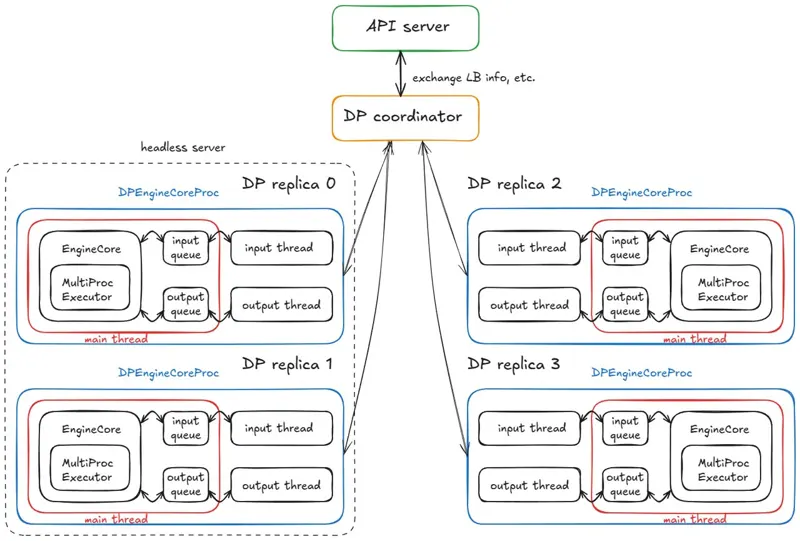
A systems walkthrough of vLLM: engine loop, scheduler, paged-attention KV blocks, continuous batching, prefix caching, speculative decoding, disaggregated P/D, multi-GPU executors, a two-node serving stack, and the latency-vs-throughput roofline.
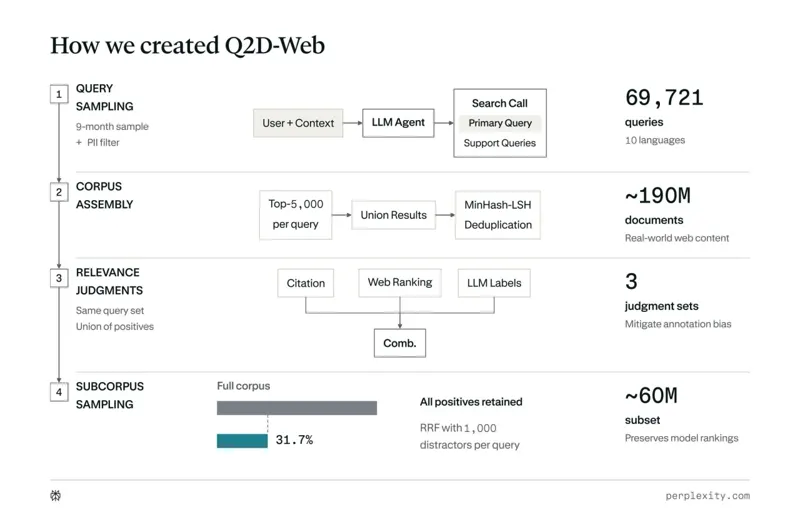
Perplexity released Q2D-Web, a retrieval benchmark with 190 million documents, 69,721 agent queries, three relevance sets, a public leaderboard, and a practical subsampled corpus.
IEEE Spectrum's Video Friday collected fourteen robotics clips this week. Nearly all of them show robots working in the real world rather than in a render. Agility's Digit drags a couch across a living room; SteadyTray's ReST-RL hierarchical reinforcement learning keeps unsecured payloads level on a Unitree G1, generalizing zero-shot sim-to-real across objects and external force disturbances; Figure argues that a robot in every home is a safety-and-cost problem rather than a data-and-compute one; CMU's APEX replaces choreographed motion with adaptive full-body maneuvers. NC State builds teardrop-shaped liquid-crystal elastomer soft robots that leap for as long as infrared light is on, with no battery, controller, or onboard sensing, and the University of Tokyo fits the musculoskeletal humanoid Musashi-W with a three-layer joint-covering skin carrying 44 pressure- and stretch-sensitive elements. DEEP Robotics' Lynx M20S hauls grape baskets in Turpan, where summer ground temperatures exceed 50 degrees Celsius, while ROBOTIS' first OH! GYM! student cohort goes from simulated motions to a physical AI Sapiens K1 in one month. The edition also carries the September-to-November event calendar: Humanoids Summit Seoul, IROS 2026, and CoRL 2026.
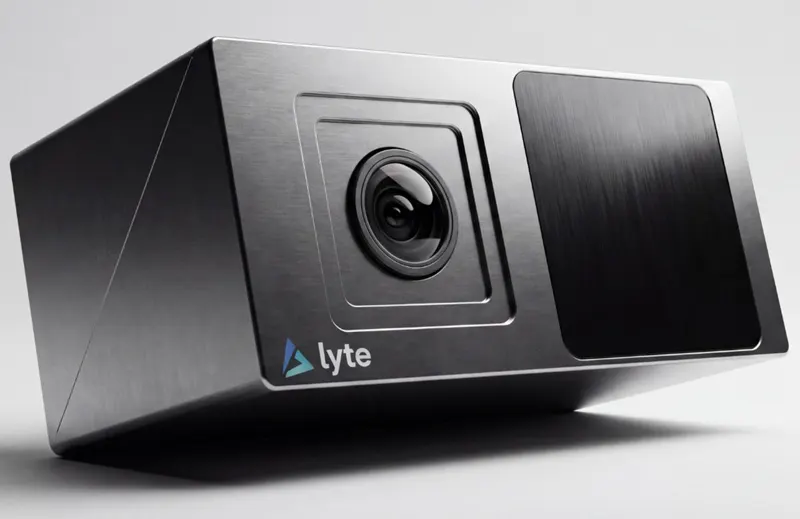
Perception silicon company Lyte has raised $165M in Series C at a $1.6B post-money valuation, led by Maverick Silicon with Fidelity participating. Lyte has now raised $272M since 2021, having exited stealth in January with $107M aggregate. Its LyteVision platform fuses 4D coherent vision, high-resolution RGB, and IMU onto a single synchronized timeline, measuring position and motion natively at the edge instead of reconstructing them in software. CEO Alexander Shpunt's framing: physical AI has a sensing problem before it has a model problem. LyteVision won CES 2026 Best of Innovation in Robotics and ships to inspection, logistics, and manufacturing customers; the new money goes to production scale, perception AI, and deployments.