Moon Spring Bio-mimicry
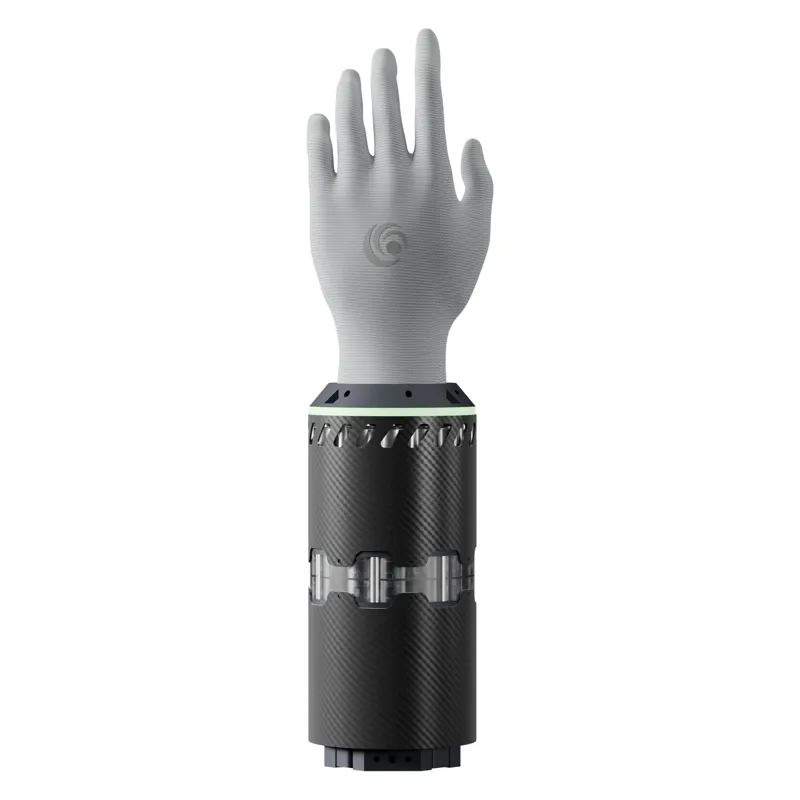
The Y-Hand M1 builds on Prof. Lei Ren's pioneering bionic tension-compression body robot theory: it replaces rigid hinges with joints capable of 3D 6-DOF motion, uses magnetic-collection electric-driven artificial muscles replicating human skeletal-muscle biomechanics, and a multi-layer rigid-flexible coupled design. With 38 whole-hand DOF it delivers 330 N grip (28.7 kg whole-hand grasp) and 180 N per-finger output; 0.2 s whole-hand close time; 0.04 mm fingertip positioning accuracy; and 59 mm/N finger compliance for safe, compliant physical interaction combining strength, speed, precision, dexterity and compliance.
COMPONENT
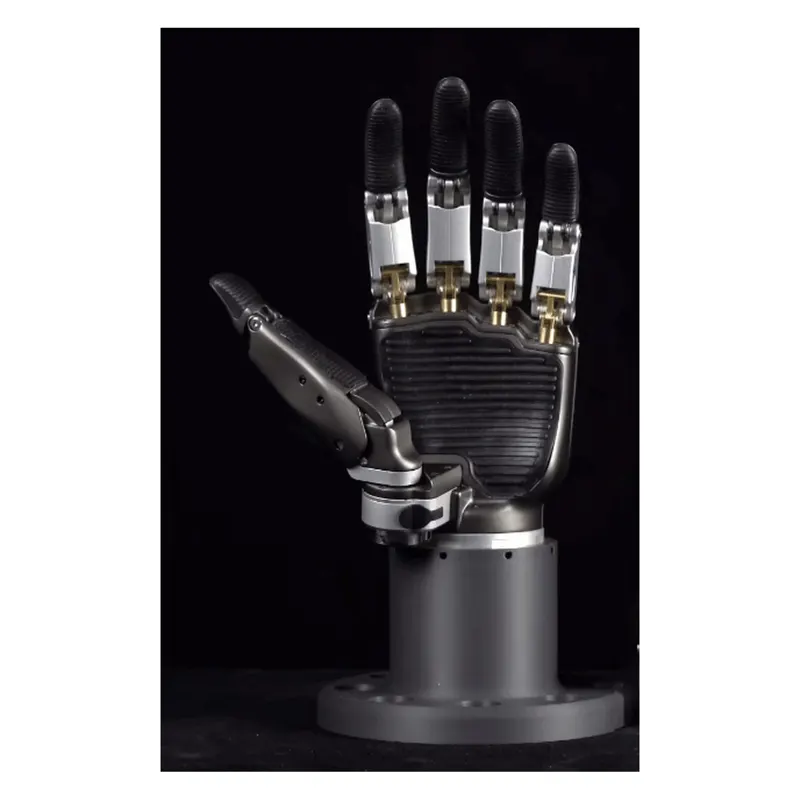
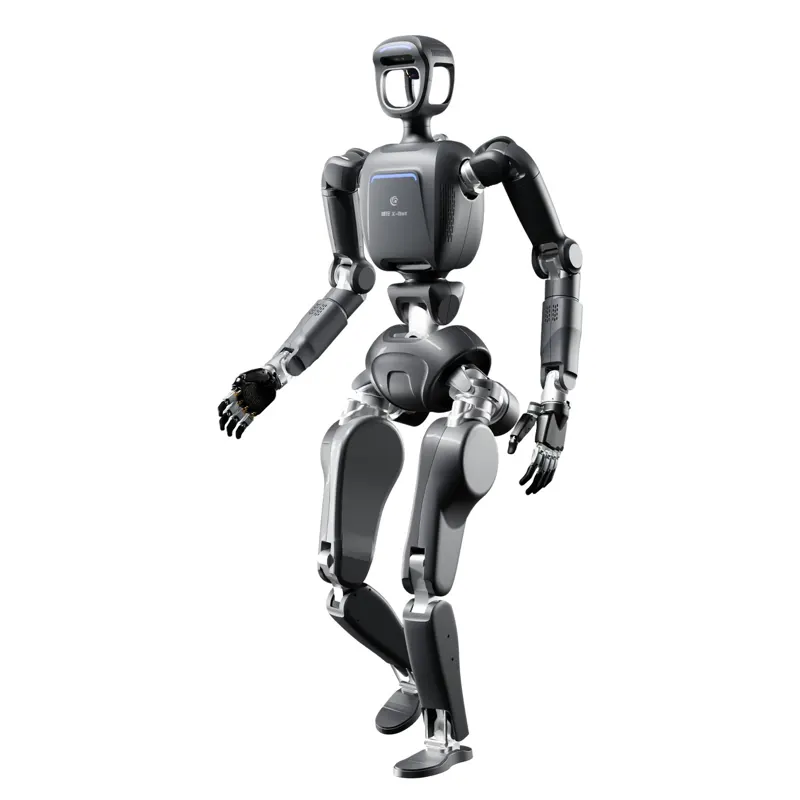
The X-Hand M1 is Yuequan Bionic's rigid bionic dexterous hand: 11 joints with human-like hand size and segment proportions, a bionic palmar arch and ring-shaped oblique-axis design driven by a high power-density motor matrix. Strong and fast: 100 N five-finger grip and 30 N fingertip force, 40 kg whole-hand lift capacity at only 630 g; 0.4 s five-finger close time with ±0.1 mm fingertip repeatability. Sensitive perception via 472 tactile sensing units. Ethernet interface with CAN/RS485 customization; pairs with the X-Bot and W-Bot humanoids.
 Humanoid