mimic-video: Video-Action Models for Generalizable Robot Control
Loading video
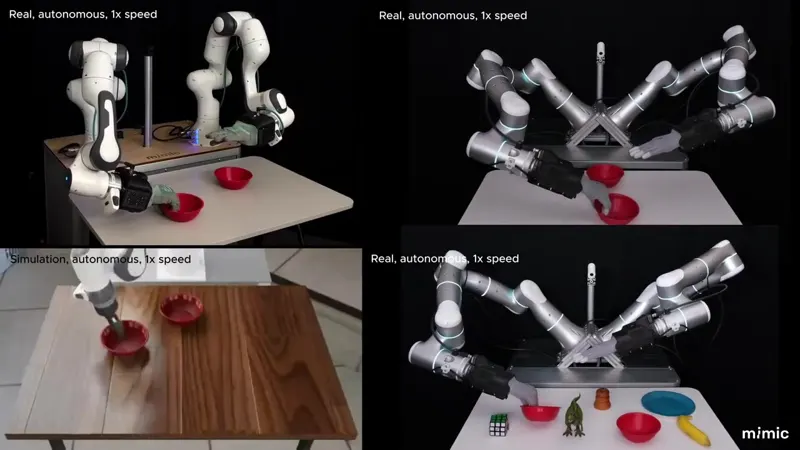
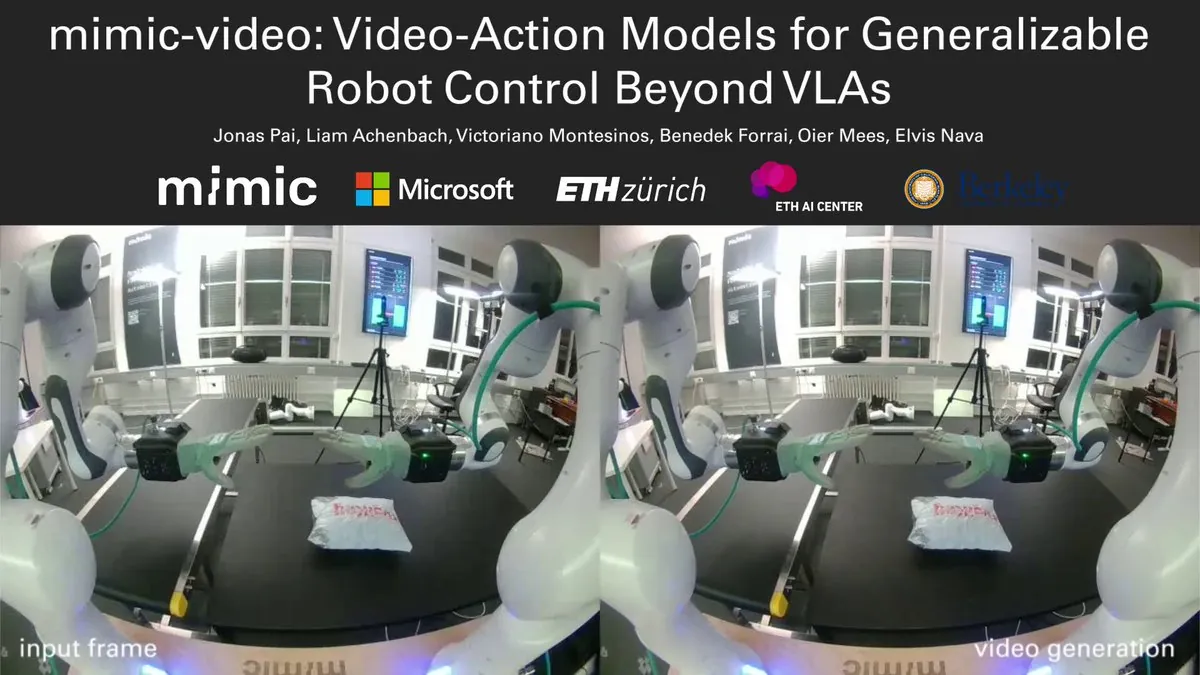
Loading videomimic-video keeps a pretrained video backbone frozen, extracts latent visual plans, and decodes low-level robot commands. The authors report 10x better sample efficiency and 2x faster convergence than VLA baselines across simulated and real bimanual manipulation.
Category: research
Author: @robotsdigest
Date: 2026-11-18T00:00:00
Duration: 127.893s
Reference: https://arxiv.org/abs/2512.15692