A Tactile Model Pretrained on 5,000 Hours of Real Contact
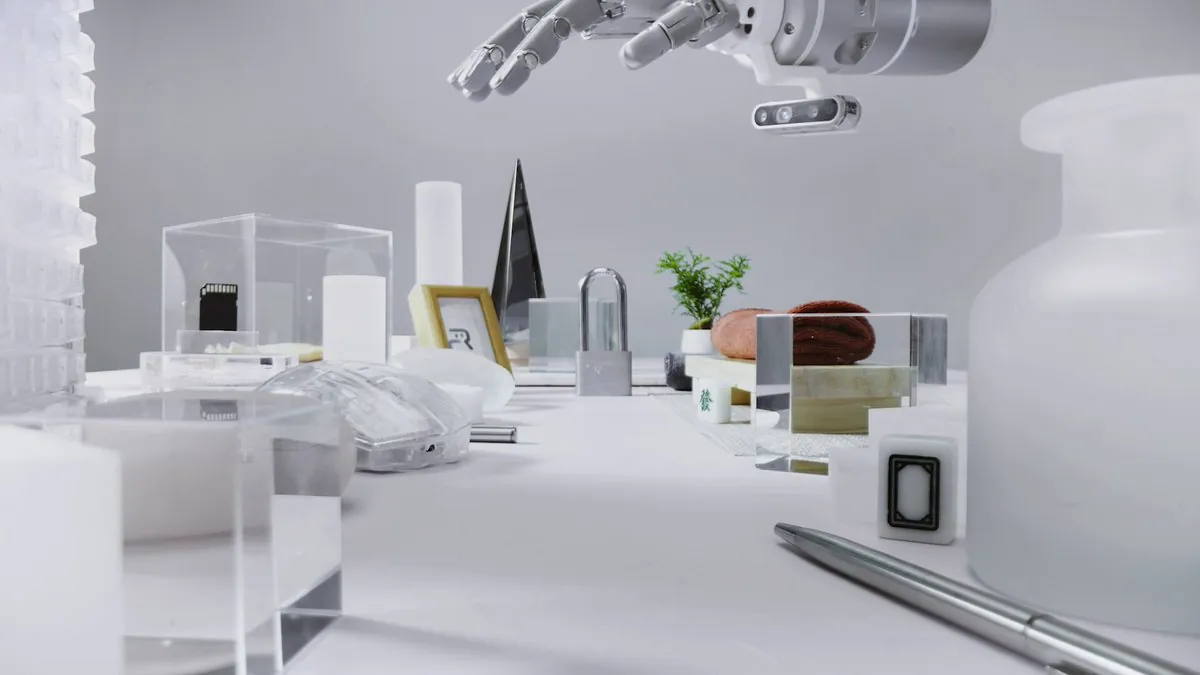
Loading video
Loading videoLingBot Touch is an open tactile foundation model pretrained on nearly 5,000 hours of real data, with transfer across sensors, hands, tasks, and action models.
Tactile SensingFoundation ModelsHeterogeneous SensorsDexterous ManipulationEmbodied AITactile Perception
Category: perception
Author: @robbyant_brain
Date: 2026-11-09T00:00:00
Duration: 96.68s