ACP: Humanoid Ladder and Platform Climbing via Attention-based Contacts
Loading video
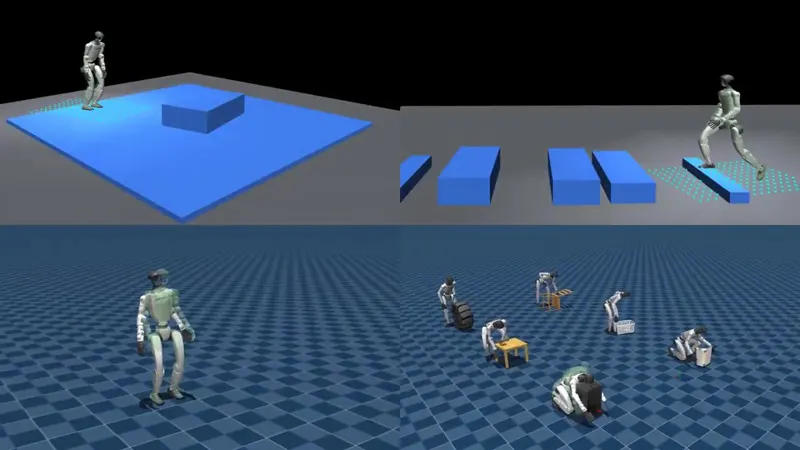
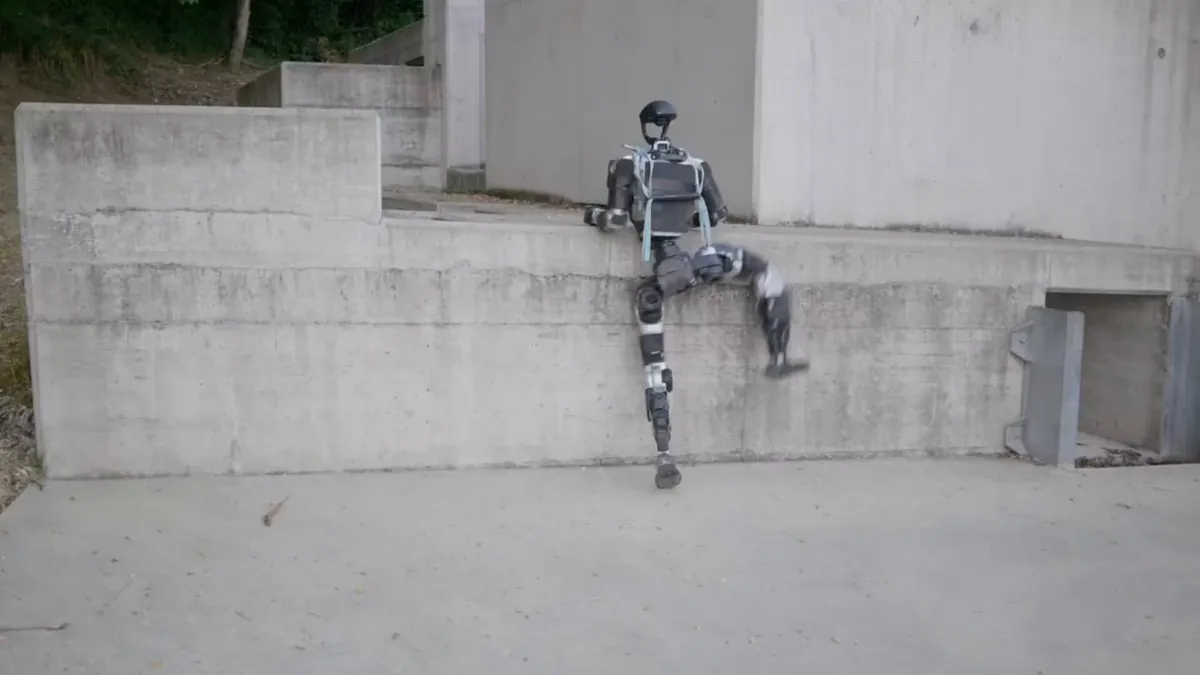
Loading videoETH Zurich ACP teaches a Unitree G1 to climb ladders and raised platforms with hands, feet and knees: 13.2 minutes of human demonstrations supply contact affordances, RL coordinates 23 joints, and onboard LiDAR plans contacts at runtime, chaining behaviors and recovering from failed attempts.
Category: humanoid
Author: @CyberRobooo
Date: 2026-10-23T00:00:00
Duration: 17.577s
Reference: https://arxiv.org/abs/2610.31608