BLOG
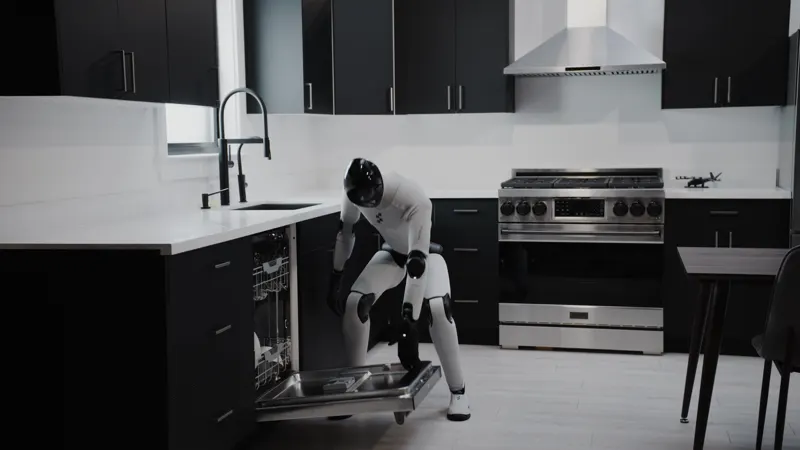
Figure AI releases Helix 02, extending single-network control from upper body to whole robot. System 0 trained on 1000+ hours of human motion data replaces 100K lines of hand-engineered C++, enabling 4-minute continuous autonomous loco-manipulation.
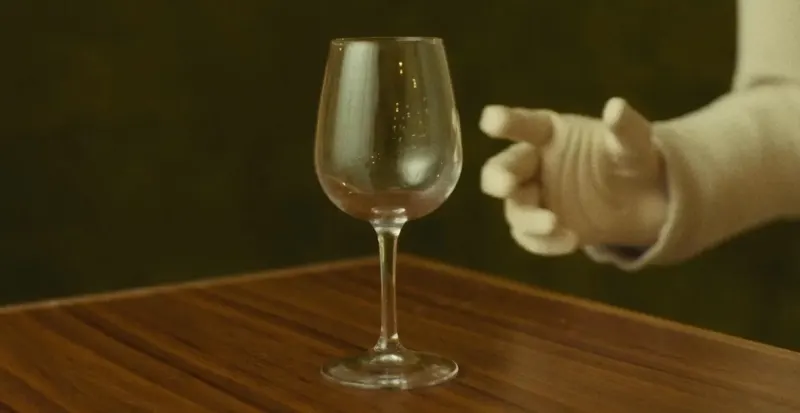
1X announces 25-DOF tendon-driven hands for NEO. Low gear ratios enable force transparency and backdrivability, combined with high-resolution tactile skin, turning every grasp into an experiment — a perception stack, not just an actuator.
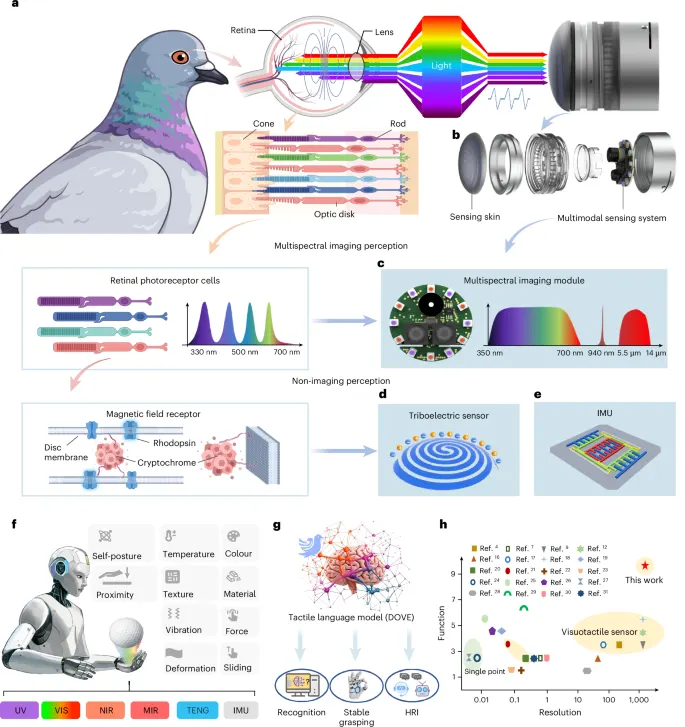
Published in Nature Sensors, SuperTac is a biomimetic multimodal tactile sensor inspired by pigeon multispectral vision. It integrates multispectral imaging, triboelectric and inertial sensing in a 1mm skin, achieving 0.06N force accuracy, 0.4mm position accuracy, and 94-100% classification accuracy across texture, material, colour, sliding and collision. The DOVE 8.5B tactile language model enables natural-language tactile understanding.