Unitree Dex5-1 Dexterous Hand
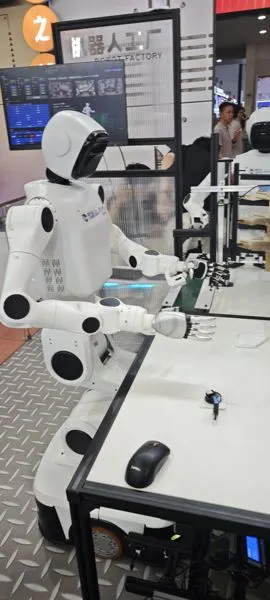
Unitree five-finger dexterous hand at 1100 g with 20 DoF (16 active: 4 thumb + 3 per finger), ±22° four-finger abduction, 10 mm minimum grasp diameter, ±1 mm fingertip repeatability and 10 N per-fingertip force; hollow-cup motors with low-backlash reducers, all joints back-drivable and fingers individually replaceable; 24-60 V supply (58V@0.2A static, 58V@4A peak), USB 2.0, -20~60°C; palm-down load 3.5 kg / palm-sideways 4.5 kg on a 5 cm rigid object; Dex5-1P adds 94 tactile sensors (palm 2×5, finger-belly 5×2×3, fingertip 5×2×3, finger-base 4×2×3 arrays).
COMPONENT
Dexterous HandUnitree RoboticsUnitree Dex5-1Tactile Sensing
 Humanoid