
Depth Anything V4: Dynamic 4D Scene Reconstruction via Riemannian Flow Matching on 4D Gaussian Splatting
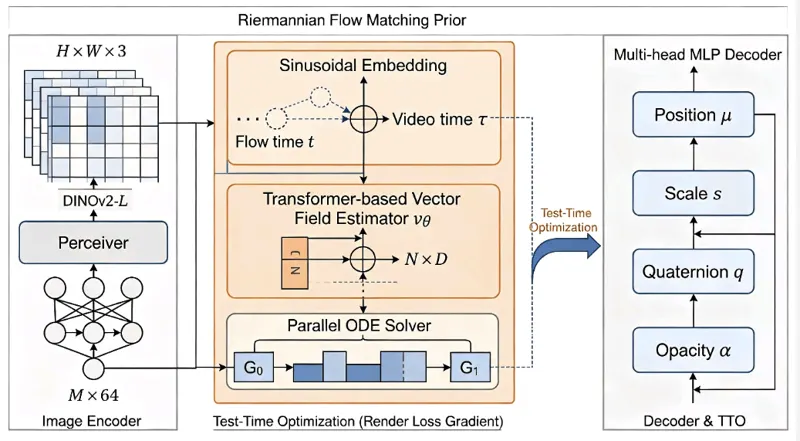
WITHDRAWN / archival entry: arXiv marks this paper as withdrawn by its authors (v2, 20 Aug 2026, 1 KB record, comment: “Major errors in research”); it is kept here for critical reading only. The paper itself proposes Depth Anything V4 (DAV4), dynamic 4D scene reconstruction from monocular video by defining Riemannian Flow Matching (RFM) directly on the non-Euclidean manifolds of 4D Gaussian Splatting parameters (scale, rotation, opacity), so every intermediate state on the probability path remains valid without post-hoc projection. A deterministic MLP baseline sharing the same data, architecture and test-time optimization (TTO) protocol isolates the contribution: MLP+TTO scores 0.762 F-score versus 0.806 for RFM+TTO, a +0.044 isolated gain, while Euclidean flow matching with projection reaches only 0.684 with 12.3% invalid Gaussians. Pre-training costs 360 GPU-hours and amortizes only beyond roughly 10,000 scenes; uncertainty is quantified via negative Gaussian log-likelihood and expected calibration error; no human-annotated depth labels are used as training losses.