SuperMimic: Scaling Humanoid Whole-Body Control with One Differentiable World Model
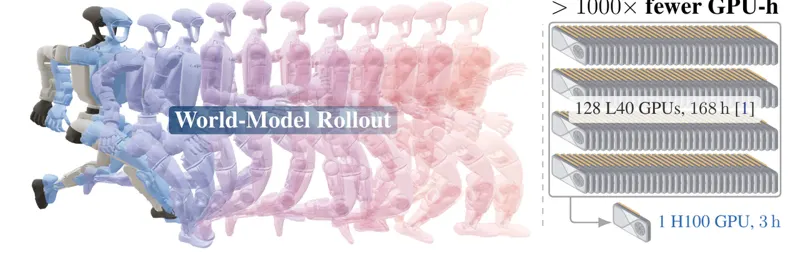
SuperMimic fits one differentiable world model from simulator transitions and uses short imagined rollouts to train a general humanoid tracker. It surpasses SONIC in three hours on one H100, then reaches zero failures on 129,514 motions after 9.8 hours on two H100s.
Qiayuan Liao, Yiyang Shao, Junfeng Long · 70 views · Oct 20, 2026
HumanoidWorld Models
Oct 20, 2026