Skip to content
← Tags

#Loco-manipulation (10)

HOTICE: Whole-Body Humanoid Object Transportation in Cluttered Environments

HOTICE: Whole-Body Humanoid Object Transportation in Cluttered Environments

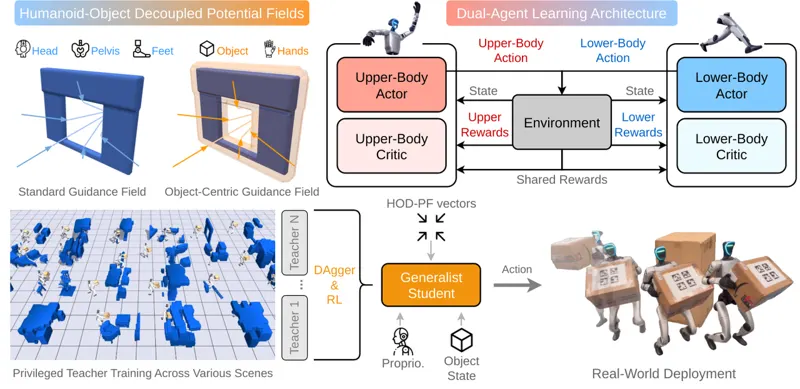
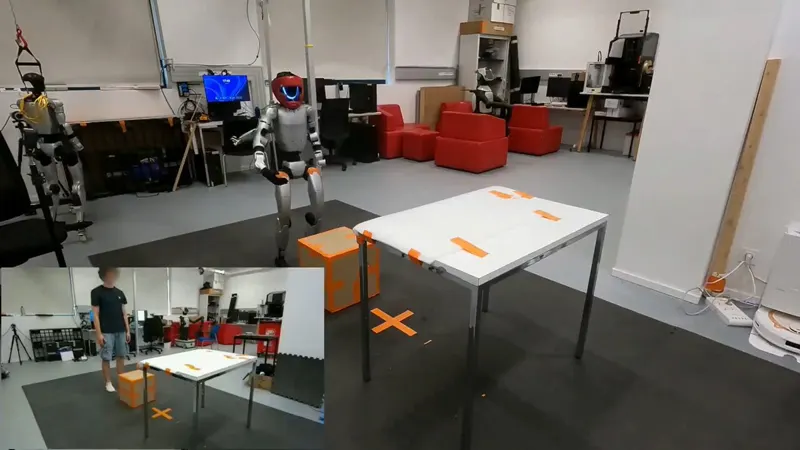
Object transportation is a fundamental capability for humanoid robots operating in real-world, human-centric environments, yet existing methods struggle when clutter constrains free space around both the robot and its carried payload. We present HOTICE, a whole-body humanoid learning framework for transporting objects through such cluttered environments. First, we introduce Humanoid-Object Decoupled Potential Fields, which jointly encode collision-avoidance guidance for the robot and the carried object, enabling coordinated, obstacle-aware motion for both. Second, to address the large action space inherent to whole-body loco-manipulation, we design a dual-agent reinforcement learning architecture that decouples upper- and lower-body control while preserving whole-body coordination via shared state observations and rewards. To train a policy that generalizes across diverse cluttered scenes, we further employ a specialist-to-generalist distillation strategy, in which privileged teacher policies are distilled into a single deployable student policy. We evaluate HOTICE in MuJoCo simulation and on a real Unitree G1 humanoid, demonstrating effective and robust object transportation across cluttered scenarios for objects of varying shapes. Our results show that HOTICE reliably coordinates whole-body motion and object-aware collision avoidance, generalizing effectively to previously unseen cluttered environments while achieving strong performance in sim2real deployment.
Toan Nguyen, Weiduo Yuan, Siheng Zhao · 124 views · Sep 21, 2026
HumanoidLoco-manipulation
Sep 21, 2026
HAF: Adapting Generalist VLAs to Humanoid Whole-Body Loco-manipulation via Hierarchical Action Flow and Spectral Latent RL

HAF: Adapting Generalist VLAs to Humanoid Whole-Body Loco-manipulation via Hierarchical Action Flow and Spectral Latent RL

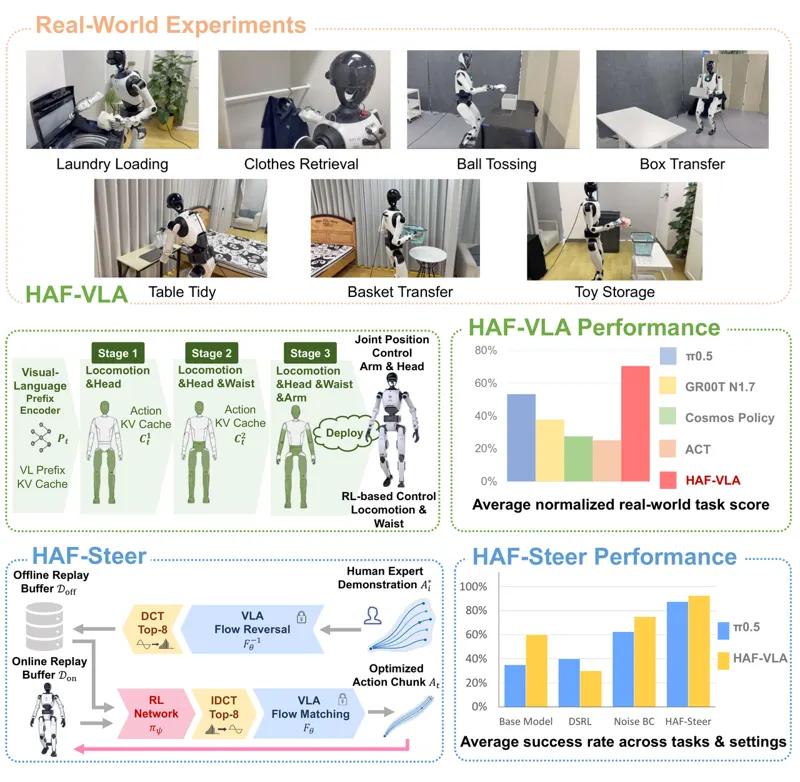
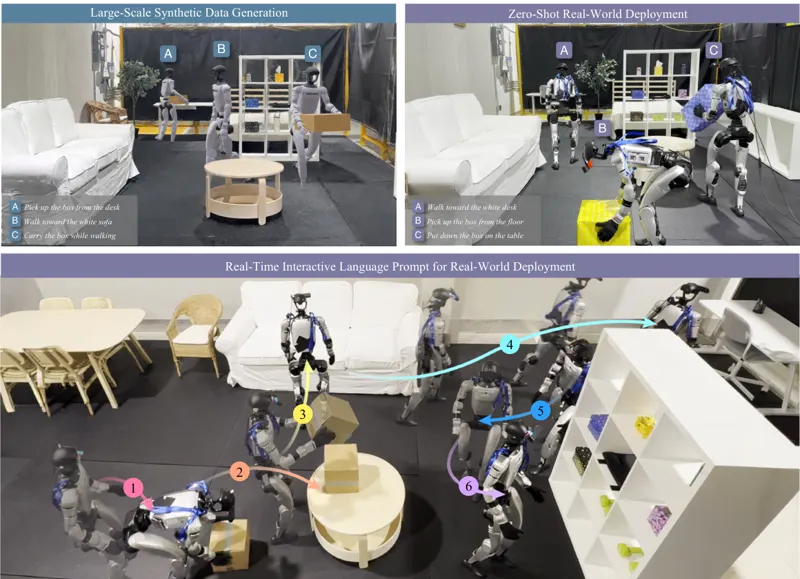
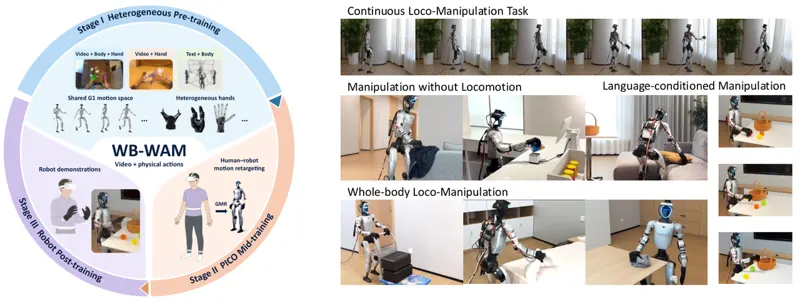
Humanoid robots hold great promise as general-purpose agents in human-centered environments, yet generalist vision-language-action (VLA) foundation models are not readily applicable to humanoid whole-body loco-manipulation. The high dimensionality and interdependence of humanoid motions make it challenging for conventional single-stage VLA architectures to coordinate locomotion, waist posture, and dual-arm manipulation effectively. Moreover, policies trained through offline behavior cloning can remain suboptimal during real-world deployment. Although online reinforcement learning can refine policies through real-world interaction, directly tuning large VLA backbones demands excessive computation and may introduce safety risks during real-robot exploration. To address these bottlenecks, we introduce HAF (Humanoid Adaptation Framework), a two-part framework consisting of HAF-VLA and HAF-Steer that transfers off-the-shelf generalist VLA foundation models to humanoid whole-body loco-manipulation. HAF-VLA is a hierarchical action-flow generator built on a pretrained flow-matching VLA. It splits full-body action denoising into three sequential stages with stage embeddings and cross-stage KV caches that retain kinematic dependencies, avoiding incoherent whole-body actions from one-shot generation. On top of the frozen HAF-VLA, HAF-Steer is a latent offline-to-online RL pipeline that leverages flow-matching invertibility and DCT-based dimensionality reduction to restrict RL optimization to a compact noise subspace and train a regularized SAC policy. This avoids updating the large VLA backbone and enables efficient real-world policy refinement. Evaluated on seven real-world humanoid loco-manipulation tasks, HAF surpasses vanilla single-stage VLA baselines and improves whole-body coordination and task performance. Project website: https://grange007.github.io/HAF .

Langzhe Gu, Chengkai Hou, Meng Li · 751 views · Aug 17, 2026
VLAHumanoid
Aug 17, 2026
CoorDex: Coordinating Body and Hand Priors for Continuous Dexterous Humanoid Loco-Manipulation

CoorDex: Coordinating Body and Hand Priors for Continuous Dexterous Humanoid Loco-Manipulation

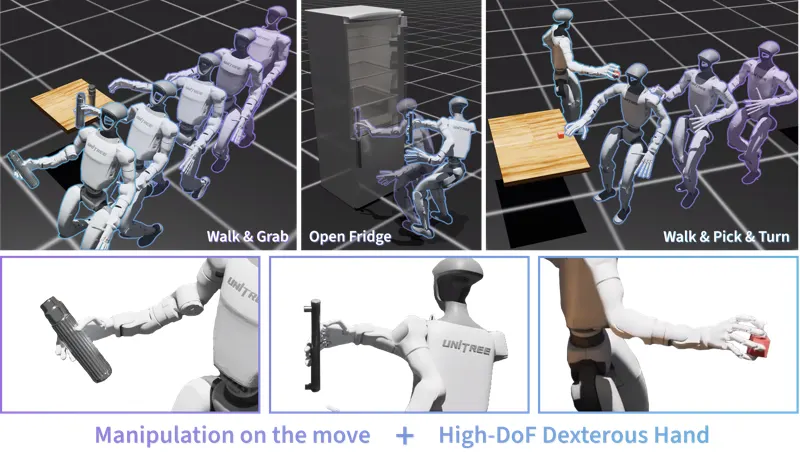
Humanoid loco-manipulation is often simplified into a stop-and-go process: walking to an object, stopping to manipulate it, and then resuming locomotion. It also commonly relies on low degree-of-freedom (DoF) end effectors that behave like an open-close grasp primitive. We introduce CoorDex, a learning pipeline that converts high-dimensional body and dexterous hand control into coordinated latent residual control, enabling high-DoF dexterous loco-manipulation on the move. Starting from simulated whole-body and hand demonstrations, CoorDex trains privileged motion tracking teachers for the humanoid body and dexterous hand, distills them into proprioception-conditioned latent priors, and uses the frozen priors as the action space for downstream residual reinforcement learning. A coordinated latent residual policy composes these priors through shared task context and separate body-hand residual heads, preserving natural whole-body motion while improving finger-level contact reliability. CoorDex enables a Unitree G1 humanoid with a 20-DoF WUJI hand to execute dexterous manipulation while in motion, including non-stop bottle grasping and carrying, fridge door opening on the move, and cube pick-and-turn. Ablations on the walk-grasp-carry task show that joint-space PPO, joint-space hand control, and monolithic latent prediction all fail under the same reward budget, while the latent-prior interface and coordinated residual structure make high-dimensional contact-rich loco-manipulation trainable. Project Page: https://skevinci.github.io/coordex/

Sikai Li, Shuning Li, Zhenyu Wei · 515 views · Jun 22, 2026
Loco-manipulationCoorDex
Jun 22, 2026

As an Amazon Associate, we earn from qualifying purchases.