
Adaptive Whole-Body MPC with Optimal Posture Planning for Humanoid Robots under Unknown Payloads
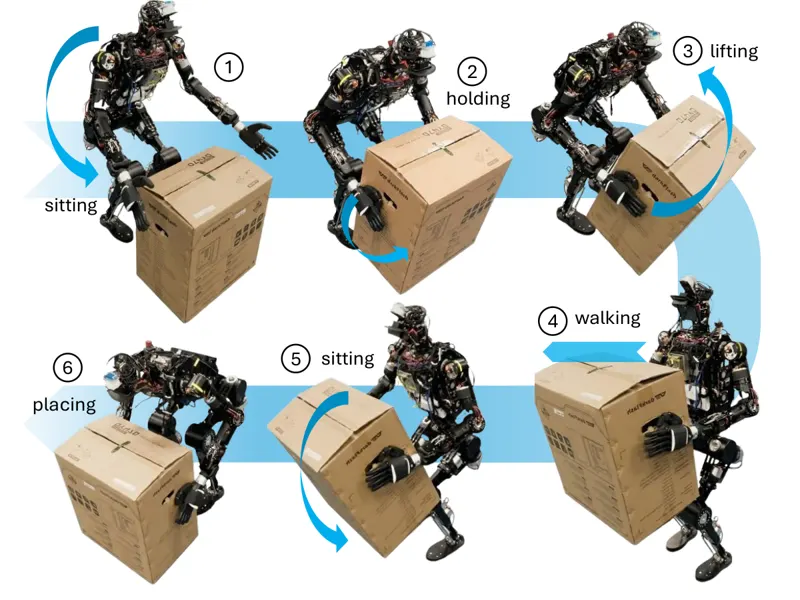
When a humanoid lifts an unknown payload, abrupt changes in mass, center of mass, and inertia destabilize whole-body control. The paper couples centroidal MPC, adaptive fuzzy balance compensation driven by capture-point error, and triple-integrator posture-transition planning. MPC produces motion references under contact, friction, and joint constraints; fuzzy compensation allocates corrective torques to stance legs; and the planner generates smooth, feasible sit-to-stand and stand-to-sit trajectories. MuJoCo simulation and a 28-DoF humanoid validate stable lifting with 7 kg and 10 kg payloads and robust 7 kg load-carrying during walking.
Manh Cuong Nguyen, Duc Cuong Vu, Viet Anh Vu · 32 views · Oct 9, 2026
HumanoidWhole-Body Control
Oct 9, 2026