RPL: Learning Robust Humanoid Perceptive Locomotion on Challenging Terrains
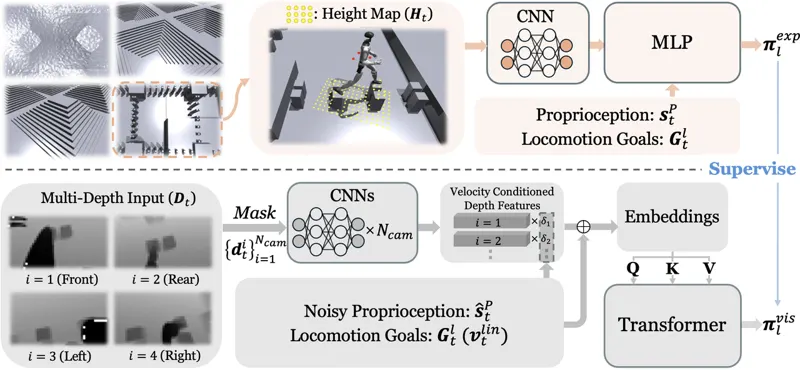
RPL uses a two-stage framework that distills terrain-specific height-map experts into a unified depth-based transformer policy, enabling robust bidirectional humanoid locomotion with payloads on slopes, stairs, and stepping stones.
Yuanhang Zhang, Younggyo Seo, Juyue Chen·Feb 3, 2026
Unitree G1HumanoidPerceptive LocomotionFeb 3, 2026
 1:25