
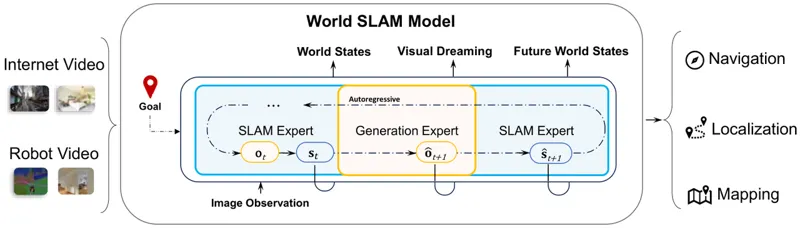
World SLAM Model: Joint World Modeling for SLAM and Navigation
World SLAM Model (WSM) embeds the mechanisms of SLAM, including persistent memory, incremental state updates, and local backend refinement, directly into a navigation world model. A unified Mixture-of-Transformers jointly predicts future RGB observations, dense depth, and camera poses from RGB input, enabling closed-loop navigation with accurate localization and mapping.
Minghui Qin, Yijun Yuan, Weicheng Zheng · 7 views · Sep 26, 2026
World ModelsSLAM
Sep 26, 2026