LEAP Hand Low-Cost Open-Source Dexterous Hand
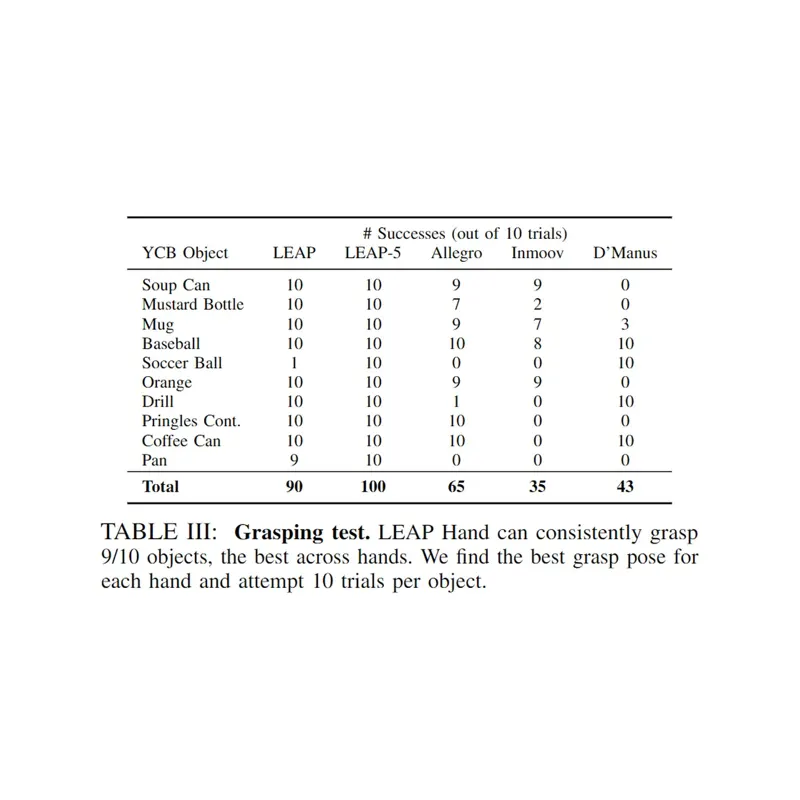
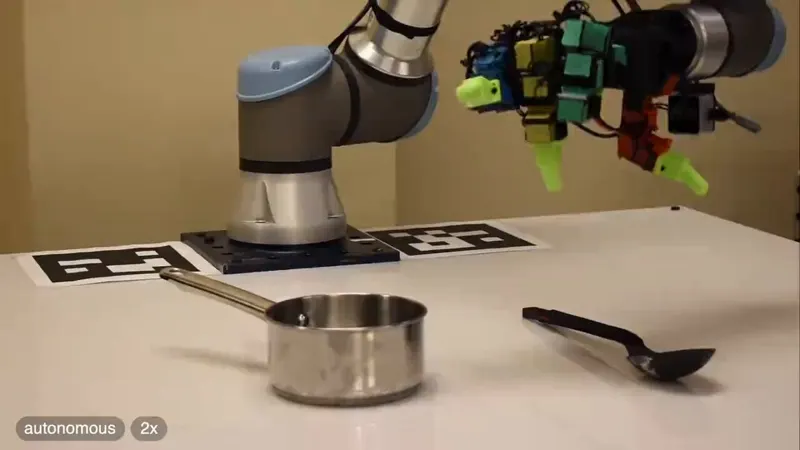
LEAP Hand is an open-source four-finger dexterous hand from Carnegie Mellon University (Kenneth Shaw, Ananye Agrawal, Deepak Pathak; RSS 2023): 16 DoF (4 per finger) at a total cost under $2,000, assemblable in under 3 hours using only common hand tools, and roughly 1/8 the cost of the Allegro Hand while achieving superior dexterity thanks to universal abduction-adduction kinematics. The project releases the URDF model, 3D CAD files, a tuned Isaac Gym / Isaac Lab simulation environment and Sim2Real training code, making it a popular low-cost platform for grasp and manipulation research, teleoperation and 3D-printable replication.
COMPONENT
Dexterous HandLEAP HandCMUOpen-source hardwareRSS 2023
 0:46