3D Point World Models: Point Completion Enables More Accurate Dynamics Learning
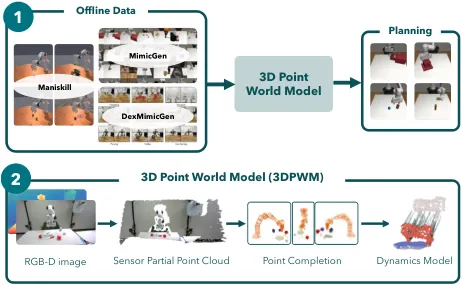
Learning predictive models of the world enables robotic control through planning and can allow robots to improvise on new tasks. Video-based dynamics models lack explicit 3D structure and accumulate geometric inconsistencies, while existing partial-point-cloud world models remain sensitive to occlusion and rollout drift. 3DPWM first completes segmented object geometry from a single calibrated RGB-D view and robot joint angles, then learns action-conditioned per-point dynamics over the completed scene. Experiments across seven datasets and two embodiments show accurate 100-300 step rollouts, stronger reward correlation, improved open-loop and closed-loop planning, adaptation to an unseen long-horizon task, and sim-to-real transfer.
Skand Peri, Hung Nguyen, Chanho Kim · 13 views · Jun 30, 2026
3D World ModelPoint Cloud Completion
Jun 30, 2026