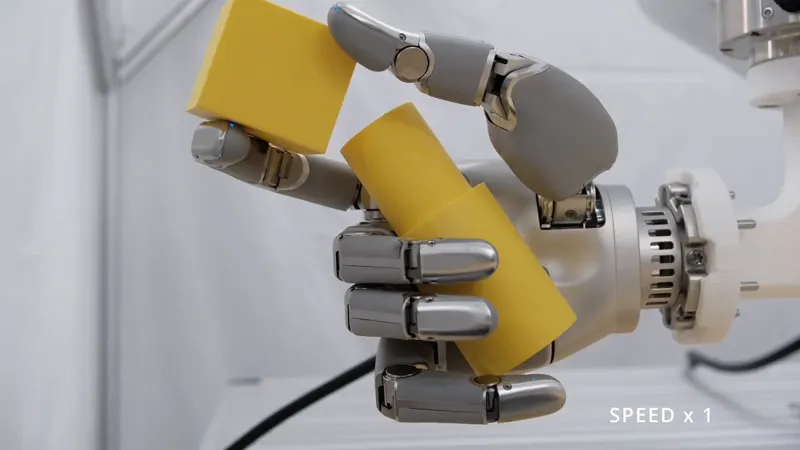
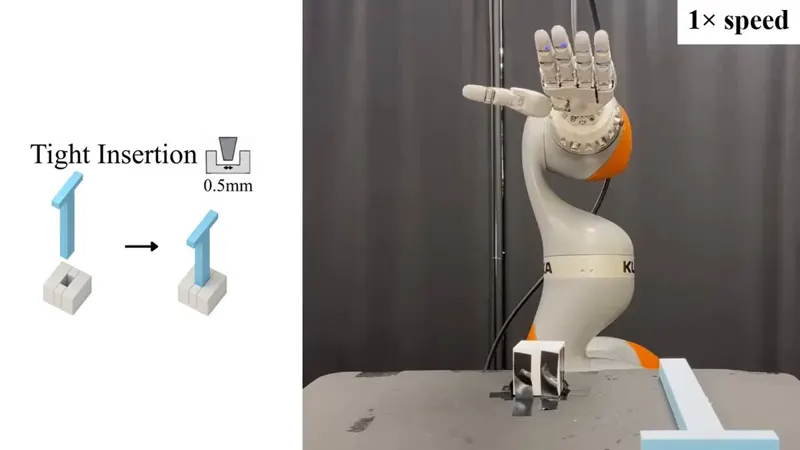
Blind Tight-Clearance Assembly from Proprioception Alone, Zero-Shot to Real Robots
Loading video
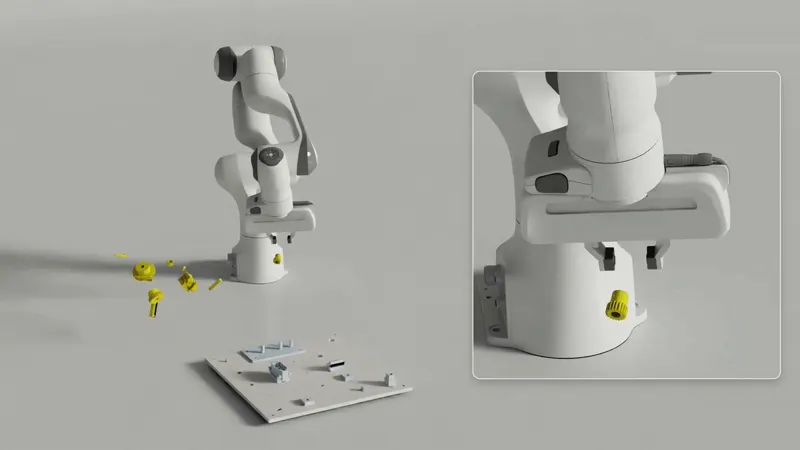
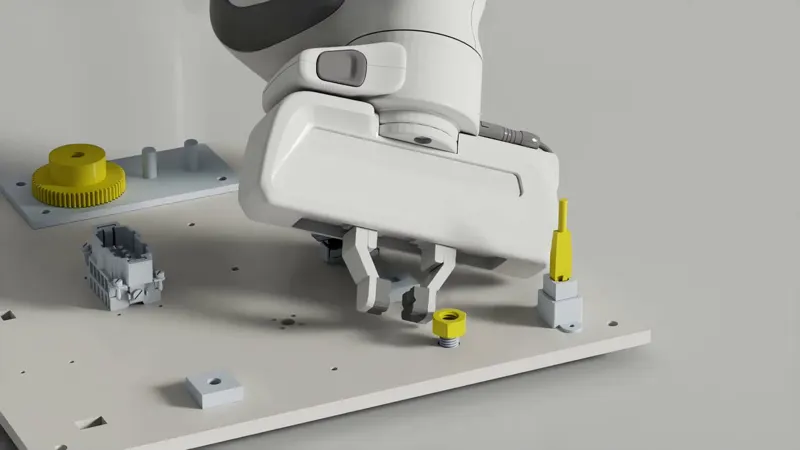
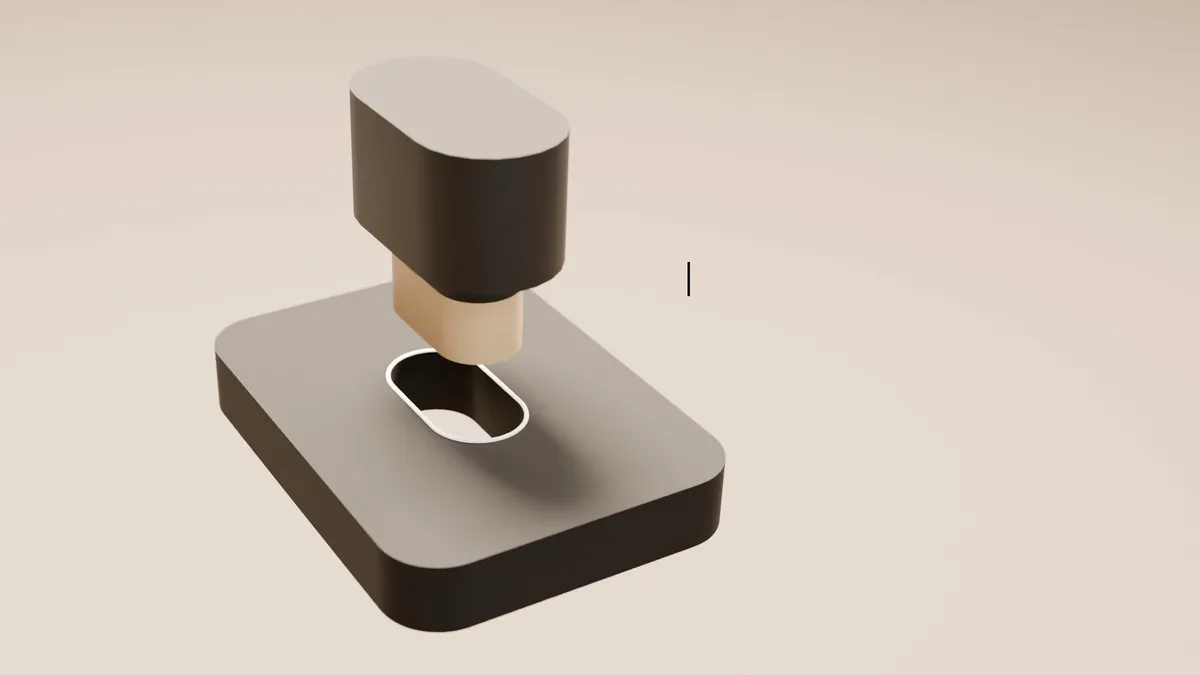
Loading videoNo cameras, no tactile or force-torque sensing, no priors on object geometry or pose — only joint position readings. Sim-trained blind policies insert pegs, mesh gears and thread nuts; the peg policy transfers zero-shot, inserting unseen pegs in 73% of real trials.
Category: arm
Author: @younghyo_park
Date: 2026-10-19T00:00:00
Duration: 35.6s
Reference: https://arxiv.org/abs/2610.23849