Draft: Parametric Robot Design Exploration Without Rebuilding CAD
Loading video
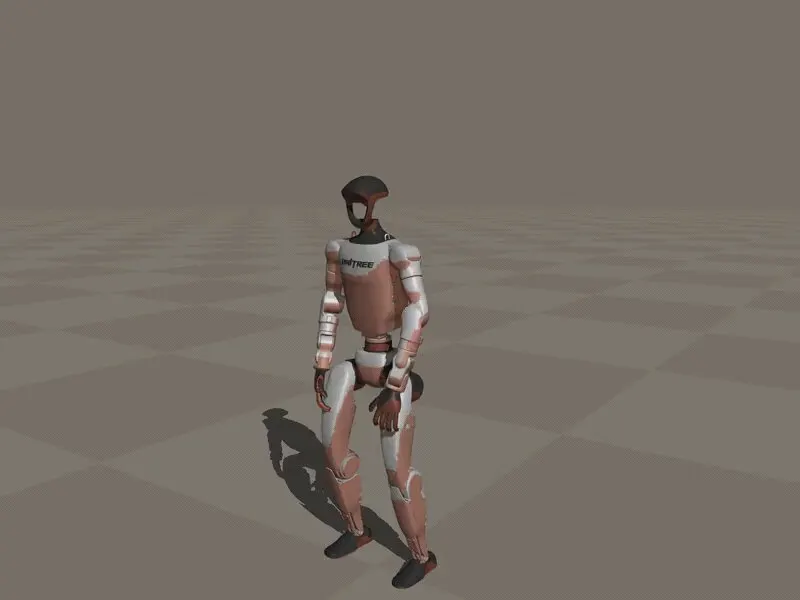
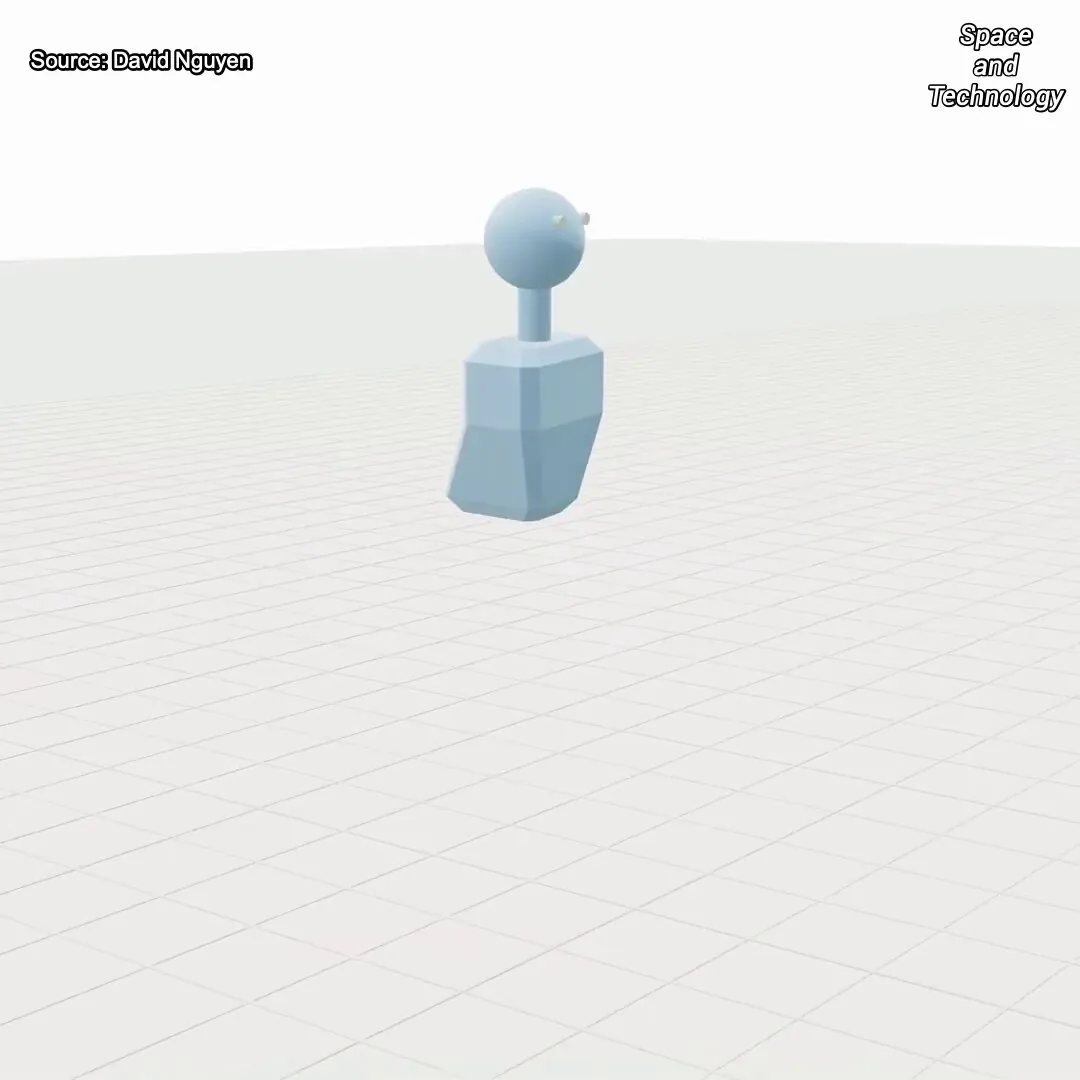
Loading videoDraft is a parametric generation tool from MIT whose generalised engine compiles any parametric tree of serial chains into a simulation-ready MJCF model with no CAD step in between, so engineers can adjust limb length, body size or motor power and immediately test how the change affects controller performance in simulation. Free parameters are grounded by trends fitted to a survey of 114 actuators and 49 published robot descriptions, and reinforcement learning is used to estimate whether a design is feasible.
Category: research
Author: @spaceandtech_
Date: 2026-10-11T00:00:00
Duration: 25.7s
Reference: https://arxiv.org/abs/2609.38405