NVIDIA open-sources Lyra 2.0: one image becomes an explorable 3D world, exportable to Isaac Sim for robot simulation
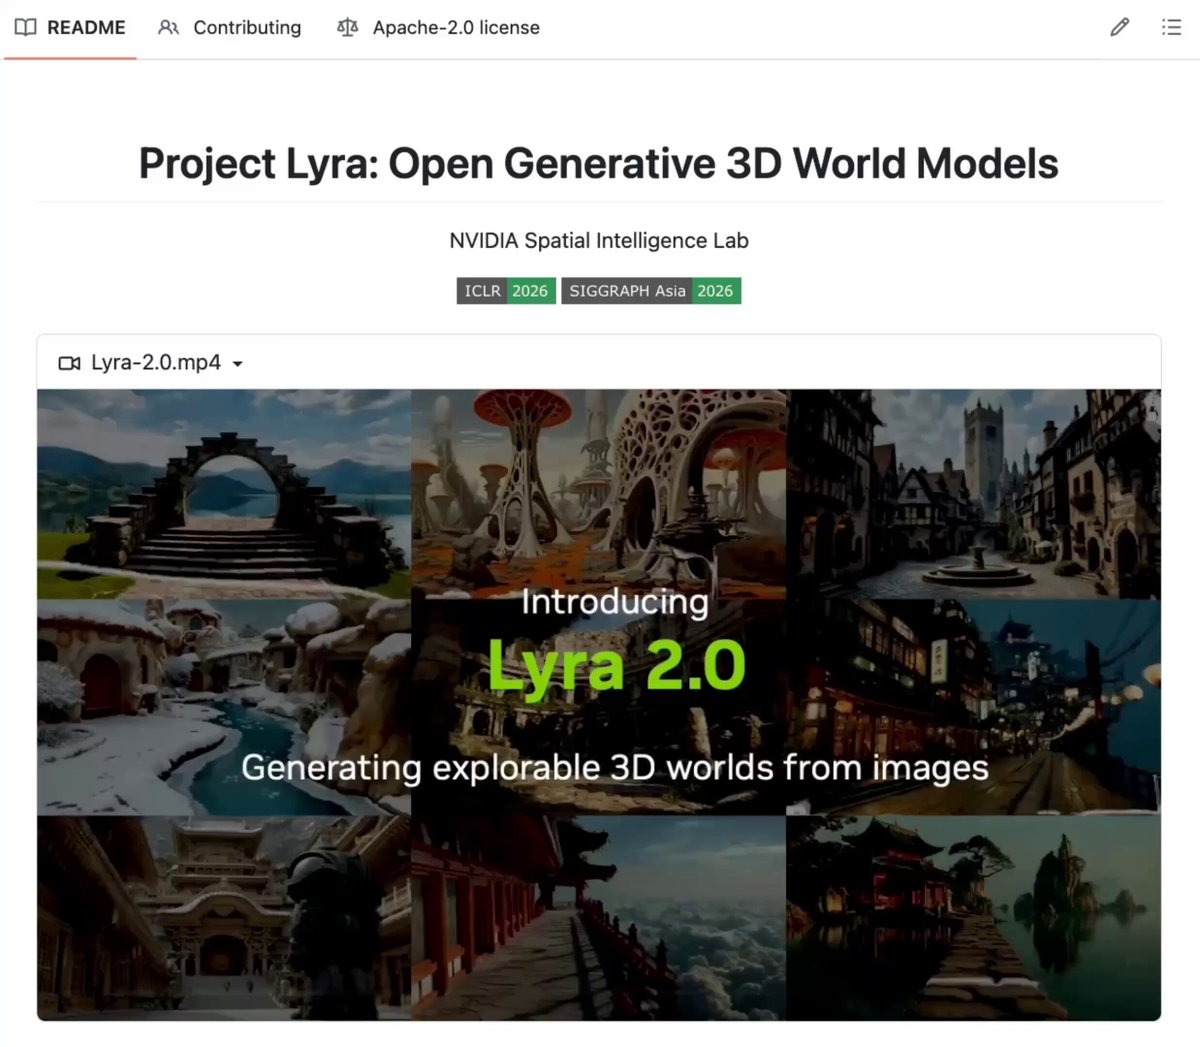
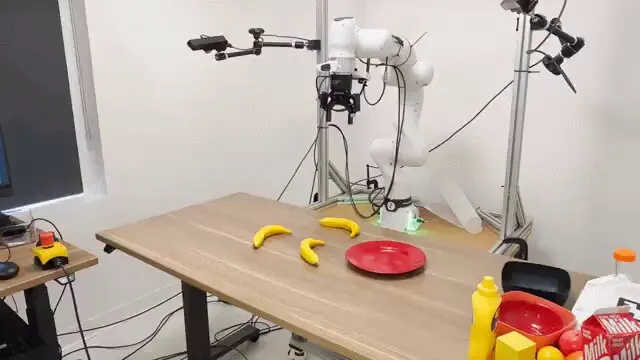
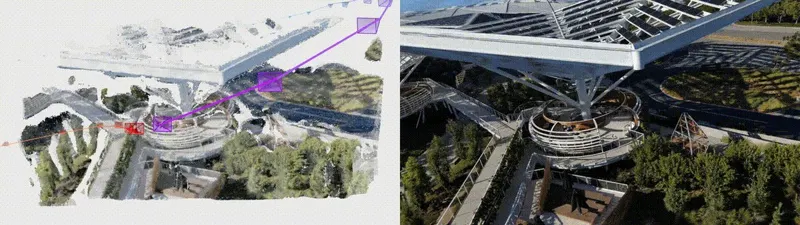
NVIDIA Spatial Intelligence Lab open-sourced Lyra 2.0 (SIGGRAPH Asia 2026, Apache-2.0 code, github.com/nv-tlabs/lyra, 2.2k stars): a single image + user-defined camera trajectory + per-chunk captions → long-horizon 3D-consistent exploration video → feed-forward reconstruction (Depth Anything v3) into 3DGS/meshes. Two key designs: an explicit 3D proxy used only for information routing (retrieving relevant history frames, establishing dense correspondences) to fight spatial forgetting; self-augmented history training teaches the model to correct its own drift rather than propagate it. An interactive GUI supports lookbacks and venturing into unobserved areas (~90m navigation demo); generated scenes export to physics engines — demonstrated in Isaac Sim for physically grounded robot navigation and interaction, enabling scalable embodied-AI simulation without real-world 3D acquisition.