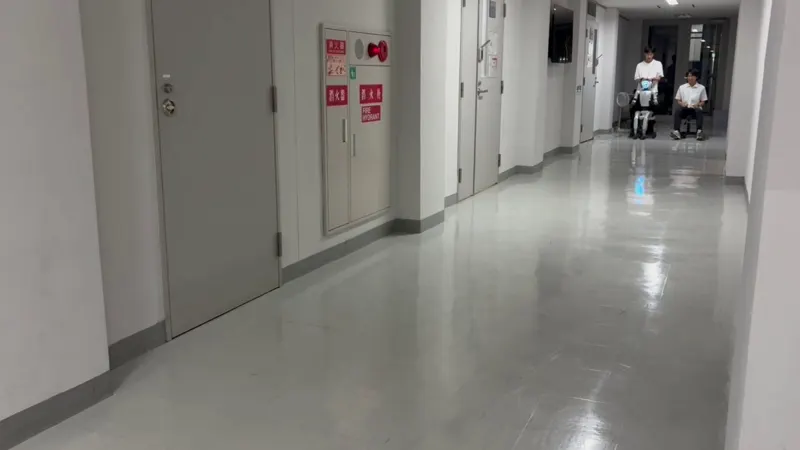
A Unitree G1 is placed on a plain office chair and taught to drive it with its feet. No motors in the chair and no chair or contact sensing at deployment: proprioception plus a velocity command only, sim-to-real and zero-shot. A fun demo, but the point is broader, that humanoid locomotion can generalize to new substrates and vehicles.
VLA-Precision (USTC) performs real-world online RL post-training of large VLAs via asymmetric co-bootstrapping (ACoB) - rapid behavioral learning coupled with progressive value calibration to suppress policy drift - and the ACoB-Stream architecture delivering up to 10.9x throughput gains. Across nine high-precision chemistry tasks and four robot embodiments it achieves 98.3% mean success in 45.8 min/task with 27.6 s episodes (1.2x/1.8x faster than VLA/RL baselines) and a 0.024% intervention rate. Code released.
Su, Chenyu, Shen, Zhaolong, Qian, Yuan
UMR learns dense point cloud correspondence for humanoid motion retargeting, removing manual mappings and enabling scalable, detailed pose reproduction.
Hanyang Cao, Yuetong Fang, Taesoo Kwon
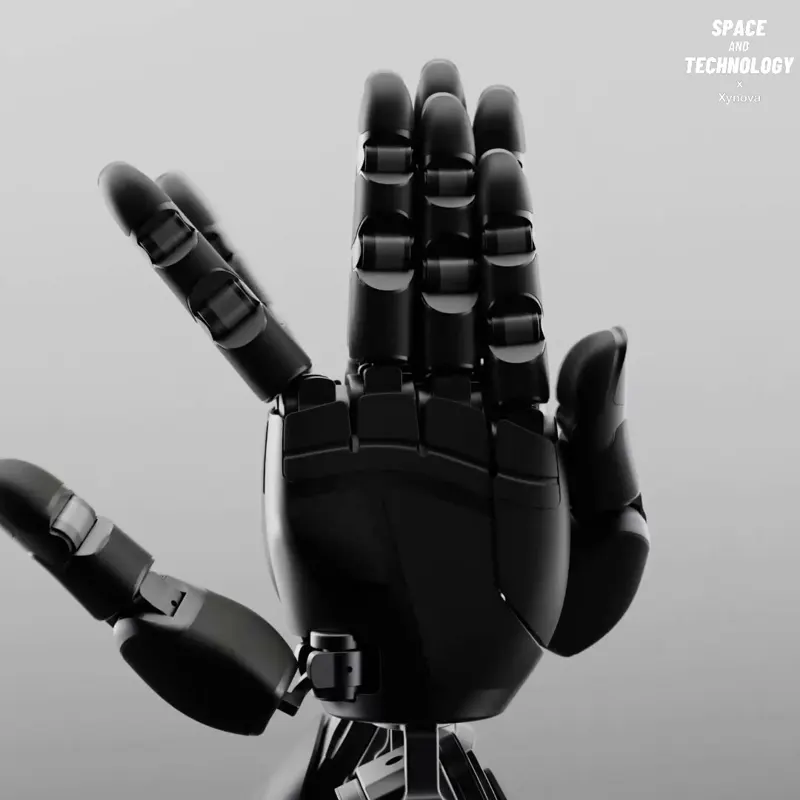
Xynova introduced Prima 1, a 22-DOF robotic hand combining vision and touch sensing with direct-drive motors for fast motion and lifting up to 20 kg.
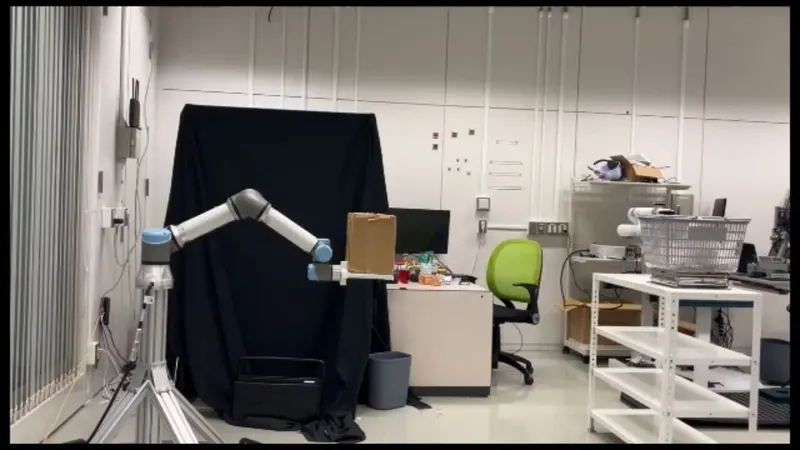
A UR5e arm skips grasping and uses sliding and rolling contact on its end-effector to accelerate and launch objects toward targets. The RL policy is trained in simulation and transferred zero-shot to the real robot, handling objects up to 790 g with high success.
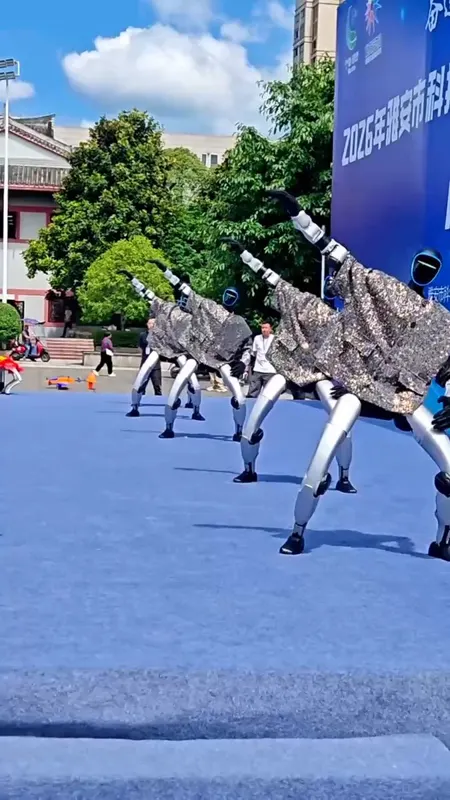
Five $16,000 Unitree humanoids in sequined jackets perform as an autonomous synchronized swarm on an outdoor stage, executing coordinated deep squats and lateral moves that highlight real-time spatial coordination and group intelligence.
A post-trained NVIDIA Cosmos 3 Edge policy runs onboard Jetson AGX Thor T5000, generating enough action output to cover about 2.13 seconds of robot motion in roughly 1.53 seconds, then replans from fresh camera and state data for continuous arm control.
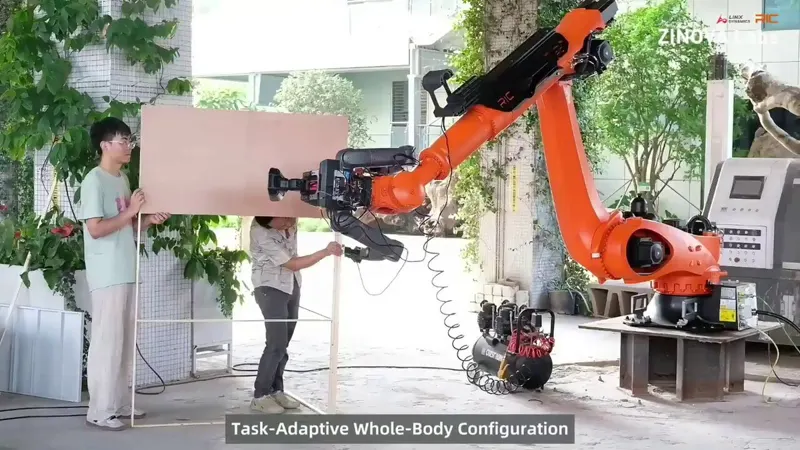
LimX showcases TRON 2 attached to an industrial robotic arm, bringing manipulation directly to the task instead of rebuilding the workspace around the robot.
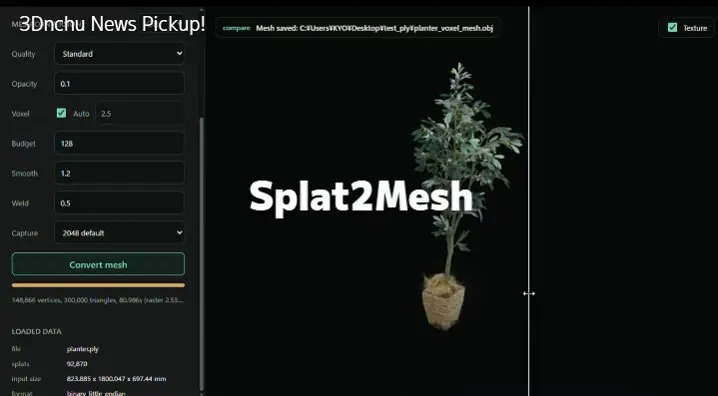
Splat2Mesh is a free Windows tool that converts 3D Gaussian Splatting data into OBJ/GLB polygon meshes, shared by Japanese developer @ymt3d and made by @ArcanaMfg.
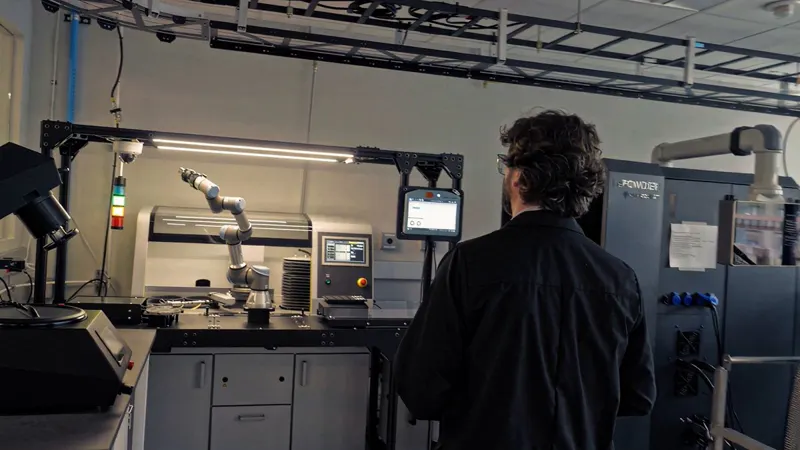
Radical AI builds self-driving materials labs that combine AI, robotics, and lab automation to accelerate closed-loop materials discovery and testing.
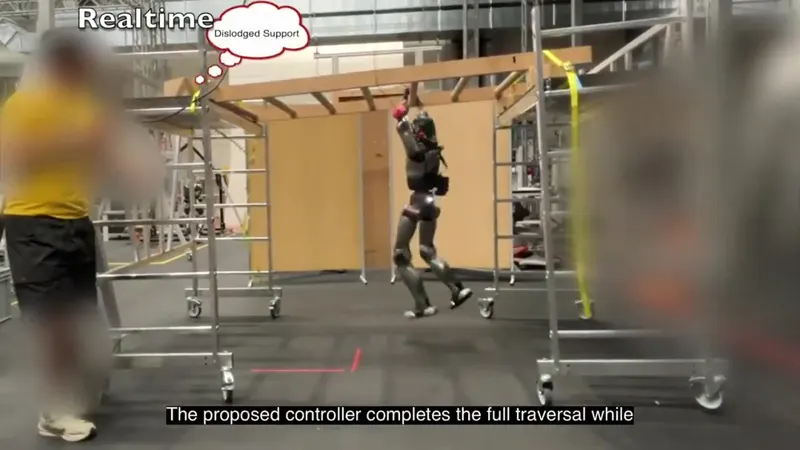
A new paper studies learning and sim2real for agile humanoid traversal of sparse 3D structures, including monkey bars and overhanging obstacles.
LightOrigins open-sources LightNav-0, a compact generalist embodied navigation model that elicits Qwen3-VL spatial intelligence. Trained entirely in simulation, it unifies instruction following, open-vocabulary object navigation and visual tracking in one model, transferring zero-shot across humanoid, quadruped, wheeled and aerial robots.
As an Amazon Associate, we earn from qualifying purchases.