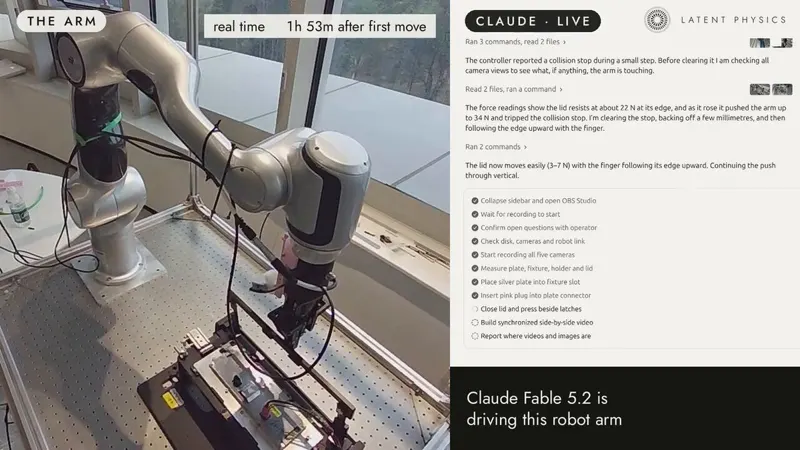
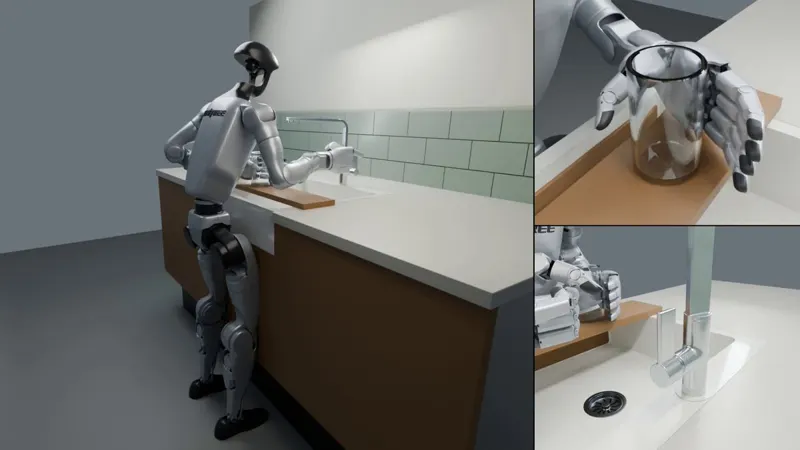
For a precision-machining task, Claude Fable 5.2 wrote and ran its own control code for a robot arm without teleoperation, demonstrations or task-specific training.
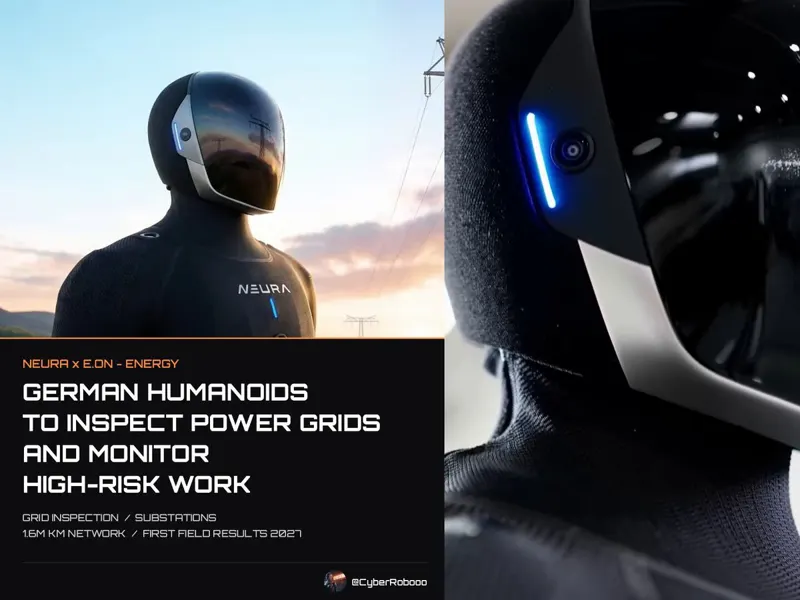
NEURA Robotics, E.ON and enviaM plan to deploy Physical AI humanoids for grid inspection and substation monitoring, with first field experience expected in 2027.
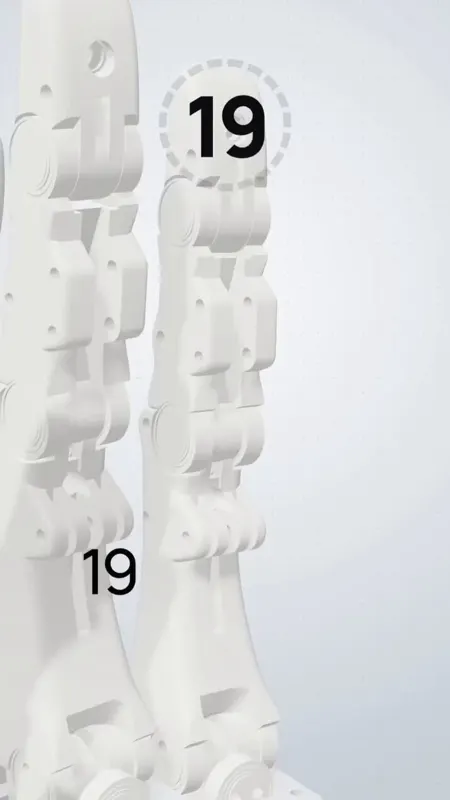
DexHand V1 from The Robot Studio is an open-source robotic hand built to explore human-like finger motion, dexterous manipulation and physical AI.
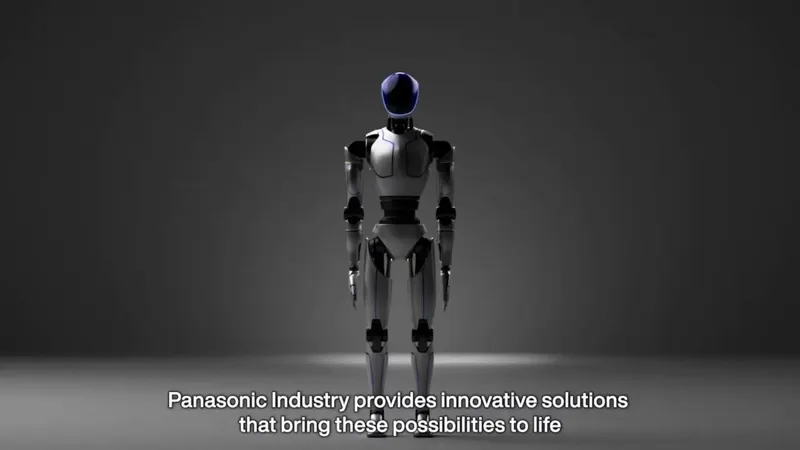
Panasonic has formed a roughly 250-person team to encode veteran manufacturing knowledge into physical AI, with factory validation planned over the next three to five years.
Eden builds on Genesis with one task definition spanning simulation and real robots; its team says coding agents create tasks 1.6 to 4 times faster than in Isaac Lab.
Ropedia’s Xperience 2 release packages a technical report, research page and dataset aimed at scaling physical AI environments and behavior data for embodied policies.
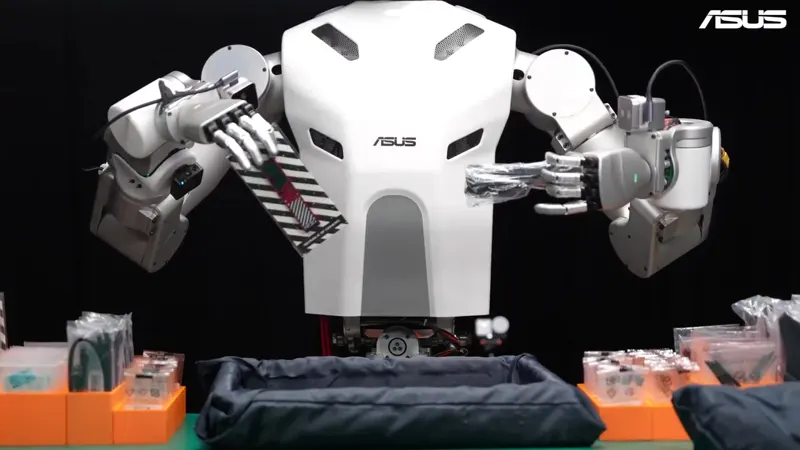
ASUS is training Gallop, its first humanoid, to pack 15 motherboard accessories in an EMS factory using worker demonstrations, simulation, and VR teleoperation. The current fixed-base, dual-arm system targets 20-second cycles at 99.5% success.
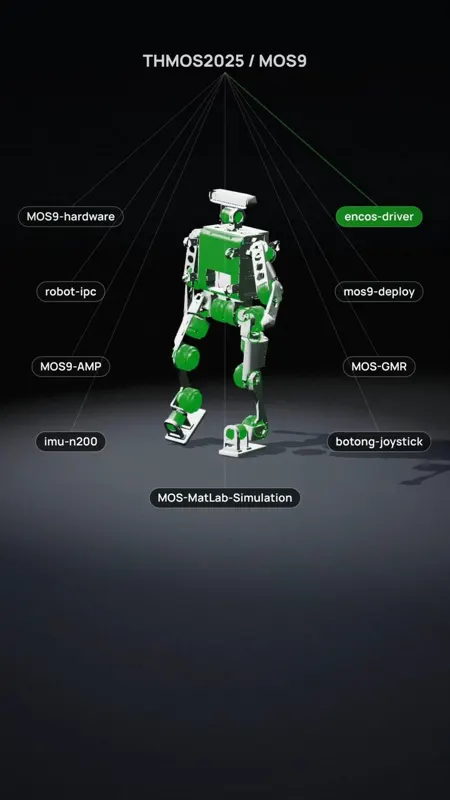
TH-MOS has open-sourced MOS-9, a humanoid built for RoboCup soccer, with hardware designs, motion control, motor drivers, and simulation tools.
Lightwheel's RoboFinals RL-Env turns real human work captured by EgoSuite into calibrated simulation tasks, starting with long-horizon, deformable automotive repair.
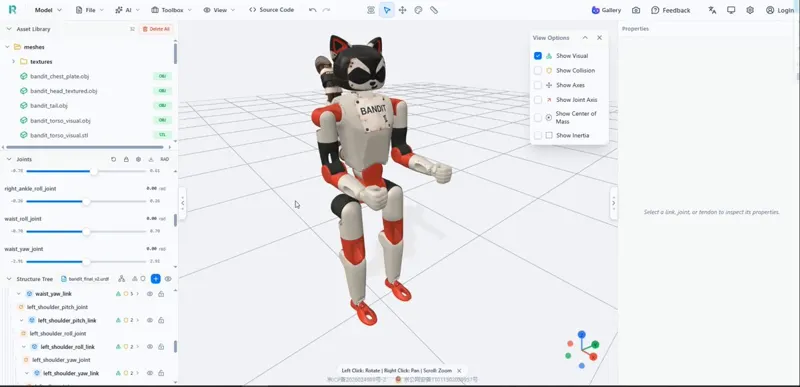
Bandit is a community-driven 24-DoF humanoid. This simulation shows joint-by-joint pose control and the open URDF workflow behind extensible motion experiments.
NVIDIA GR00T 2 learns a new robot task from five demonstrations and 30 minutes of training on a roughly ,000 GPU, combining simulation, human video, and real-robot data in one learning stack.
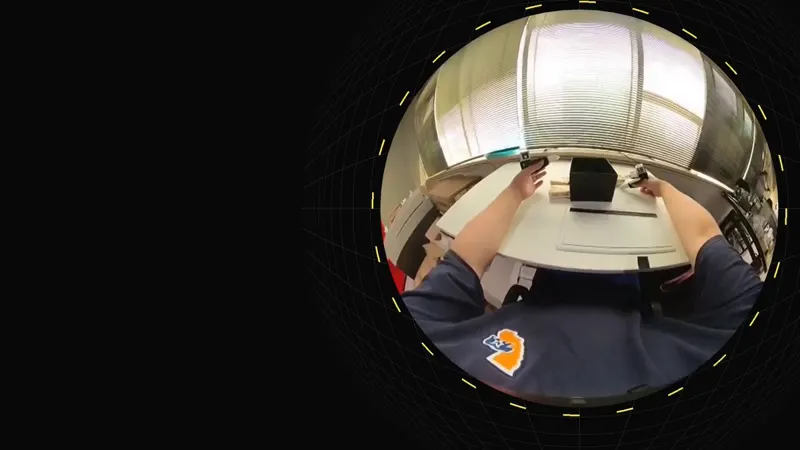
A new open data-collection system uses one fisheye camera and its wide field of view to capture manipulation across a large workspace.
As an Amazon Associate, we earn from qualifying purchases.