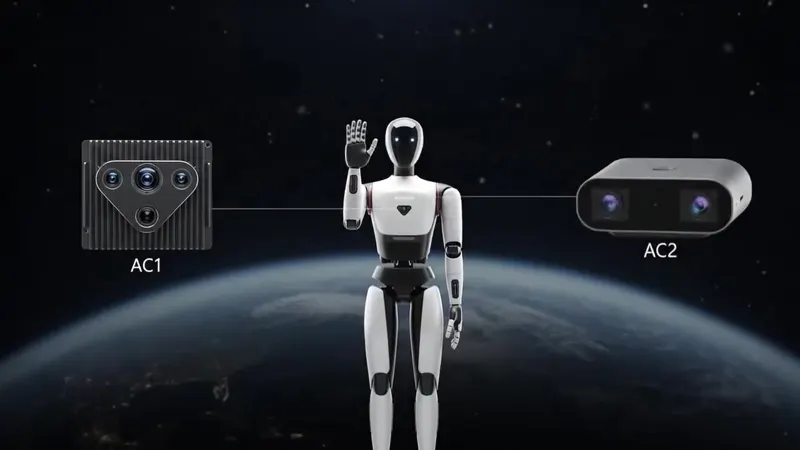
RoboSense shipped 719,200 LiDAR units in H1 2026, up 2.7x YoY, with robotics accounting for 282,600 units, a 6.1x increase
ACE-Data-0 is a large-scale synchronized multimodal dataset aligning ego and multi-view video, human/hand/object motion, audio, and tactile sensing on a unified timeline and shared coordinate system.
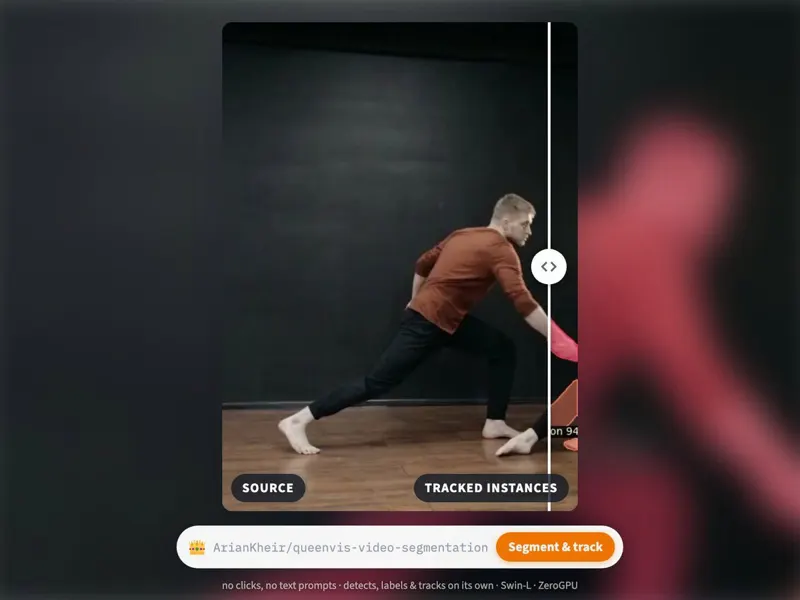
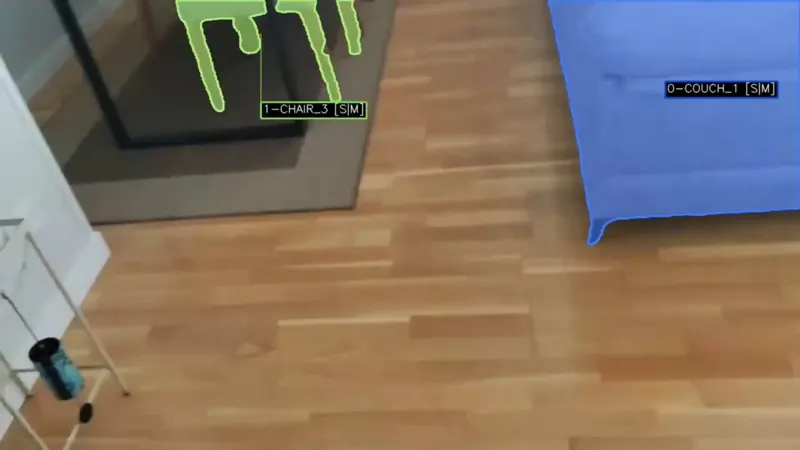
Detects, labels and tracks people and objects in raw video with no prompting needed, maintaining identities through occlusion
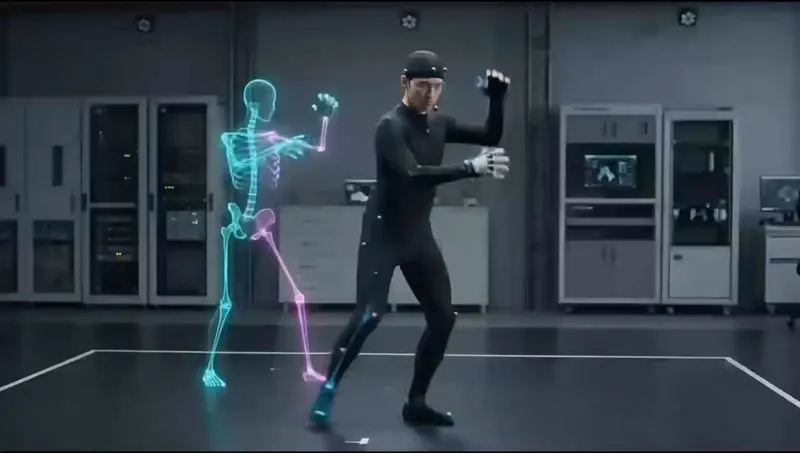
Archon Robotics achieves full self-perception on the robot itself, no motion capture cage required
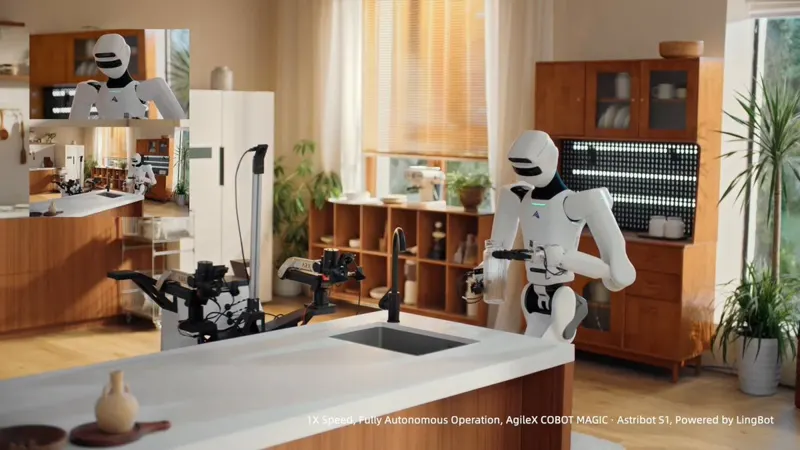
Solves transparent water perception for robots — recognizes invisible water columns in real time and performs precise autonomous water filling
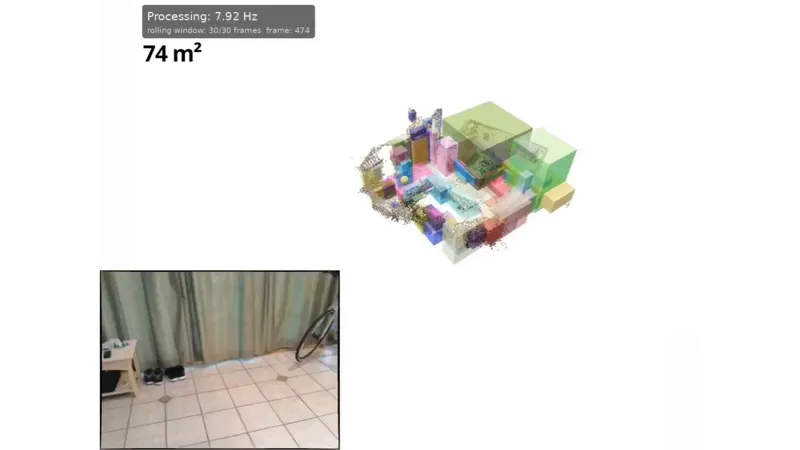
Builds structured spatial memory integrating object features and relative positions, enabling language-guided precise object search across 15,000 sqm construction sites
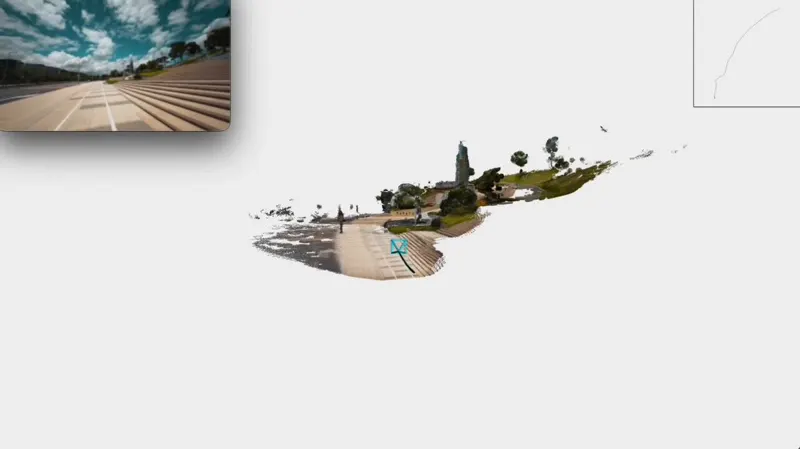
HKUST and Alibaba propose Glob3R, a scalable global 3D reconstruction framework built on geometric foundation models for large-scale SfM
A perception-aware CBF-RL framework that couples control-barrier safety with onboard sensing for whole-body humanoid dodgeball. The deployed policy sees the ball only as segmentation-masked depth from a head-mounted camera, with CBF guidance representing clearance to every body link. Deployed zero-shot on Unitree G1, achieving 95% success rate on real-world throws.
Lizhi Yang, Junheng Li, Aaron D. Ames
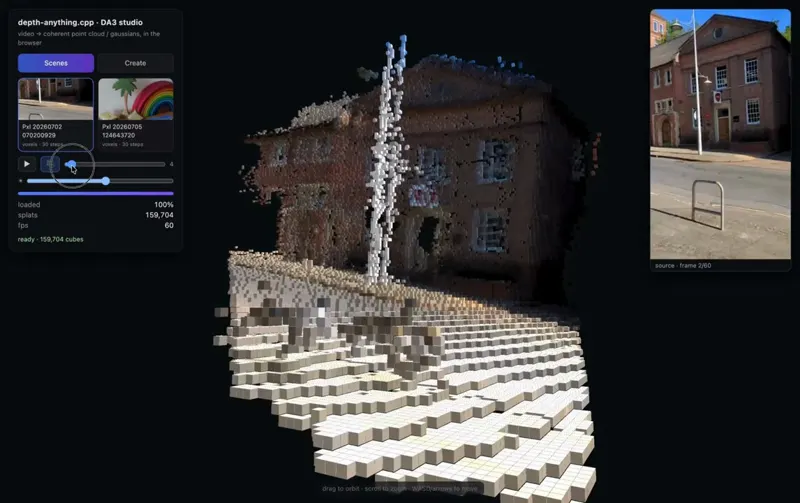
Open-source tool turns phone video into a fully walkable 3D world with 996K points at 60 FPS, no cloud or subscription needed
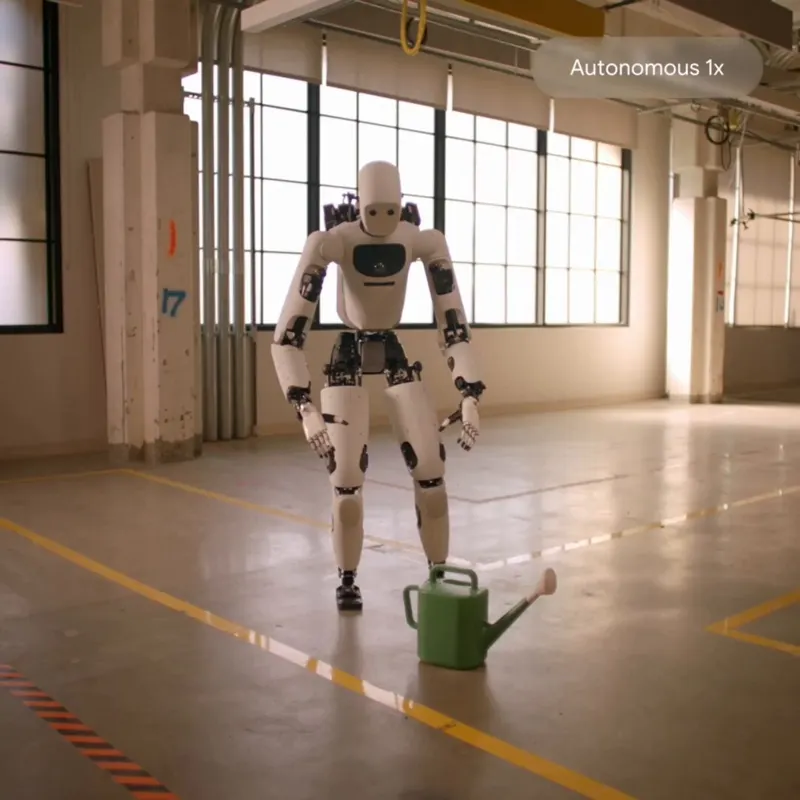
Gemini Robotics 2 moves physical AI beyond tabletop tasks, enabling intelligent whole-body control for humanoids. Apptronik Apollo 2 processes a single prompt to reach, bend, and pick up a watering can.
REMIND tackles re-identifying objects that disappear and reappear, look similar, or are observed from changing viewpoints, for indoor navigation.
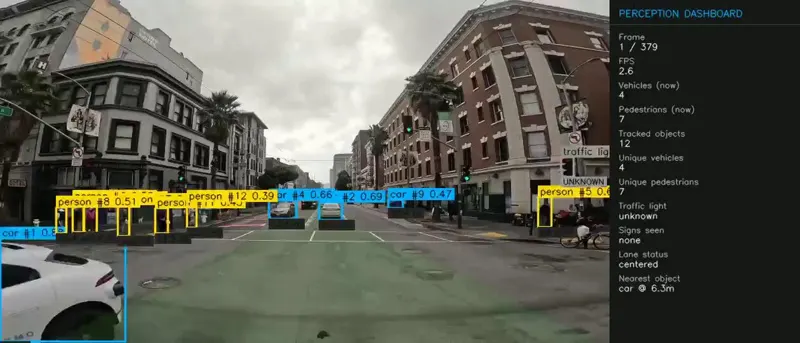
Monocular-camera-only perception system integrating YOLOv8, ByteTrack, MiDaS for detection, tracking, lane recognition, distance estimation, and collision warning. Open-sourced on GitHub.