Skip to content
Global-Local Attention Decomposition for Terrain Encoding in Humanoid Perceptive Locomotion

Global-Local Attention Decomposition for Terrain Encoding in Humanoid Perceptive Locomotion

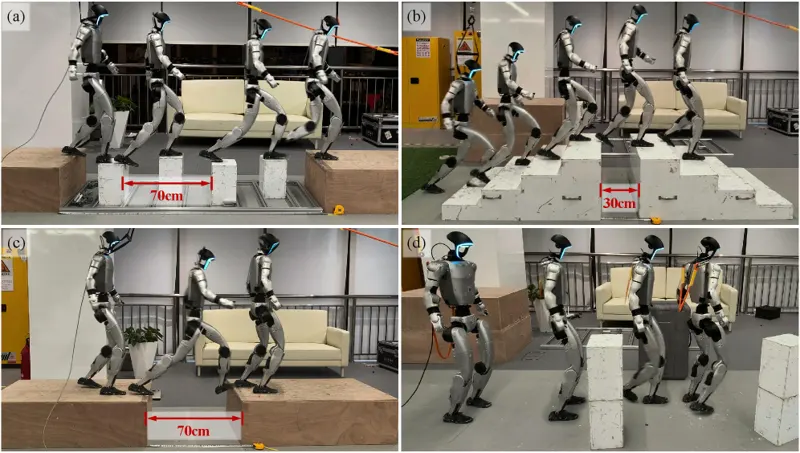
Although reinforcement learning has significantly advanced humanoid locomotion, perceptive policies still struggle on sparse-foothold terrain and constrained environments. Success in these scenarios requires both broad terrain awareness and precise foothold selection, two perceptual roles that conventional encoders often entangle. To address this challenge, we propose Global-Local Attention Decomposition (GLAD) for terrain encoding in humanoid locomotion. Realized by a coarse-to-fine encoder over a robot-centric elevation map, GLAD explicitly separates these objectives: a global attention branch utilizes attention pooling to summarize the surrounding terrain context, while a state-conditioned local attention branch sparsifies and encodes precise foothold-relevant geometry. This explicit attention decomposition prevents the dilution of fine-grained spatial cues while reducing training overhead. Experiments demonstrate that GLAD enables reliable locomotion over challenging gaps, stepping stones, and stairs. Furthermore, the learned policy exhibits emergent terrain-responsive behaviors, autonomously following narrow paths and avoiding obstacles under simple velocity commands without explicit navigation planners. In real-world deployment on a Unitree G1 humanoid robot using onboard LiDAR, the proposed method achieves robust zero-shot sim-to-real transfer across diverse sparse-foothold and obstacle-rich domains.

HumanoidAttention Mechanism
Shengcheng Fu, Yang Zhang, Zhanxiang Cao · 451 views · May 30, 2026
Learning Whole-Body Humanoid Locomotion via Motion Generation and Motion Tracking

Learning Whole-Body Humanoid Locomotion via Motion Generation and Motion Tracking

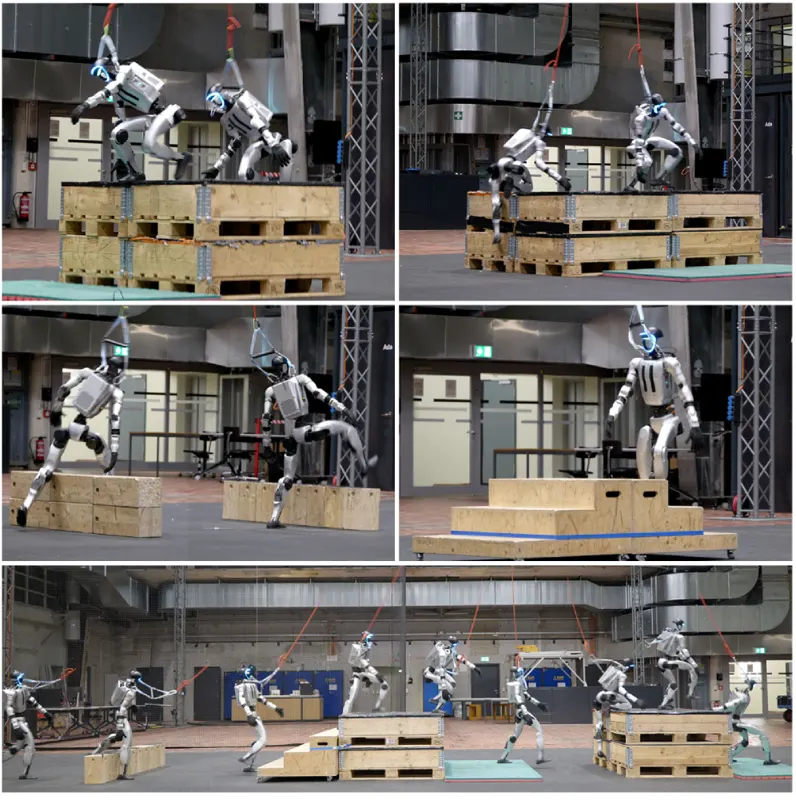
Whole-body humanoid locomotion is challenging due to high-dimensional control, morphological instability, and the need for real-time adaptation to various terrains using onboard perception. Directly applying reinforcement learning (RL) with reward shaping to humanoid locomotion often leads to lower-body-dominated behaviors, whereas imitation-based RL can learn more coordinated whole-body skills but is typically limited to replaying reference motions without a mechanism to adapt them online from perception for terrain-aware locomotion. To address this gap, we propose a whole-body humanoid locomotion framework that combines skills learned from reference motions with terrain-aware adaptation. We first train a diffusion model on retargeted human motions for real-time prediction of terrain-aware reference motions. Concurrently, we train a whole-body reference tracker with RL using this motion data. To improve robustness under imperfectly generated references, we further fine-tune the tracker with a frozen motion generator in a closed-loop setting. The resulting system supports directional goal-reaching control with terrain-aware whole-body adaptation, and can be deployed on a Unitree G1 humanoid robot with onboard perception and computation. The hardware experiments demonstrate successful traversal over boxes, hurdles, stairs, and mixed terrain combinations. Quantitative results further show the benefits of incorporating online motion generation and fine-tuning the motion tracker for improved generalization and robustness.

HumanoidWhole-body locomotion
Zewei Zhang, Kehan Wen, Michael Xu · 471 views · Apr 19, 2026
Learning Humanoid Locomotion with Perceptive Internal Model

Learning Humanoid Locomotion with Perceptive Internal Model

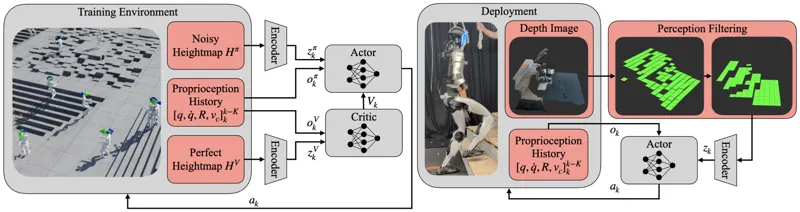
In contrast to quadruped robots that can navigate diverse terrains using a "blind" policy, humanoid robots require accurate perception for stable locomotion due to their high degrees of freedom and inherently unstable morphology. However, incorporating perceptual signals often introduces additional disturbances to the system, potentially reducing its robustness, generalizability, and efficiency. This paper presents the Perceptive Internal Model (PIM), which relies on onboard, continuously updated elevation maps centered around the robot to perceive its surroundings. We train the policy using ground-truth obstacle heights surrounding the robot in simulation, optimizing it based on the Hybrid Internal Model (HIM), and perform inference with heights sampled from the constructed elevation map. Unlike previous methods that directly encode depth maps or raw point clouds, our approach allows the robot to perceive the terrain beneath its feet clearly and is less affected by camera movement or noise. Furthermore, since depth map rendering is not required in simulation, our method introduces minimal additional computational costs and can train the policy in 3 hours on an RTX 4090 GPU. We verify the effectiveness of our method across various humanoid robots, various indoor and outdoor terrains, stairs, and various sensor configurations. Our method can enable a humanoid robot to continuously climb stairs and has the potential to serve as a foundational algorithm for the development of future humanoid control methods.

HumanoidInternal Perception Model
Junfeng Long, Junli Ren, Moji Shi · 450 views · Nov 21, 2024
PRIOR: Perceptive Learning for Humanoid Locomotion with Reference Gait Priors

PRIOR: Perceptive Learning for Humanoid Locomotion with Reference Gait Priors

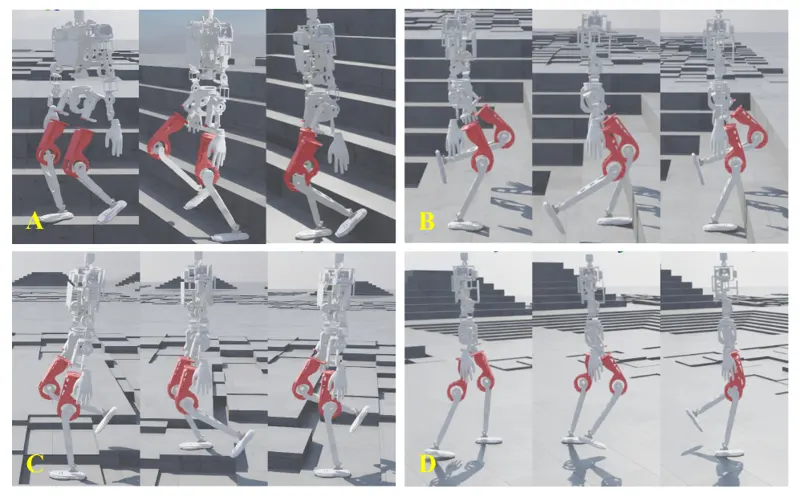
Training perceptive humanoid locomotion policies that traverse complex terrains with natural gaits remains an open challenge, typically demanding multi-stage training pipelines, adversarial objectives, or extensive real-world calibration. We present PRIOR, an efficient and reproducible framework built on Isaac Lab that achieves robust terrain traversal with human-like gaits through a simple yet effective design: (i) a parametric gait generator that supplies stable reference trajectories derived from motion capture without adversarial training, (ii) a GRU-based state estimator that infers terrain geometry directly from egocentric depth images via self-supervised heightmap reconstruction, and (iii) terrain-adaptive footstep rewards that guide foot placement toward traversable regions. Through systematic analysis of depth image resolution trade-offs, we identify configurations that maximize terrain fidelity under real-time constraints, substantially reducing perceptual overhead without degrading traversal performance. Comprehensive experiments across terrains of varying difficulty-including stairs, boxes, and gaps-demonstrate that each component yields complementary and essential performance gains, with the full framework achieving a 100% traversal success rate. We will open-source the complete PRIOR framework, including the training pipeline, parametric gait generator, and evaluation benchmarks, to serve as a reproducible foundation for humanoid locomotion research on Isaac Lab.

Isaac LabHumanoid
Chenxi Han, Shilu He, Yi Cheng · 407 views · Mar 19, 2026
Omnidirectional Humanoid Locomotion on Stairs via Unsafe Stepping Penalty and Sparse LiDAR Elevation Mapping

Omnidirectional Humanoid Locomotion on Stairs via Unsafe Stepping Penalty and Sparse LiDAR Elevation Mapping

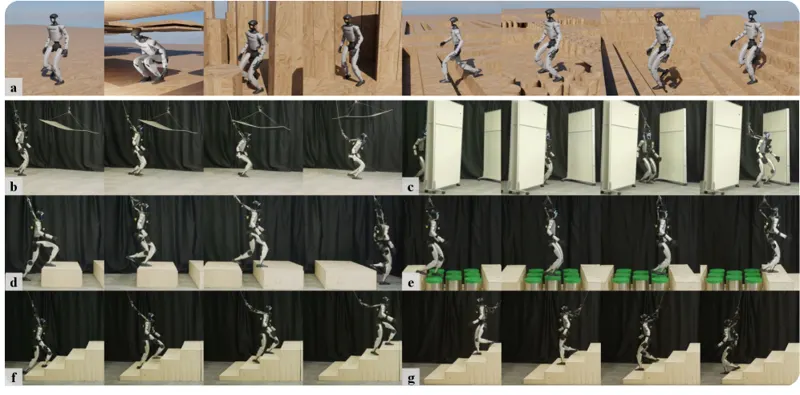
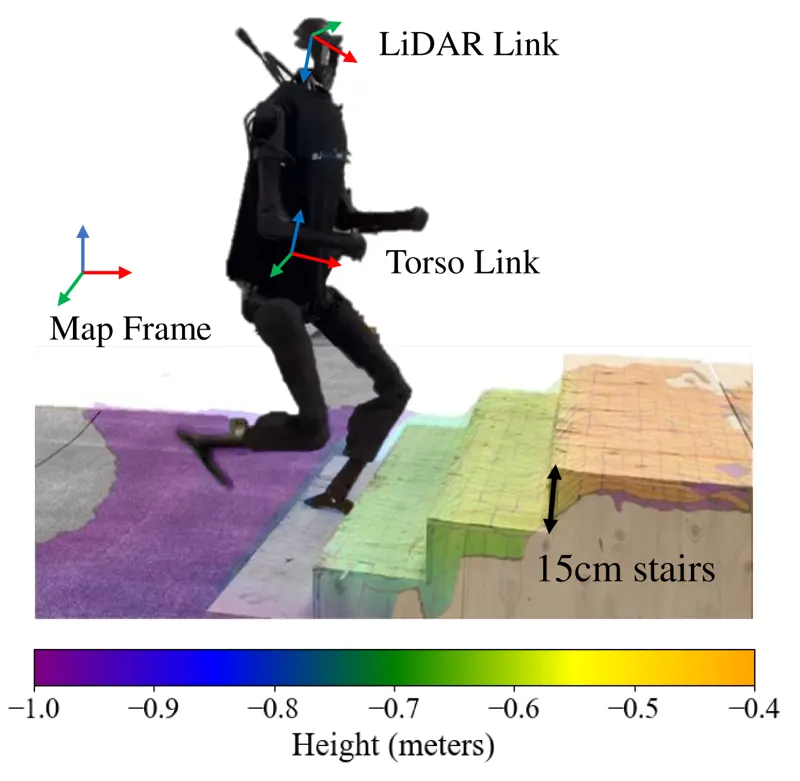
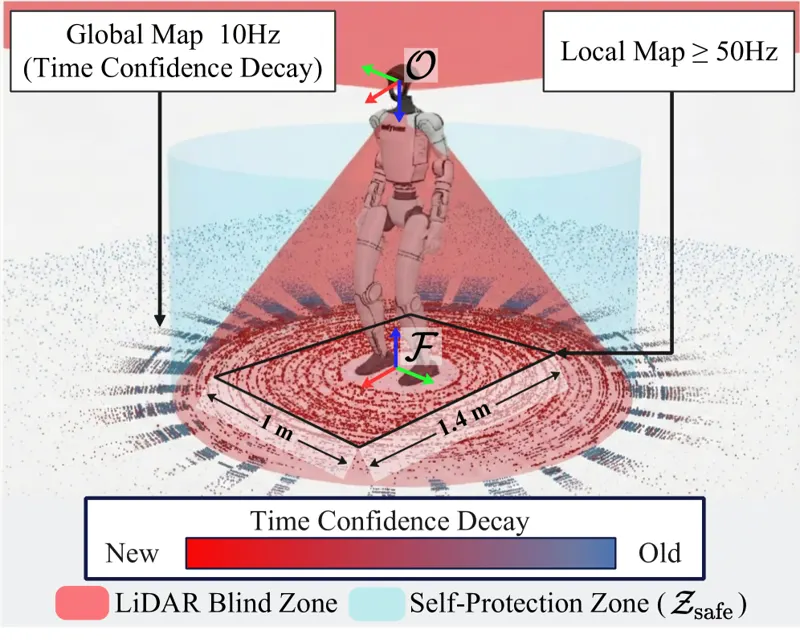
Humanoid robots, characterized by numerous degrees of freedom and a high center of gravity, are inherently unstable. Safe omnidirectional locomotion on stairs requires both omnidirectional terrain perception and reliable foothold selection. Existing methods often rely on forward-facing depth cameras, which create blind zones that restrict omnidirectional mobility. Furthermore, sparse post-contact unsafe stepping penalties lead to low learning efficiency and suboptimal strategies. To realize safe stair-traversal gaits, this paper introduces a single-stage training framework incorporating a dense unsafe stepping penalty that provides continuous feedback as the foot approaches a hazardous placement. To obtain stable and reliable elevation maps, we build a rolling point-cloud mapping system with spatiotemporal confidence decay and a self-protection zone mechanism, producing temporally consistent local maps. These maps are further refined by an Edge-Guided Asymmetric U-Net (EGAU), which mitigates reconstruction distortion caused by sparse LiDAR returns on stair risers. Simulation and real-robot experiments show that the proposed method achieves a near-100% safe stepping rate on stair terrains in simulation, while maintaining a remarkably high safe stepping rate in real-world deployments. Furthermore, it completes a continuous long-distance walking test on complex outdoor terrains, demonstrating reliable sim-to-real transfer and long-term stability.

LiDARHumanoid
Yuzhi Jiang, Yujun Liang, Junhao Li · 456 views · Mar 9, 2026

As an Amazon Associate, we earn from qualifying purchases.