T-WLA: Bridging Slow Vision and Fast Touch
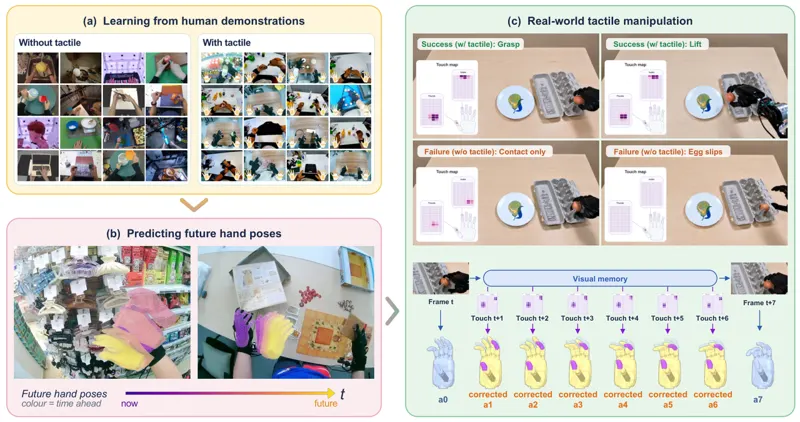
T-WLA shares a history-aware visual memory between a slow vision-language-action policy and a fast tactile residual editor. The visual branch produces an action chunk and memory at 39.7 Hz; the lightweight tactile editor reuses them to correct only unexecuted actions at 119.1 Hz. It improves tactile-conditioned hand-motion prediction and contact-rich manipulation, reaching 50.0% average success on four real-robot tasks with 30 demonstrations each.
Kaichen Zhou, Yuzhen Chen, Hannah Yao · 22 views · Oct 20, 2026
Tactile SensingVisuotactile Manipulation
Oct 20, 2026