HITTER: A HumanoId Table TEnnis Robot via Hierarchical Planning and Learning
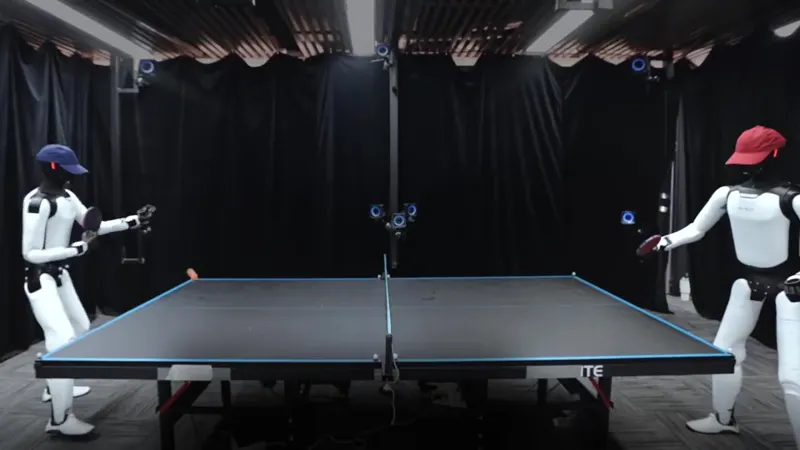
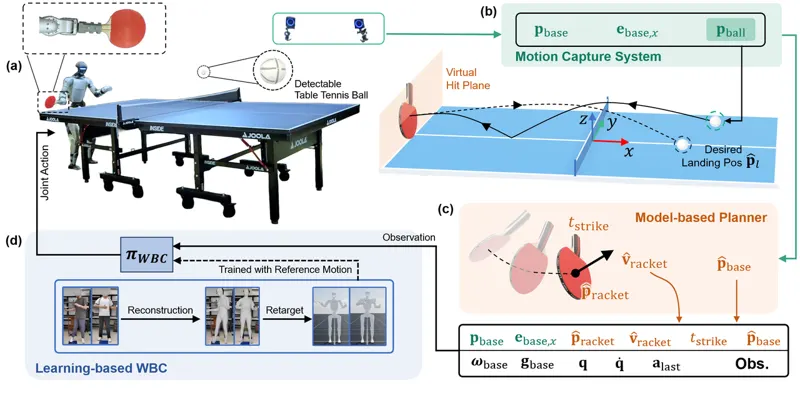
HITTER couples a model-based planner (ball trajectory prediction, strike position/velocity/timing) with an RL whole-body controller trained on human forehand/backhand motion references, enabling a Unitree G1 to sustain rallies of up to 106 consecutive shots against a human opponent.
Zhi Su, Bike Zhang, Nima RahmanianAug 28, 2025
HumanoidTable TennisWhole-Body ControlAug 28, 2025