0:19RL2-VLA: adaptive RL compositional steering framework@derektan1995 · 407 views · 2026-08-05VLARL²-VLA
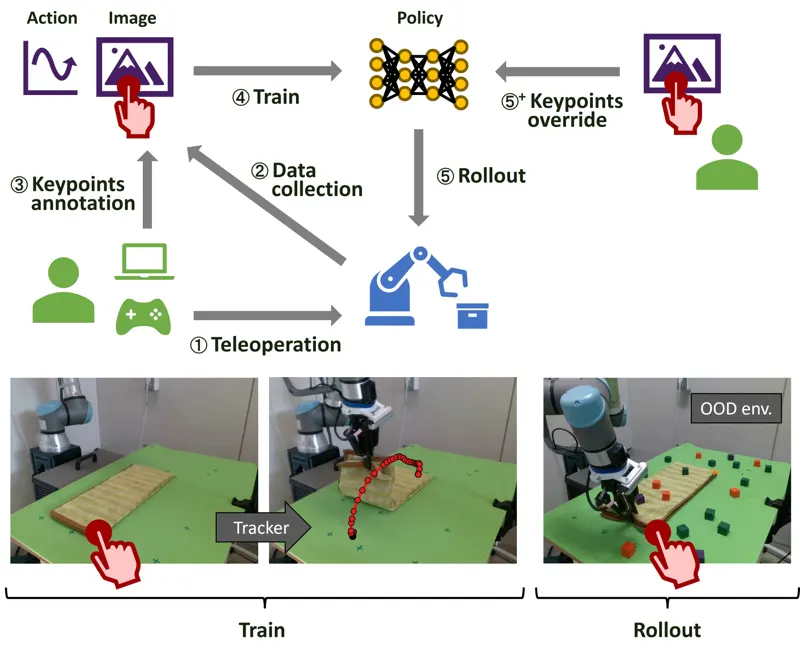
GuidedAttention: Interpretable and Correctable Visual Attention for OOD-Robust Robot Manipulation via Imitation LearningEnd-to-end visuomotor policies provide little opportunity for humans to understand or correct the policy's visual attention. We propose GuidedAttention, a visuomotor imitation learning framework that introduces interpretable and correctable visual attention as an explicit intermediate representation. Task-relevant attention keypoints are predicted from camera images and condition a diffusion-based action policy. Users can inspect and optionally correct selected keypoints once at rollout initialization, after which the corrected attention is automatically propagated throughout execution by a tracking module. Experiments in simulation and the real world demonstrate that GuidedAttention consistently improves robot manipulation performance, particularly under positional and appearance out-of-distribution (OOD) conditions.Masaki Murooka, Ryoichi Nakajo, Keisuke Shirai · 387 views · Jul 23, 2026OODImitation LearningJul 23, 2026

 0:19