
A Unified Inertial Encoder for Human and Humanoid Motion
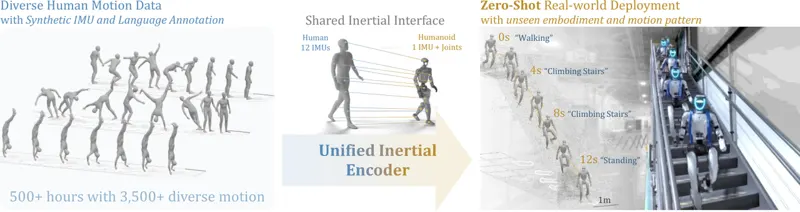
A shared kinematic-IMU interface jointly learns velocity estimation and motion-text alignment from human and retargeted humanoid motion, enabling zero-shot Unitree G1 deployment without robot-specific training.
Yutian Chen, Shibo Zhao, Rocky Duan · 19 views · Nov 6, 2026
Inertial OdometryHumanoid robots
Nov 6, 2026