Humanoid Robot Co-Design: Coupling Hardware Design with Gait Generation via Hybrid Zero Dynamics
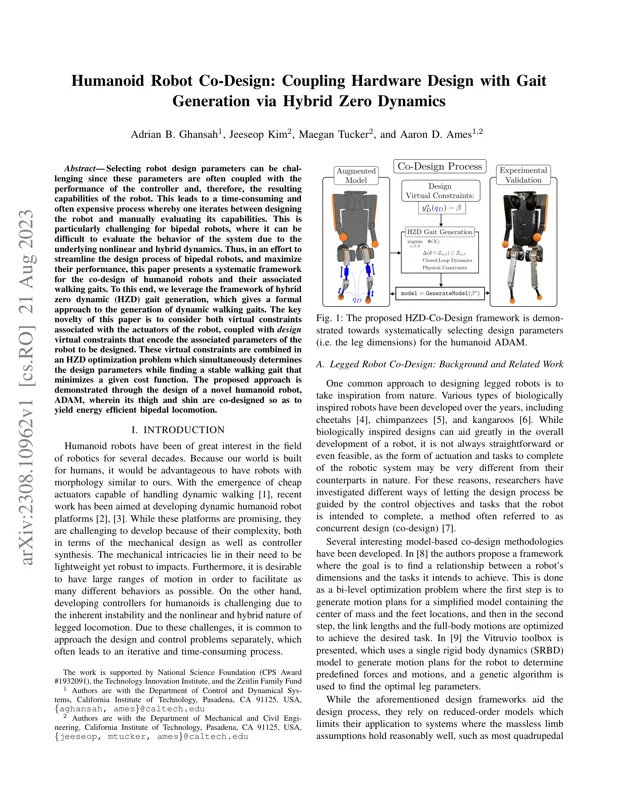
Presents a systematic co-design framework for humanoid robots using hybrid zero dynamics (HZD) gait generation, coupling actuator virtual constraints with design virtual constraints to jointly optimize robot design parameters and walking gaits. Demonstrated on the ADAM humanoid robot with co-designed thigh and shin for energy-efficient bipedal locomotion.
Adrian B. Ghansah, Jeeseop Kim, Maegan TuckerAug 21, 2023
HZDAdamHumanoidAug 21, 2023