Humanoid Mobility via Attention-based Contacts
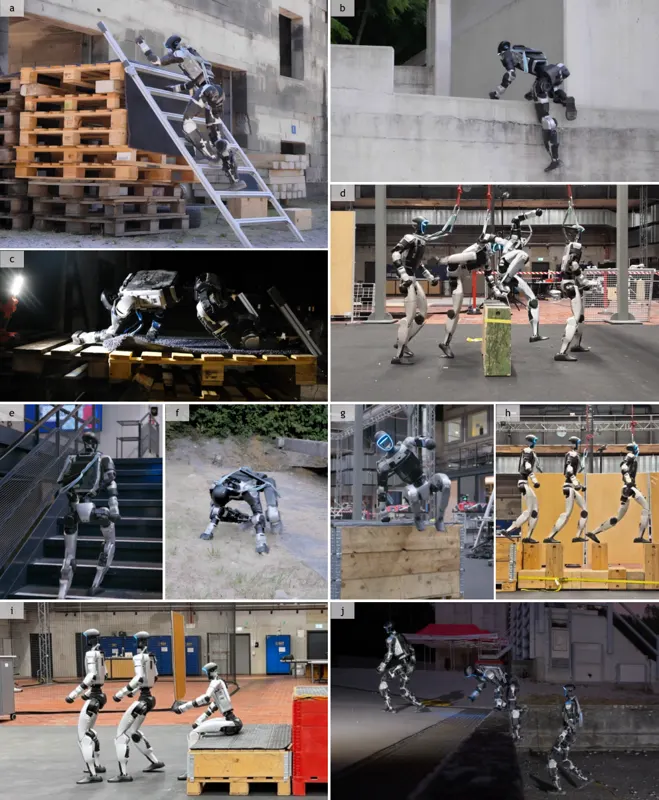
Humanoid mobility over complex terrain requires accurate foot placement and coordinated whole-body motion capable of robust adaptation. Reinforcement learning (RL) policies trained without motion references generalize well across terrains, yet eliciting effective whole-body coordination through reward design and exploration alone remains challenging. In contrast, reference-based methods yield natural motions but struggle to adapt beyond the predefined trajectories in their training data. We introduce a learning framework that bridges these two approaches by using motion data strictly as a training prior. An explicit, self-supervised, attention-based contact planner predicts future body-environment contacts, while a contact-conditioned tracker translates these plans into coordinated whole-body motion. Together, they establish contact as an interface between sensory observations and control actions. This abstraction allows the policy to internalize the contact-aware structure of locomotion rather than directly replicating kinematics. Consequently, a single policy can exploit data-driven motion priors for natural whole-body coordination while retaining the flexibility to discover environment-dependent behaviors through reinforcement learning. Building on the learned contact planner and tracker, a subsequent fine-tuning stage bootstraps their acquired capabilities to explore environment variations beyond those covered by the original motion data. Operating entirely from onboard observations without any reference inputs at deployment, this framework enables versatile humanoid mobility in challenging environments.