
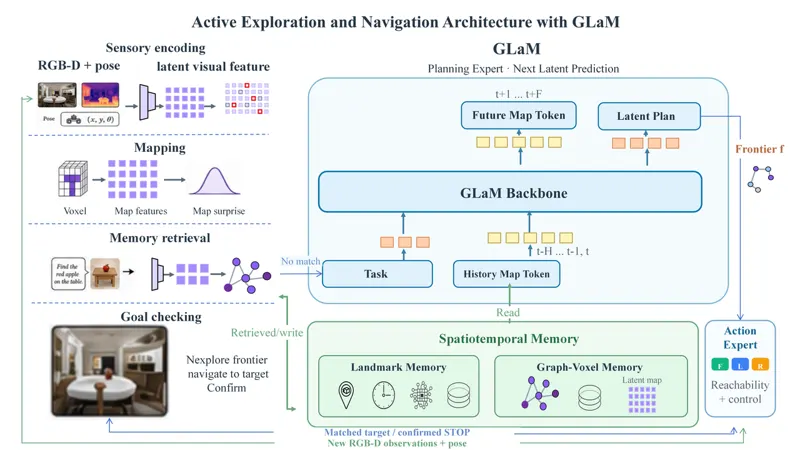
GLaM: Training a Latent World Model over Global Spatiotemporal Memory for Active Exploration and Navigation
GLaM is a goal-conditioned latent world model over an online spatiotemporal map that jointly predicts future map representations and robot-centric waypoint latents, with GLaM Nav adding observation-based verification, retrieval, and geometric control. On a controlled 50% HM3D-ObjectNav subset, it raises success rate from 78.50% to 86.89% and SPL from 47.70% to 48.35%; qualitative Astribot S1 demonstrations cover exploration and memory-based return in an unknown office.
I-Tak Ieong, Ruizhi Feng, Zhaoyang Lu · 28 views · Sep 13, 2026
Embodied AIObject Navigation
Sep 13, 2026