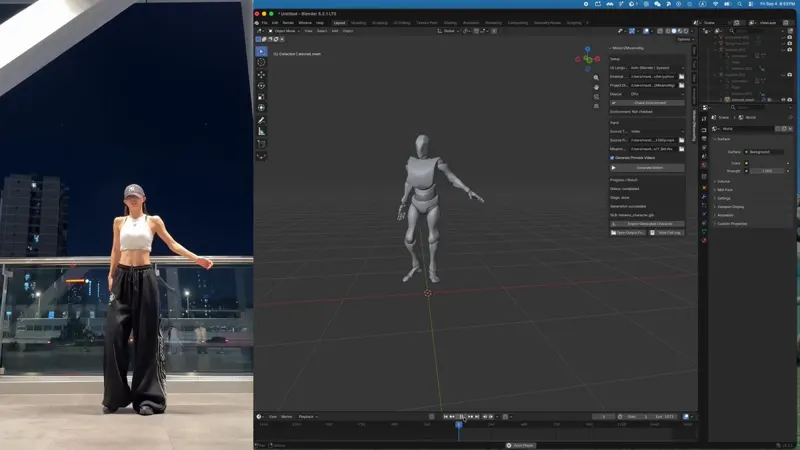
0:26Motion2MixamoRig Retargets Video Motion onto a Mixamo Character@renmu2017 · 292 views · 2026-10-12Motion CaptureMixamo
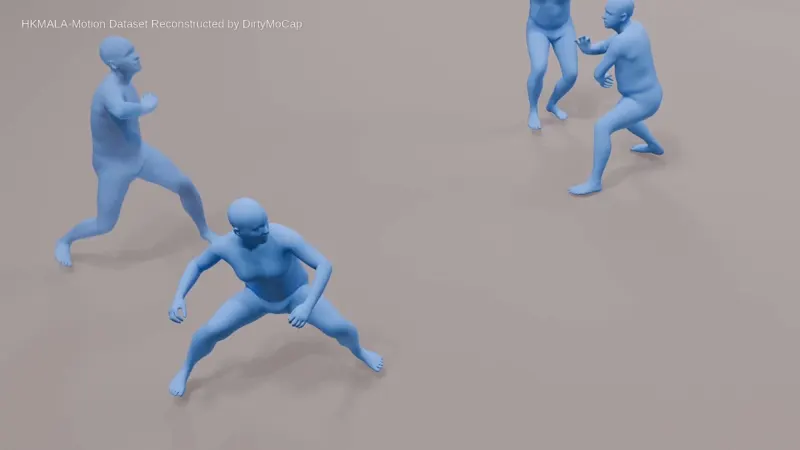
0:23DirtyMoCap: Robust Motion Capture from Noisy, Unconstrained Markers@yuliangxiu · 284 views · 2026-10-11Motion CaptureDirtyMoCap
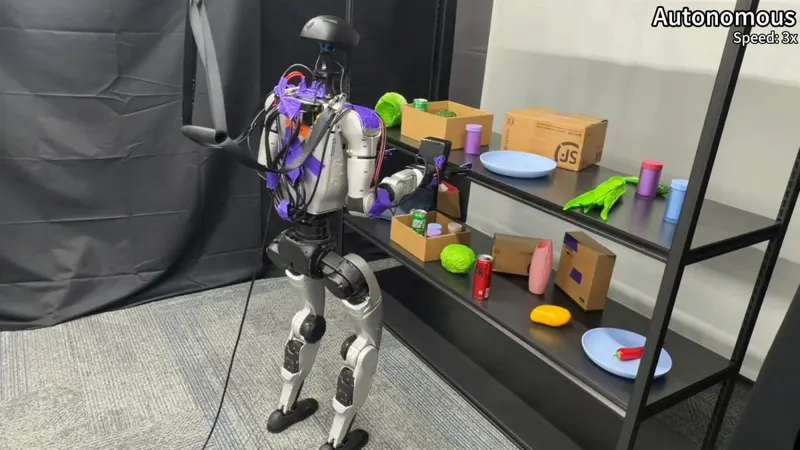
2:28Whole-Body UMI: Humanoid Whole-Body Manipulation from UMI Data@ZhongyuLi4 · 404 views · 2026-10-10HumanoidWhole-Body Control
1:40DexWeave: Learning Dexterous Humanoid Loco-Manipulation from Human Demonstrations@ErenChenAI · 312 views · 2026-10-09Mobile ManipulationHumanoid
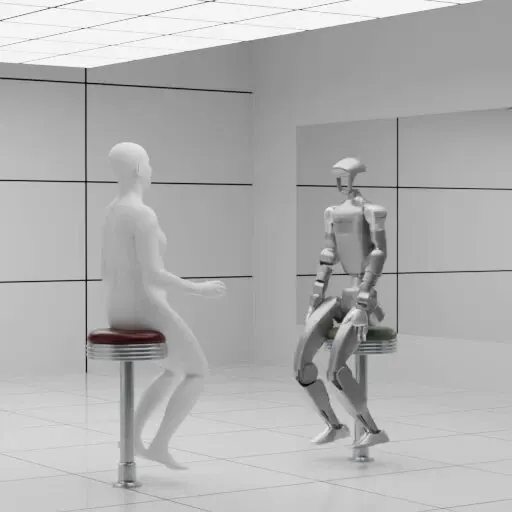
0:42DyaPlex: Full-Duplex Human-Robot Interaction at NeurIPS 2026@luminohope · 472 views · 2026-10-07Human-robot interactionNeurIPS
0:37COSMI: Compositional Human-Object Interaction Dataset and Diffusion Model@GerardPonsMoll1 · 374 views · 2026-10-07Human-Object InteractionDiffusion Transformer
0:25DynaRetarget: Learning Humanoid Robot Motions from Human Demonstrations@spaceandtech_ · 671 views · 2026-10-02HumanoidMotion retargeting
3:28CLONE: whole-body humanoid teleoperation from a single MR headset — closed-loop correction plus MoE tracking keeps 5.1cm error over 8.9m, built for long-horizon data collection@robotsdigest · 596 views · 2026-10-01HumanoidTeleoperation
0:14Clone shows VR teleoperation of Torso 3''s hand — open/close, point and pinch tracked in real time; after six months rebuilding everything, Torso 4 lands in early November with zero gears anywhere@CyberRobooo · 505 views · 2026-10-02HumanoidMusculoskeletal
0:50Google Vids opens free AI video creation: Veo 3.1 clips, AI avatars, voiceover, music and subtitle styles with just a Google account@Lonely__MH · 672 views · 2026-10-01Voice InteractionGoogle Vids
LuxTTS: small-and-fast open voice cloning — 150x realtime on one GPU, native 48 kHz, 1 GB VRAM, fully local@bkdgiffug · 684 viewsVoice InteractionTTS
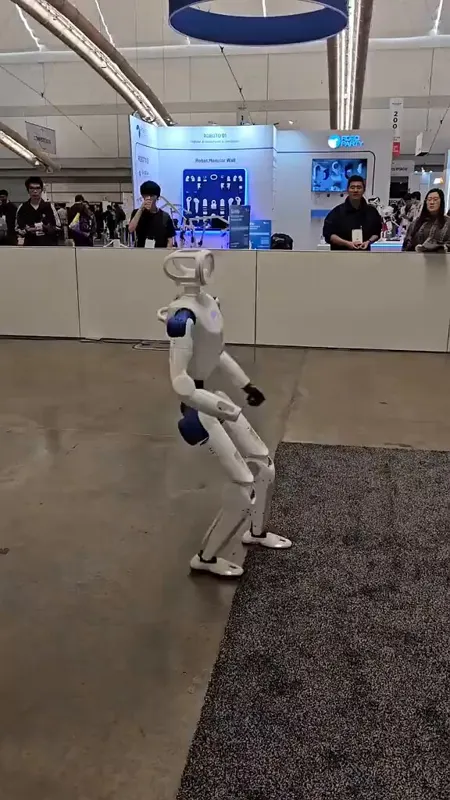
2:03RoboParty ROBOTO_ORIGIN: the second fully open-source humanoid shown at IROS — Taobao parts + JLCPCB prototyping, all structure/training/deployment code public@clankrmedia · 714 views · 2026-09-30HumanoidOpen-source hardware

 0:26