DirtyMoCap: Robust Motion Capture from Noisy, Unconstrained Markers
Loading video
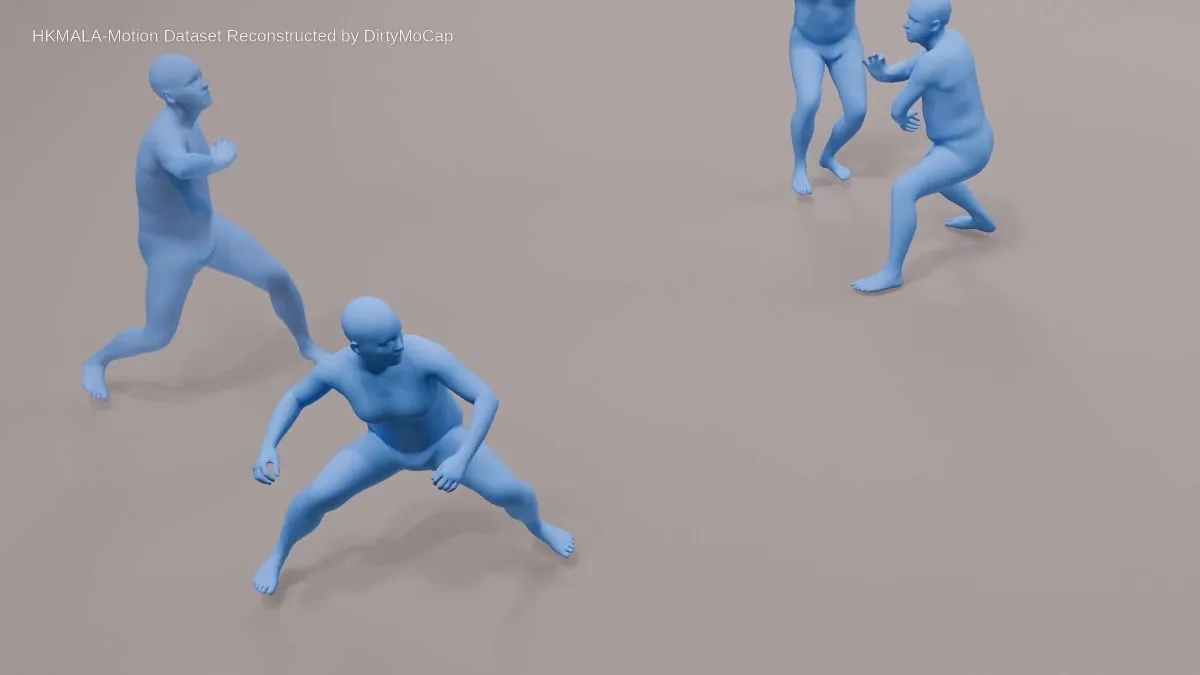
Loading videoOptical motion capture usually demands strict marker layouts and clean trajectories. DirtyMoCap is marker-layout-free: it maps unordered, sparse and noisy marker observations onto a fixed set of proxy anchors, skeletal joints plus body surface points, tracks them over long sequences with a recurrent sliding-window architecture, then fits SMPL-H using a custom differentiable Gauss-Newton solver. It ships HKMALA-Motion, 134 Kung Fu sequences across 22 styles totalling about 3 hours.
Motion CaptureDirtyMoCapSMPL-HPose estimationMarker CloudHKMALA-MotionSIGGRAPH Asia 2026Human PostureDatasets
Category: perception
Author: @yuliangxiu
Date: 2026-10-11T00:00:00
Duration: 22.6s
Reference: https://arxiv.org/abs/2609.19927