ORCS: Perceptive Whole-Body Robot Locomotion
Loading video
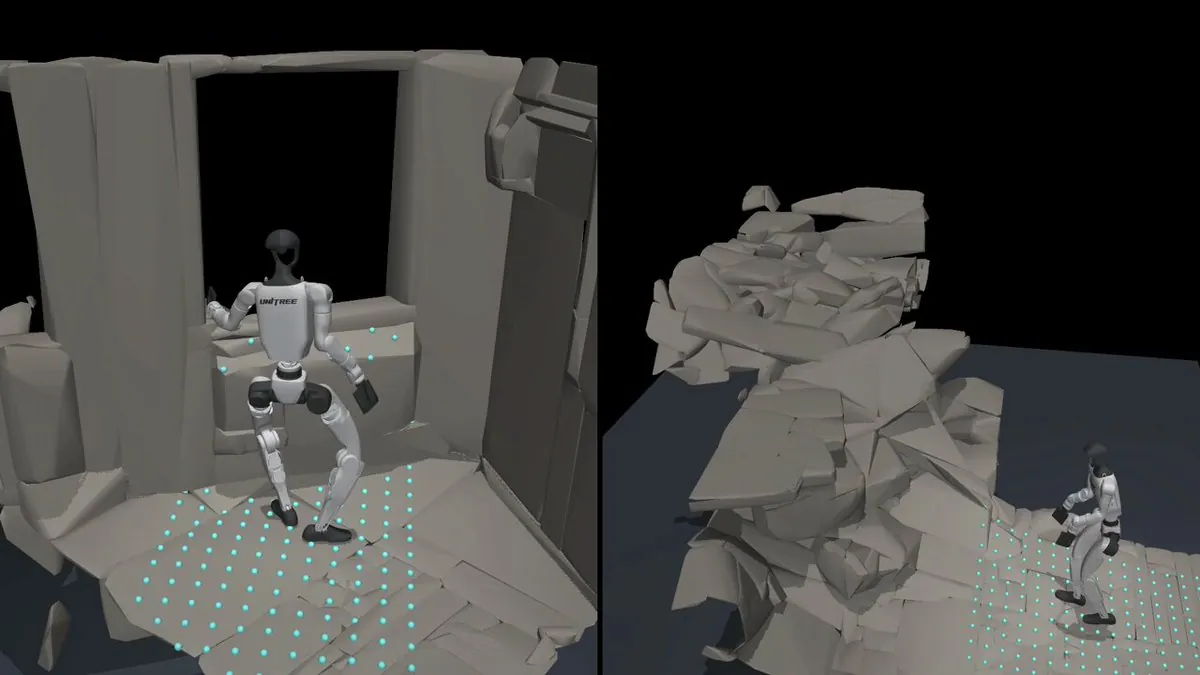
Loading videoORCS v0.1.1 adapts one perceptive whole-body locomotion policy for rocky climbs and window crossing on EgoHTR, with agentic UMR retargeting that revises references from frame-wise notes.
ORCSPerceptive LocomotionWhole-Body ControlMotion retargetingHumanoid robotsFull-body Motion Control
Category: research
Author: @lok_s_h
Date: 2026-10-30T00:00:00
Duration: 9.98s
Reference: https://github.com/lok-i/orcs