RoboJEPA: The First Scaling Law for Multi-Embodiment World Models
Loading video
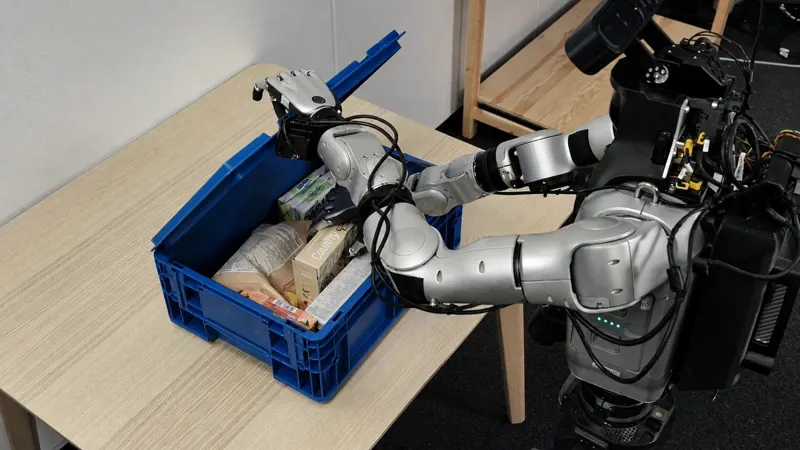
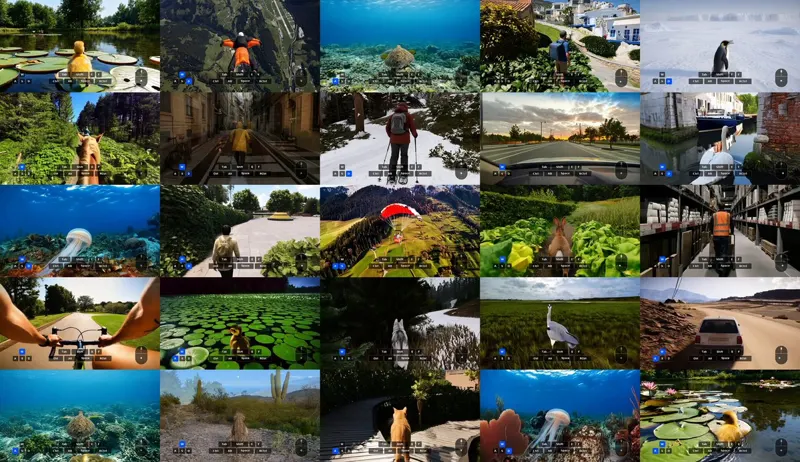
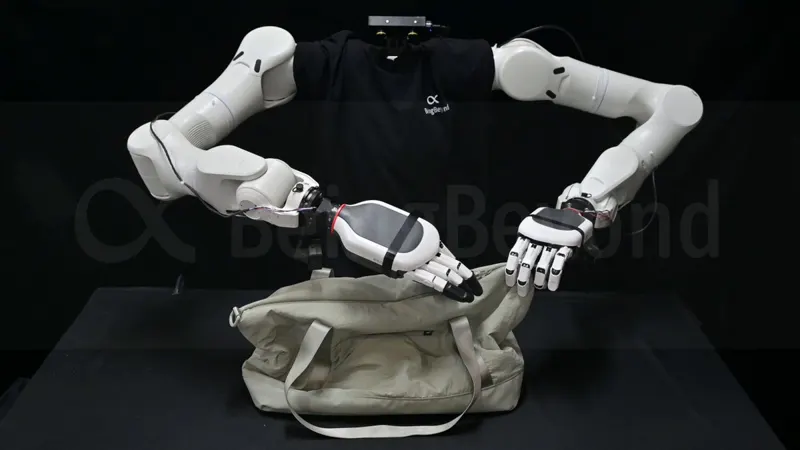
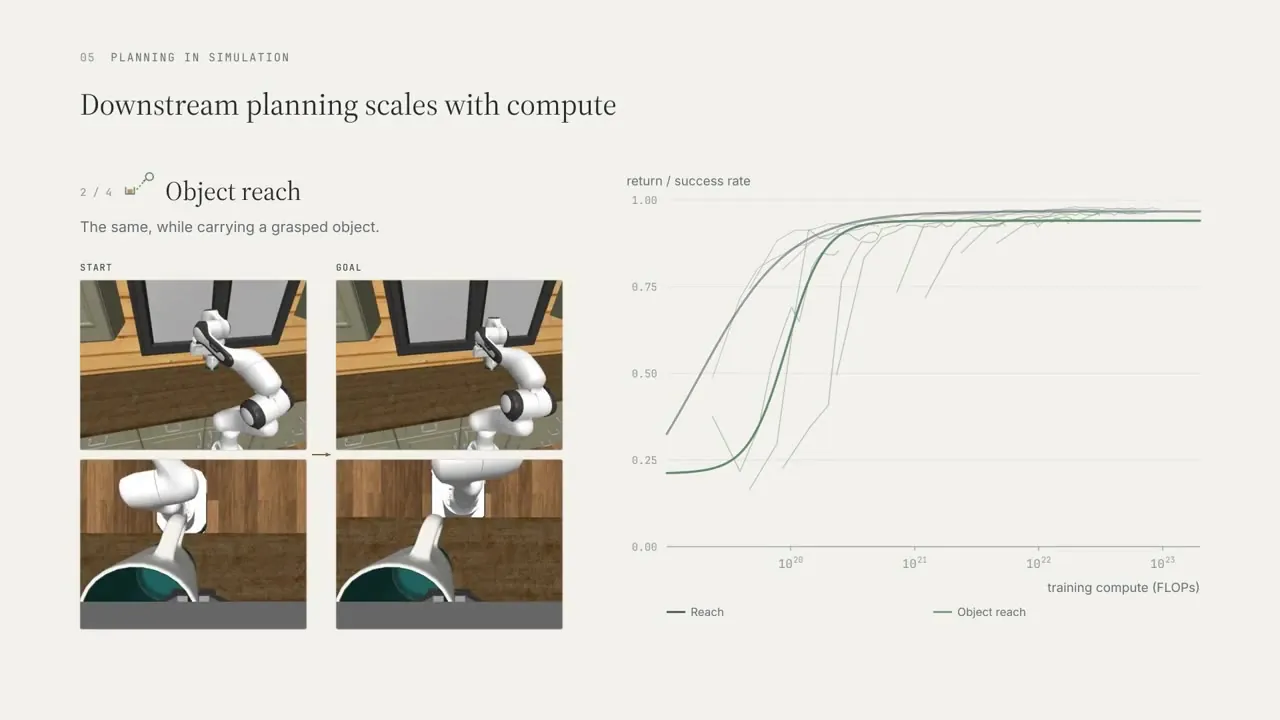
Loading videoRoboJEPA is a family of action-conditioned latent world models (22M-8B) on a frozen V-JEPA 2.1 encoder: imagination error follows an extrapolatable compute scaling law, and the 8B model plans zero-shot toward one goal image on a real robot.
Category: research
Author: @artemZholus
Date: 2026-10-10T00:00:00
Duration: 66.002s
Reference: https://arxiv.org/abs/2610.10515