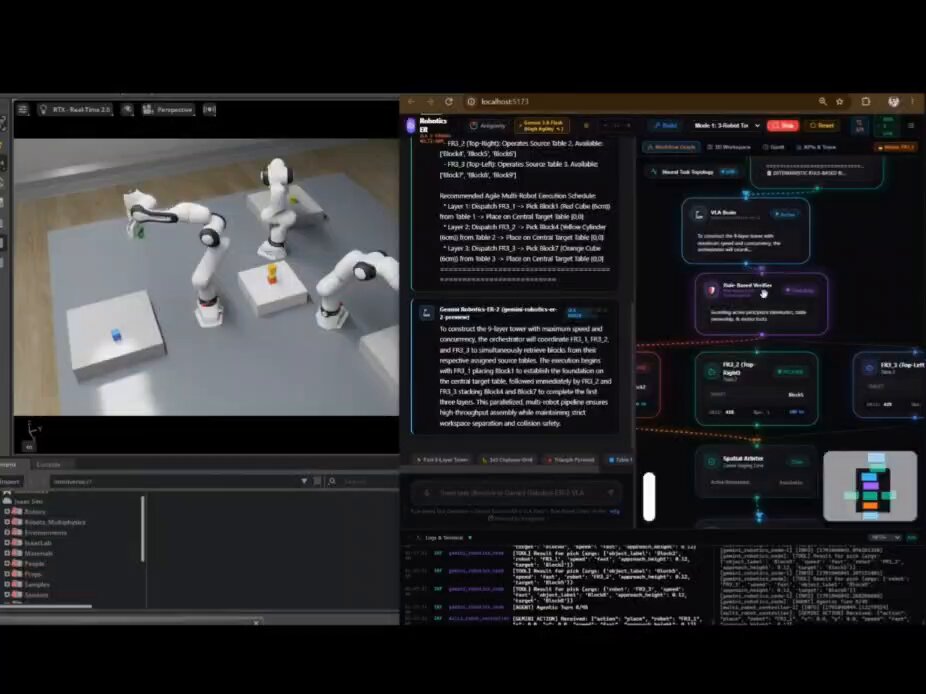
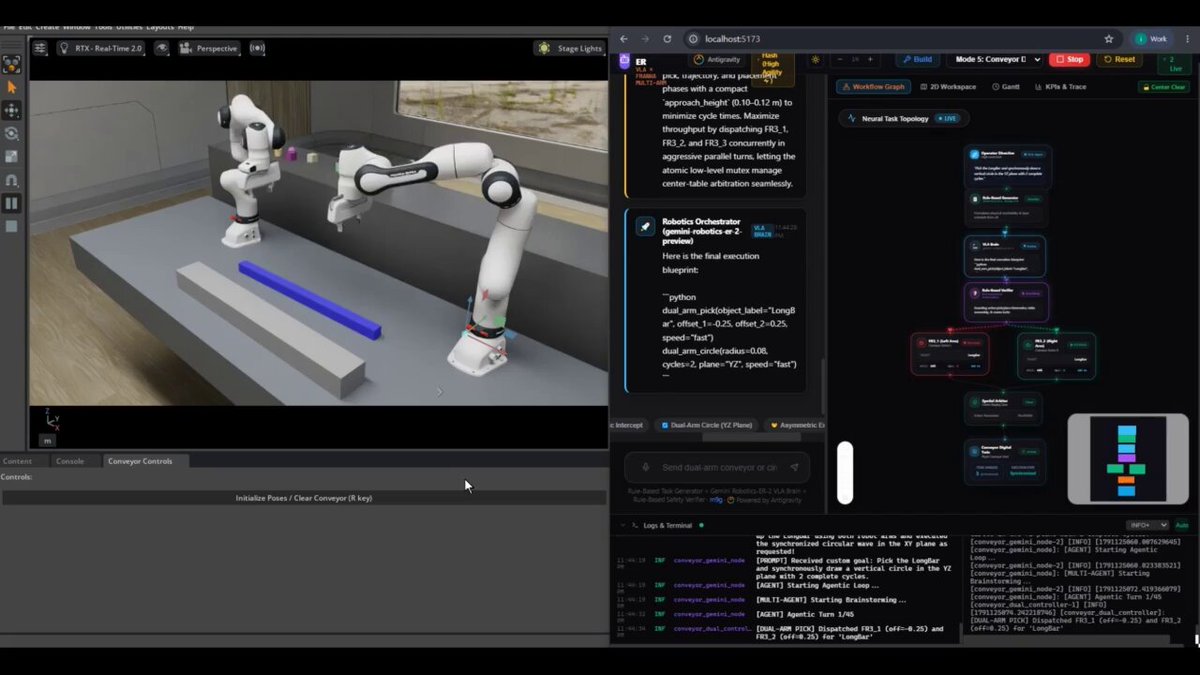
Gemini Robotics-ER 2 scripts a two-FR3 grasp: shared circle, YZ then XY (Isaac Sim + ROS 2)
Loading video
Loading videoMax Chang (@Official_m9g) demos Gemini Robotics-ER 2 writing a task for two Franka FR3 arms: the model sets grasp offsets and a shared circle (YZ first, then XY) for the runtime to execute. Candid limits: place accuracy still off, moving objects not yet pickable. Stack: Isaac Sim + ROS 2; code at github.com/mincasurong/IsaacSim_GeminiRobotics.
Category: manipulation
Author: @Official_m9g
Date: 2026-10-04T00:00:00
Duration: 11.041s