Apple EgoDex: Wear a Vision Pro, Do Chores — Dexterous Robot Data Without Teleop
Loading video
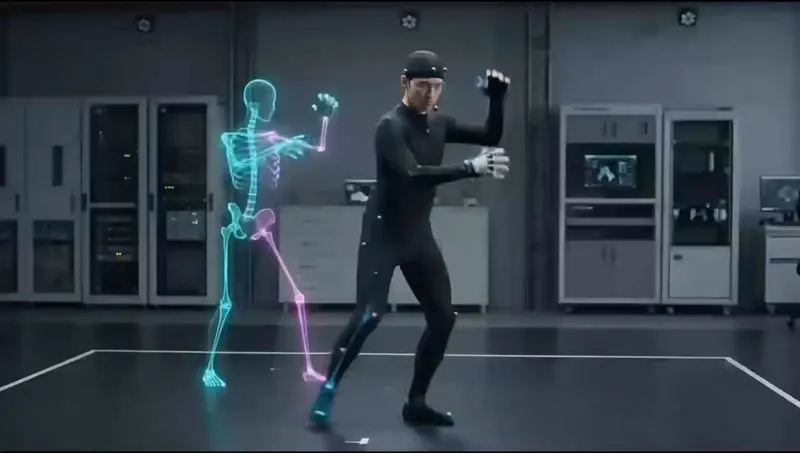
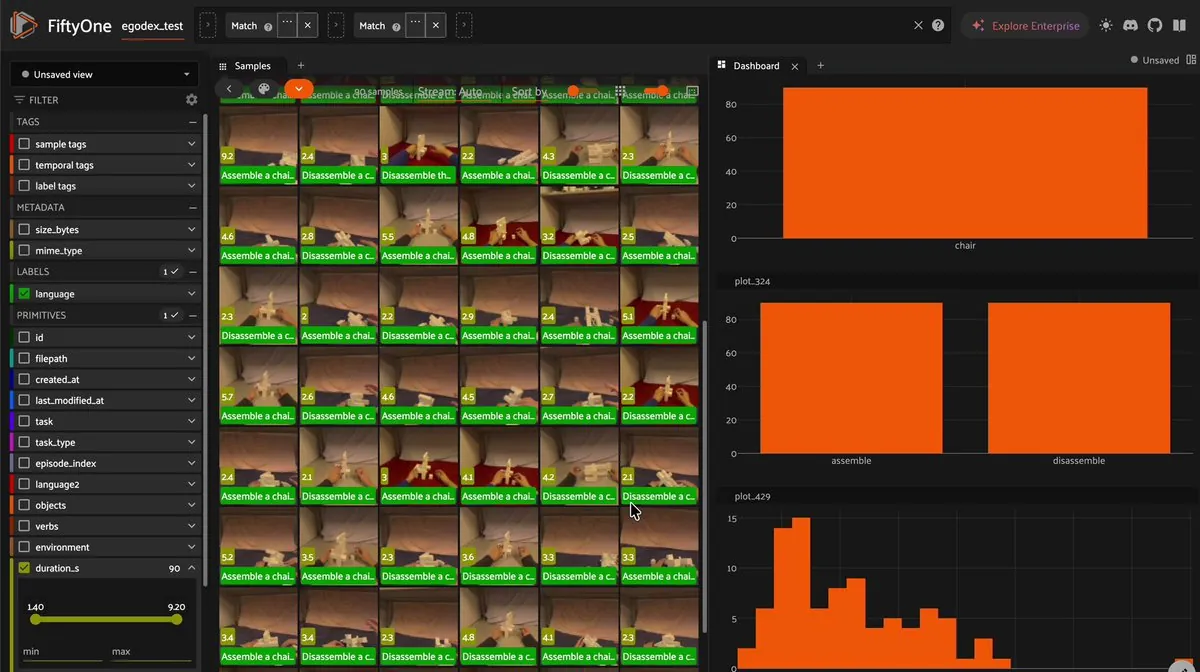
Loading videoRobot dexterity training data has a hard ceiling: someone must teleoperate a physical robot. Apple removed the robot entirely — people wear a Vision Pro and do everyday tasks: laundry, cards, shoelaces. ARKit tracks all 68 body and finger joints at 30 Hz the whole time, turning egocentric human video into a passively scalable source of dexterous manipulation data (EgoDex paper: arxiv 2505.11709).
AppleVision ProARKitEgoDexDexterous ManipulationData CollectionEgocentric Videoteleop-freeARKit-trackingEmbodied AIImitation LearningFirst-person videosTeleoperation ReplacementFull-body Tracking
Category: research
Author: @DataScienceHarp
Date: 2026-08-27T00:00:00
Duration: 30.0s
Reference: https://arxiv.org/abs/2505.11709