OpenLoong QingLong Full-Size General-Purpose Humanoid
Overview
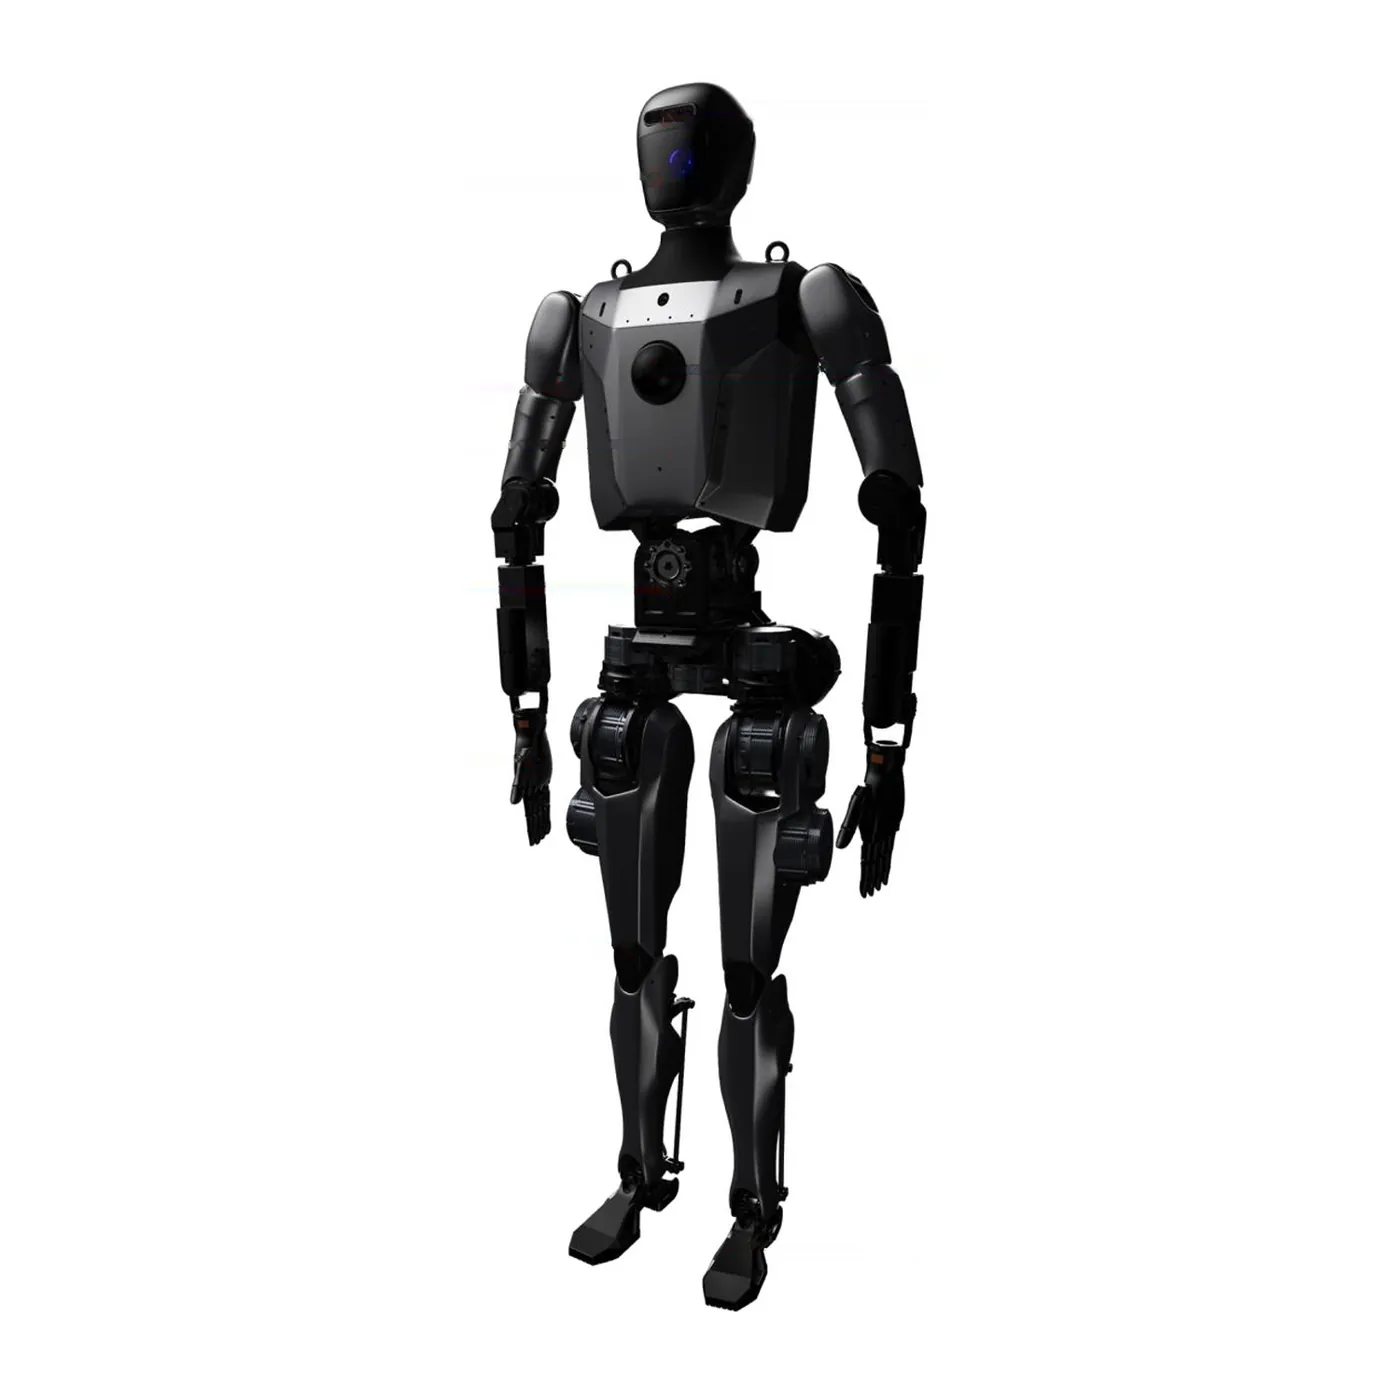
QingLong (OpenLoong) is a full-size general-purpose humanoid from the Shanghai Humanoid Robot Innovation Center: 80 kg with 43 DOF in a highly bionic joint layout that mirrors human joint ranges, walking at >=5 km/h with >=20 kg payload and >=3 h runtime, backed by up to 400 TOPS of control/perception compute. An EtherCAT bus delivers real-time joint control, while 3D LiDAR, depth cameras, surround cameras and a stereo camera provide full-environment perception for autonomous navigation, agile obstacle avoidance and stable slope walking; multi-DOF dexterous hands enable precise grasping. Its hardware is open-sourced on GitHub as OpenLoong-Hardware, including drawings for the waist, chest, head perception and leg-foot systems, to accelerate embodied-AI research and secondary development.
Specifications
| Open-source hardware | GitHub loongOpen/OpenLoong-Hardware( / / / ) |